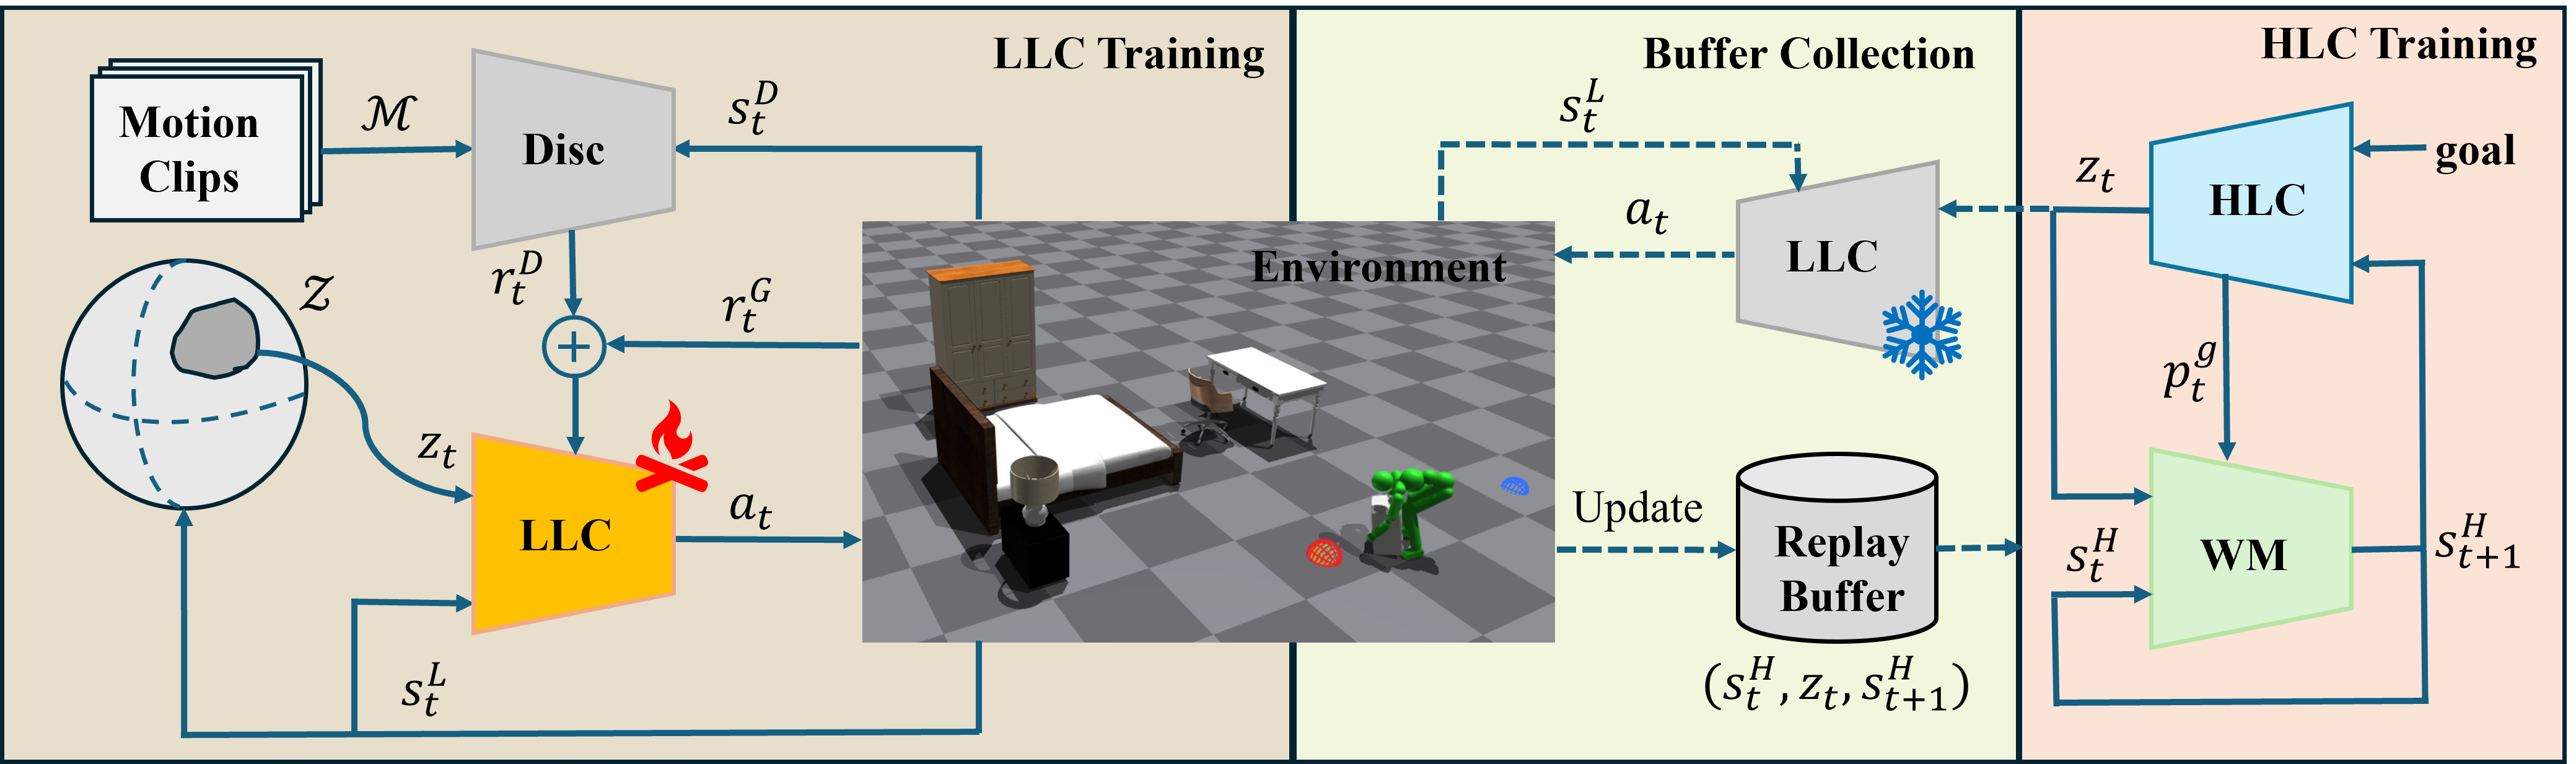
LUCID: Latent-Skill Unified Control via Imagined Dynamics
A hierarchical world-model framework that learns latent skills and plans through imagined dynamics to solve long-horizon humanoid loco-manipulation tasks.
Submitted Under review
Researcher in Robotics & Embodied Intelligence
Hi there! I am a PhD candidate in Robotics at the University of Manchester and Istituto Italiano di Tecnologia (IIT). I worked with Prof. Angelo Cangelosi, Dr. Arash Ajoudani, Prof. Wei Pan and Dr. Daniele Pucci during my PhD.
Before that, I obtained my Master's degree in Mechatronics and Information Engineering from Karlsruhe Institute of Technology, and my Bachelor's degree in Mechatronics Engineering from Zhejiang University.
I build predictive models for embodied robot intelligence — enabling robots to anticipate human motion, environmental uncertainty, and the long-horizon consequences of their actions. My work combines physics-informed learning, uncertainty quantification, and world models for robot control and planning.
A hierarchical world-model framework that learns latent skills and plans through imagined dynamics to solve long-horizon humanoid loco-manipulation tasks.
Submitted Under review
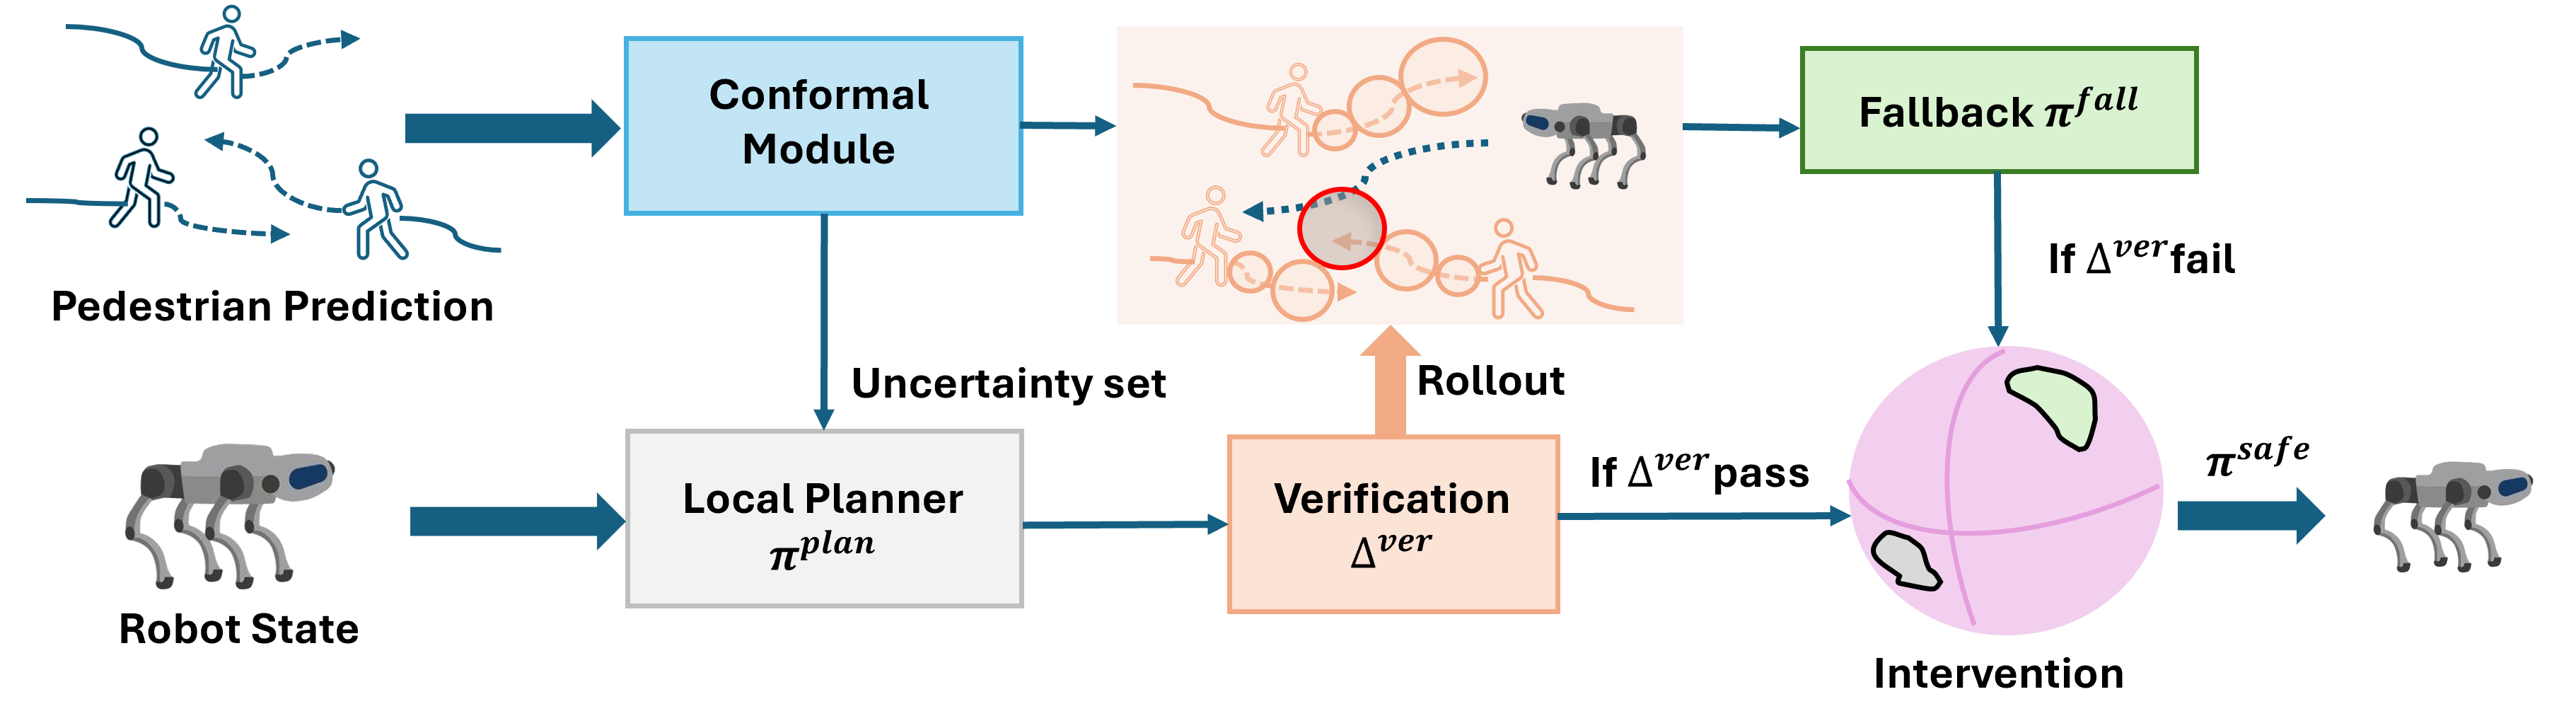
Adaptive conformal prediction for uncertainty-aware human trajectory forecasting, enabling risk-aware quadruped navigation through dynamic, crowded environments.
Submitted Under review
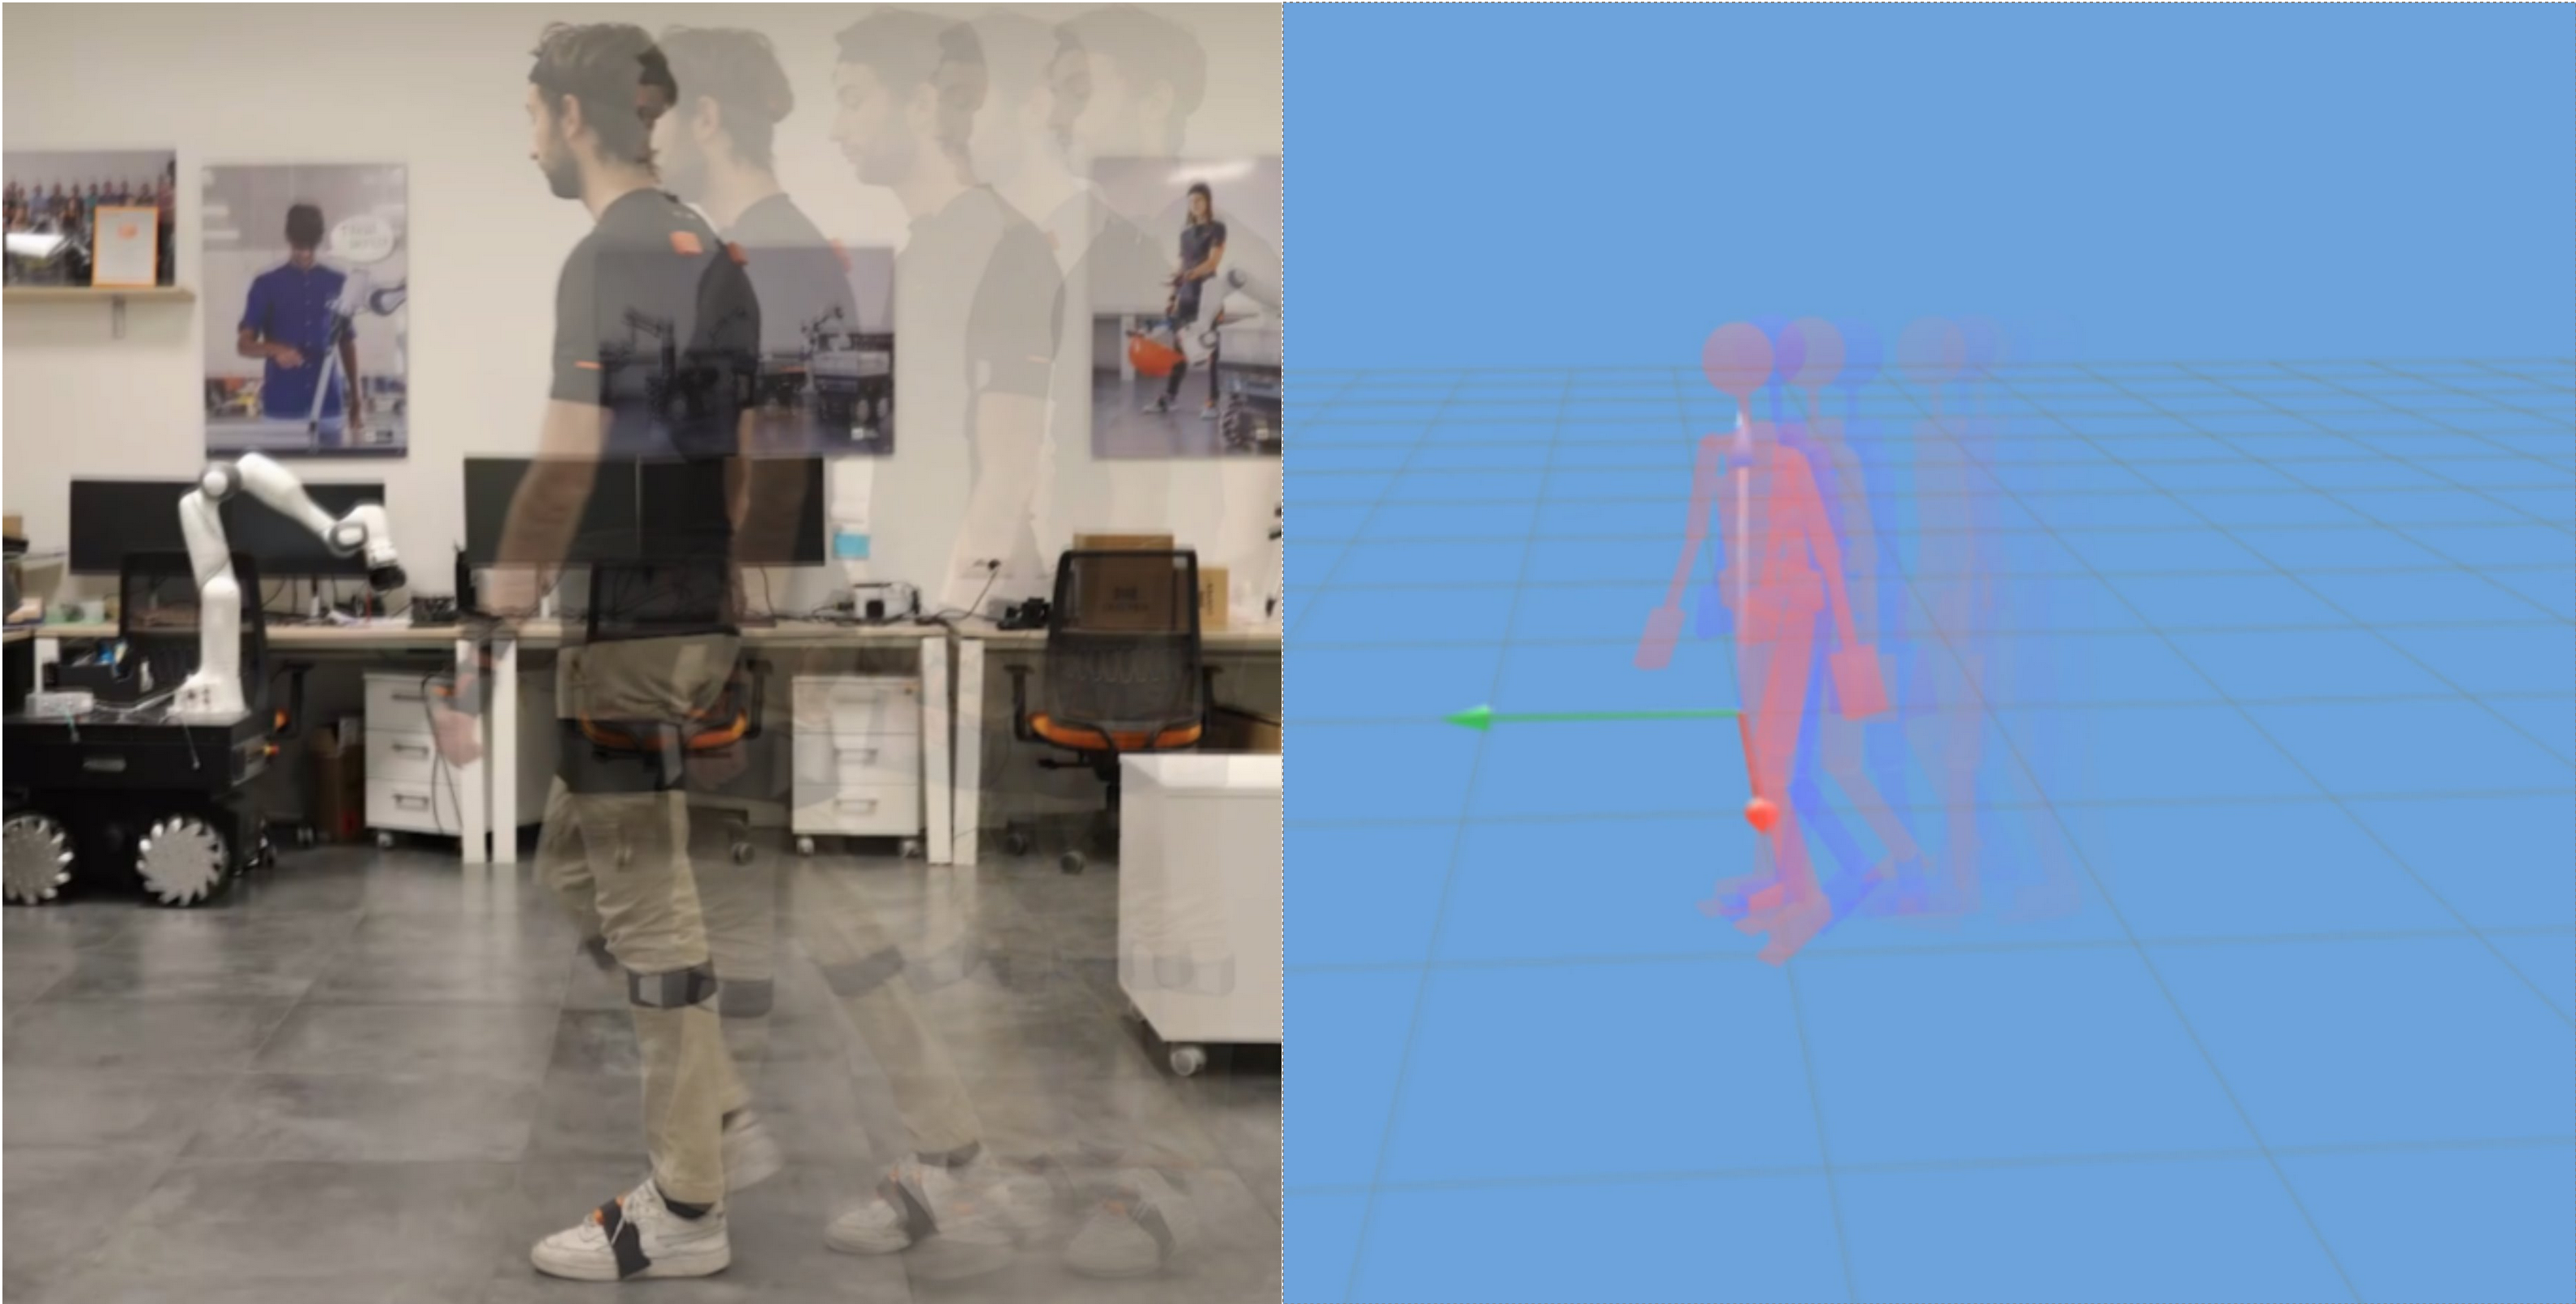
A physics-informed learning framework that predicts human whole-body kinematics from only a sparse set of wearable IMUs, improving accuracy for human–robot collaboration.
IROS 2025 Accepted
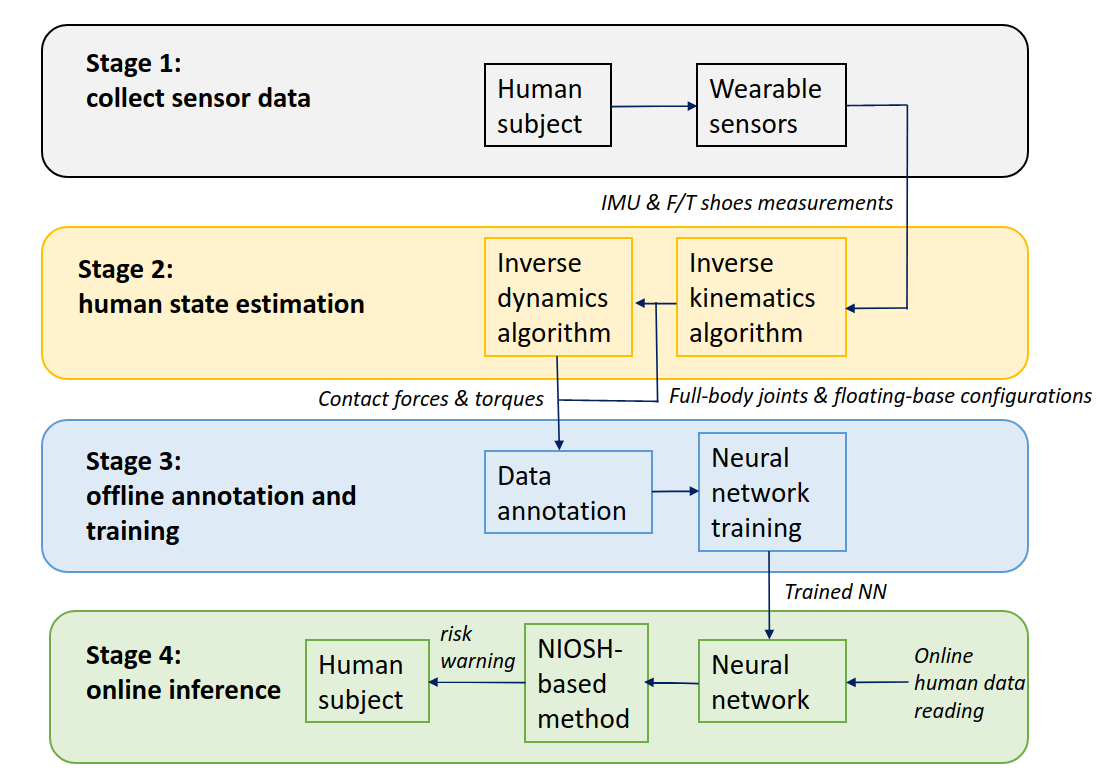
Real-time human action recognition with wearable sensing that anticipates ergonomic risk and delivers haptic alerts before hazardous motions occur.
Humanoids 2023 Accepted
Cheng Guo in bold. * denotes equal contribution where noted.
LUCID: Latent-Skill Unified Control via Imagined Dynamics for Long-Horizon Humanoid Loco-Manipulation
Submitted for peer review
CoCoNav: Conformal Control for Safe Robot Navigation in Crowds
Submitted for peer review
PhysTennis: A Differentiable-Physics Approach for Quadruped Robotic Tennis
Submitted for peer review
PAWS: Predictive Adaptive Whole-Body Safety for Cross-Embodiment Mobile Manipulation
Submitted for peer review
SoraNav: Adaptive UAV Task-Centric Navigation via Zero-shot VLM Reasoning
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
ConformalNav: Adaptive Conformal Prediction for Safe Quadrupedal Social Navigation
15th UKACC Control Conference, 2026
Physics-Informed Learning for Human Whole-Body Kinematics Prediction via Sparse IMUs
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025
Online Action Recognition for Human Risk Prediction with Anticipated Haptic Alert via Wearables
IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2023
Online Human Action Recognition for NIOSH-based Risk Assessment
IROS 2022 Workshop
Peer reviewer for the following journals and conferences:
— visits