datawhalechina/every-embodied
Jupyter Notebook
仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能
仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能
兴趣:world models and video prediction for embodied agents
Jupyter Notebook
仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能
兴趣:world models and video prediction for embodied agents
HTML
本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战
兴趣:vision-language-action (VLA) models and foundation models for robots
Rust
A high-performance inference engine for AI models
兴趣:large language models for robot task planning and reasoning
Python
Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective
兴趣:world models and video prediction for embodied agents
Python
A unified framework for training, fine-tuning, and evaluating World Action Models
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning
兴趣:imitation learning and diffusion policies for robot control
Python
A Paper List for Humanoid Robot Learning.
兴趣:humanoid robots and whole-body control
Python
[IROS 26 ScaleInfra Workshop Best Tool Paper] Involving over 50 Advanced Manipulation Policies
兴趣:robot manipulation and grasping with learned policies
人形机器人运动智能论文、开源项目、产业与求职知识库
兴趣:humanoid robots and whole-body control
Python
World model reinforcement learning for multi-turn VLM agents. RL for vision framework (NeurIPS 2025).
兴趣:vision-language-action (VLA) models and foundation models for robots
Jupyter Notebook
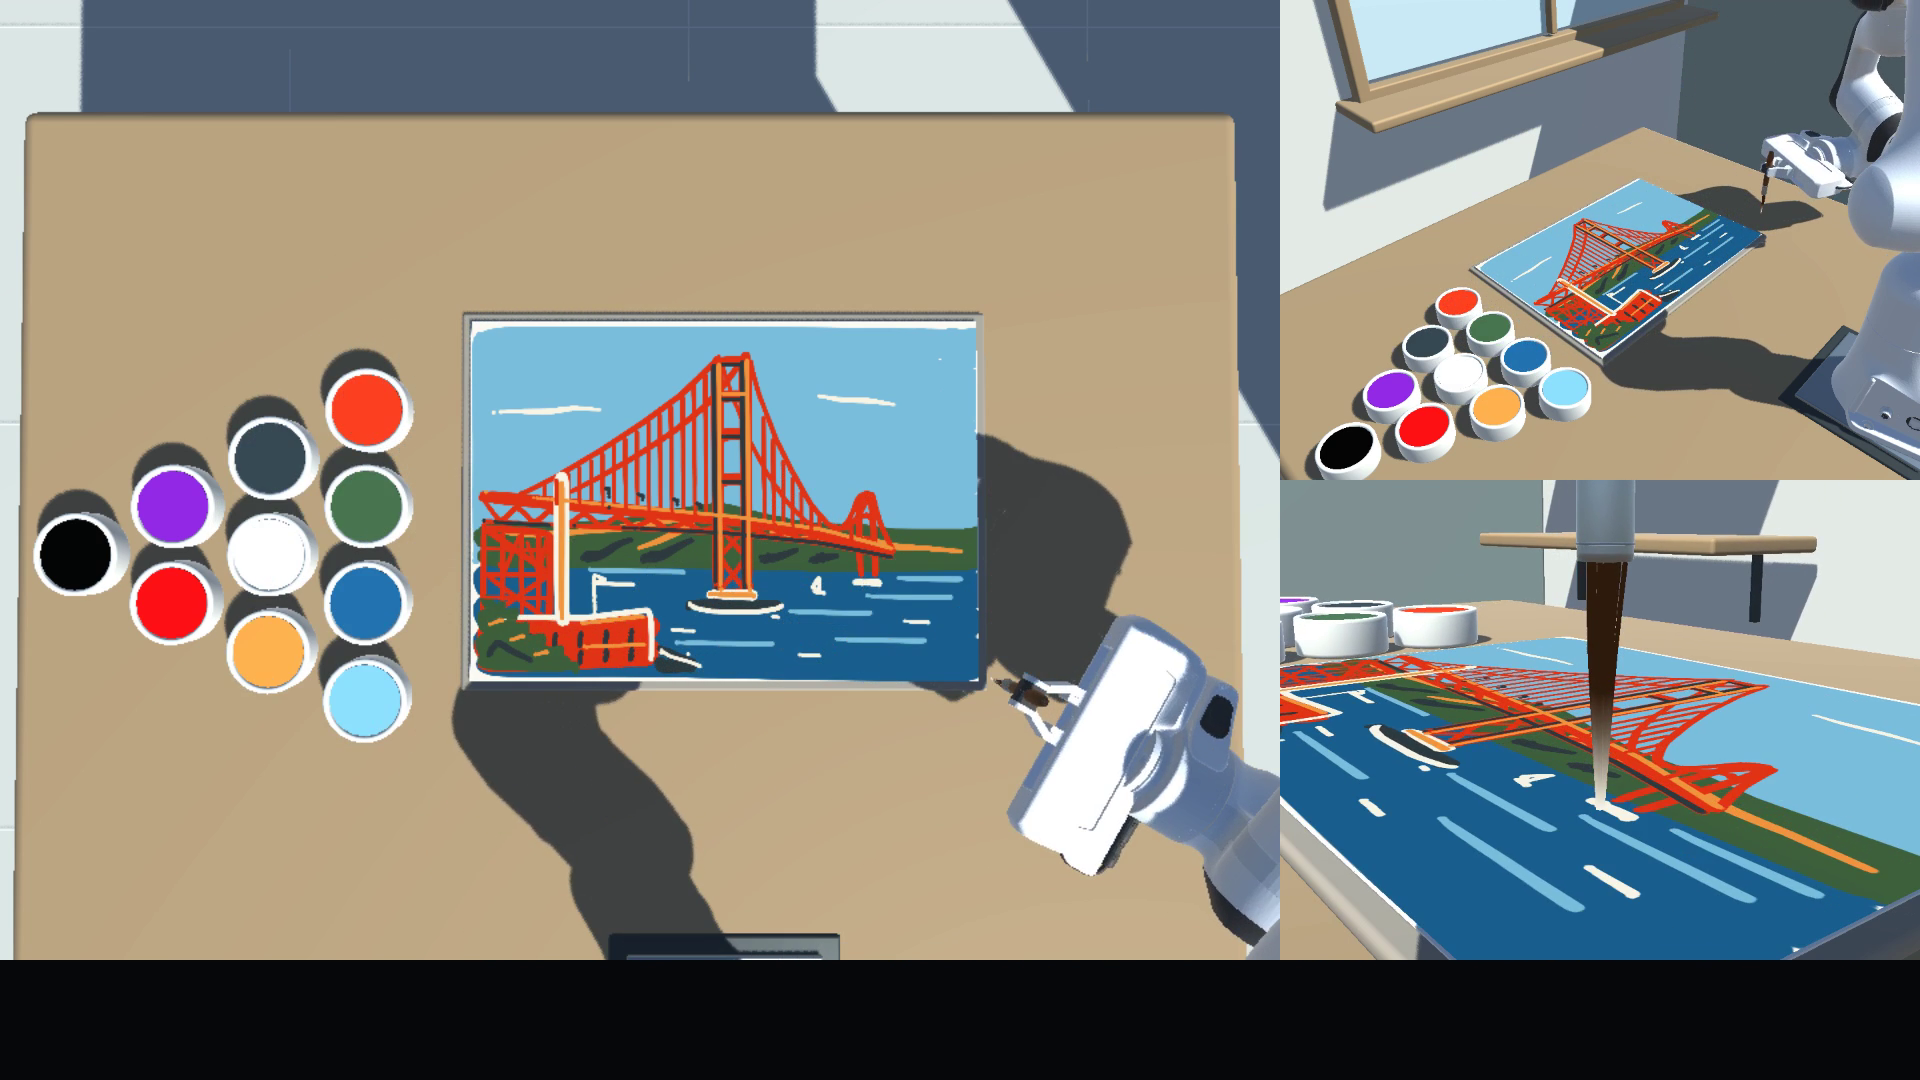
A robot-painting benchmark for multimodal language models: reference images, text prompts, and custom goals. Built on AgentArk.
兴趣:large language models for robot task planning and reasoning
Python
An open interactive toolkit that accelerates human and agentic physics-based Real2Sim of Robot Manipulation Tasks
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
A Foundation Model for Whole-Body Humanoid Control
兴趣:humanoid robots and whole-body control
Python
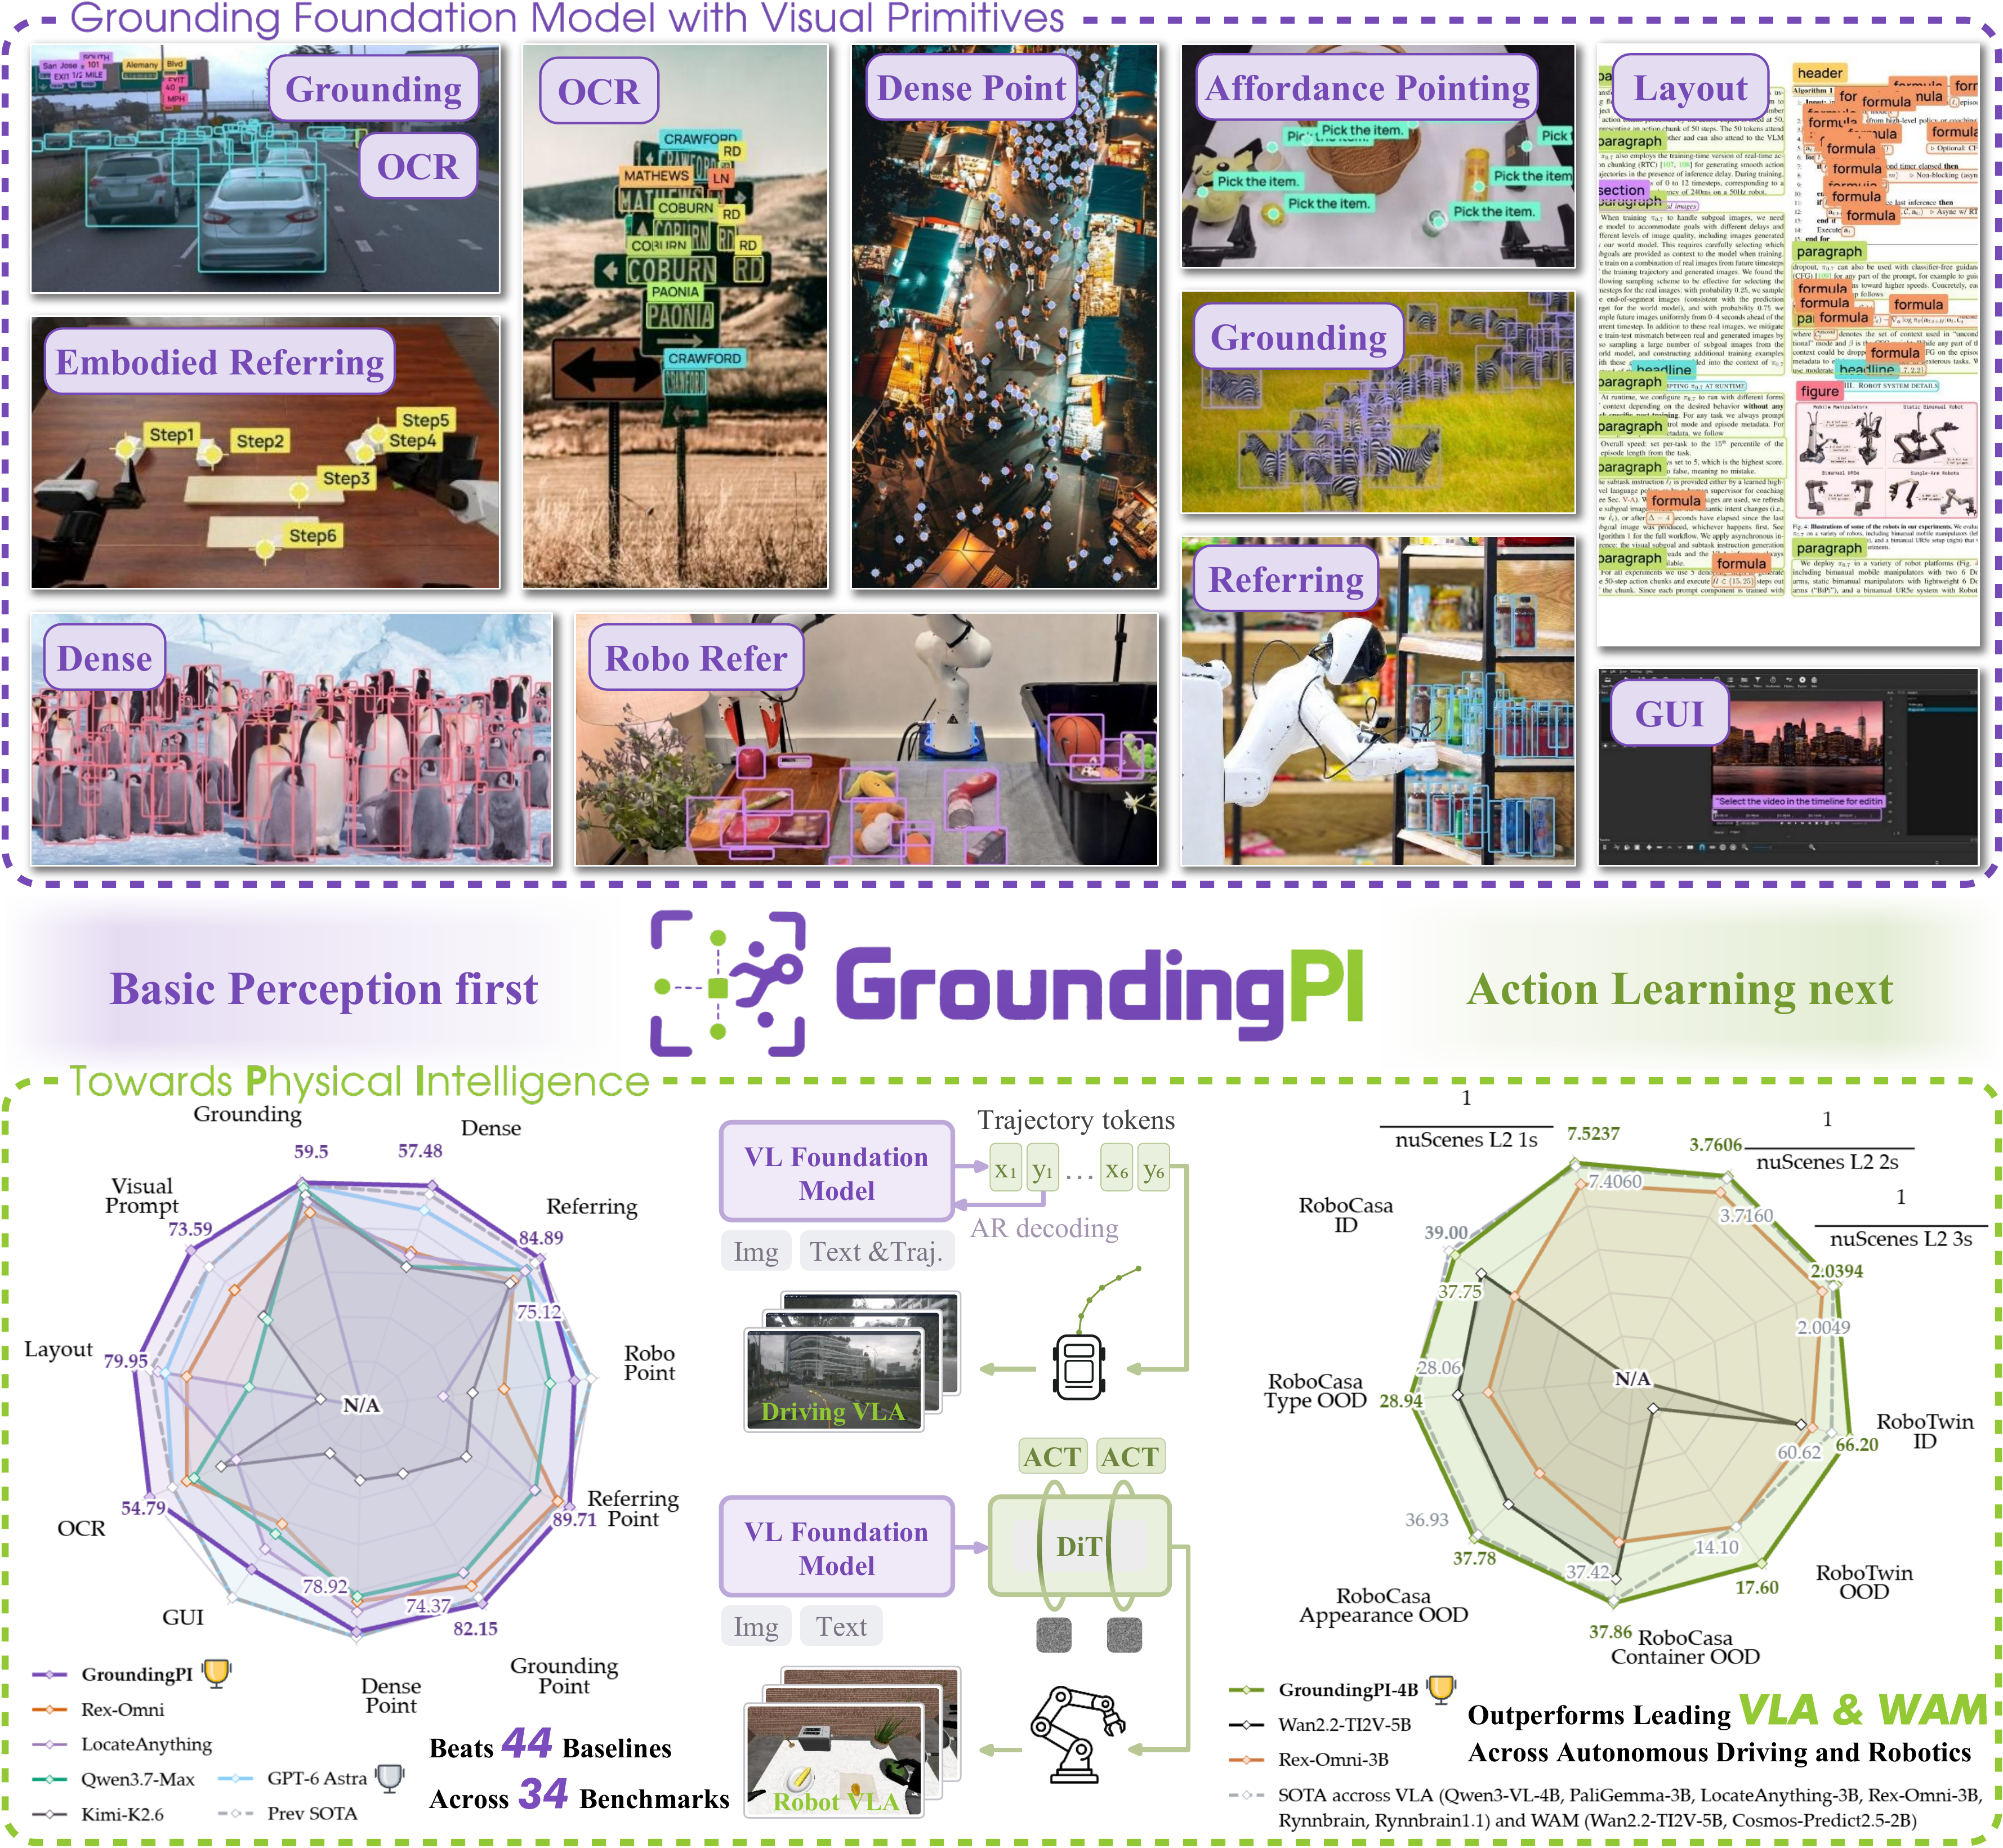
A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and improving robot generalization and data efficiency in controlled evaluations.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Unified framework for robot learning with multi-physics/renderer support
兴趣:3D perception, point clouds and scene understanding for robotics
Python
A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e, xArm, SO101, YAM and Rizon.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Tien Kung-Lab: Direct IsaacLab Workflow for Legged Robots
兴趣:humanoid robots and whole-body control
C++
Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control
兴趣:humanoid robots and whole-body control
Python
Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Design physical products with AI
兴趣:humanoid robots and whole-body control
Python
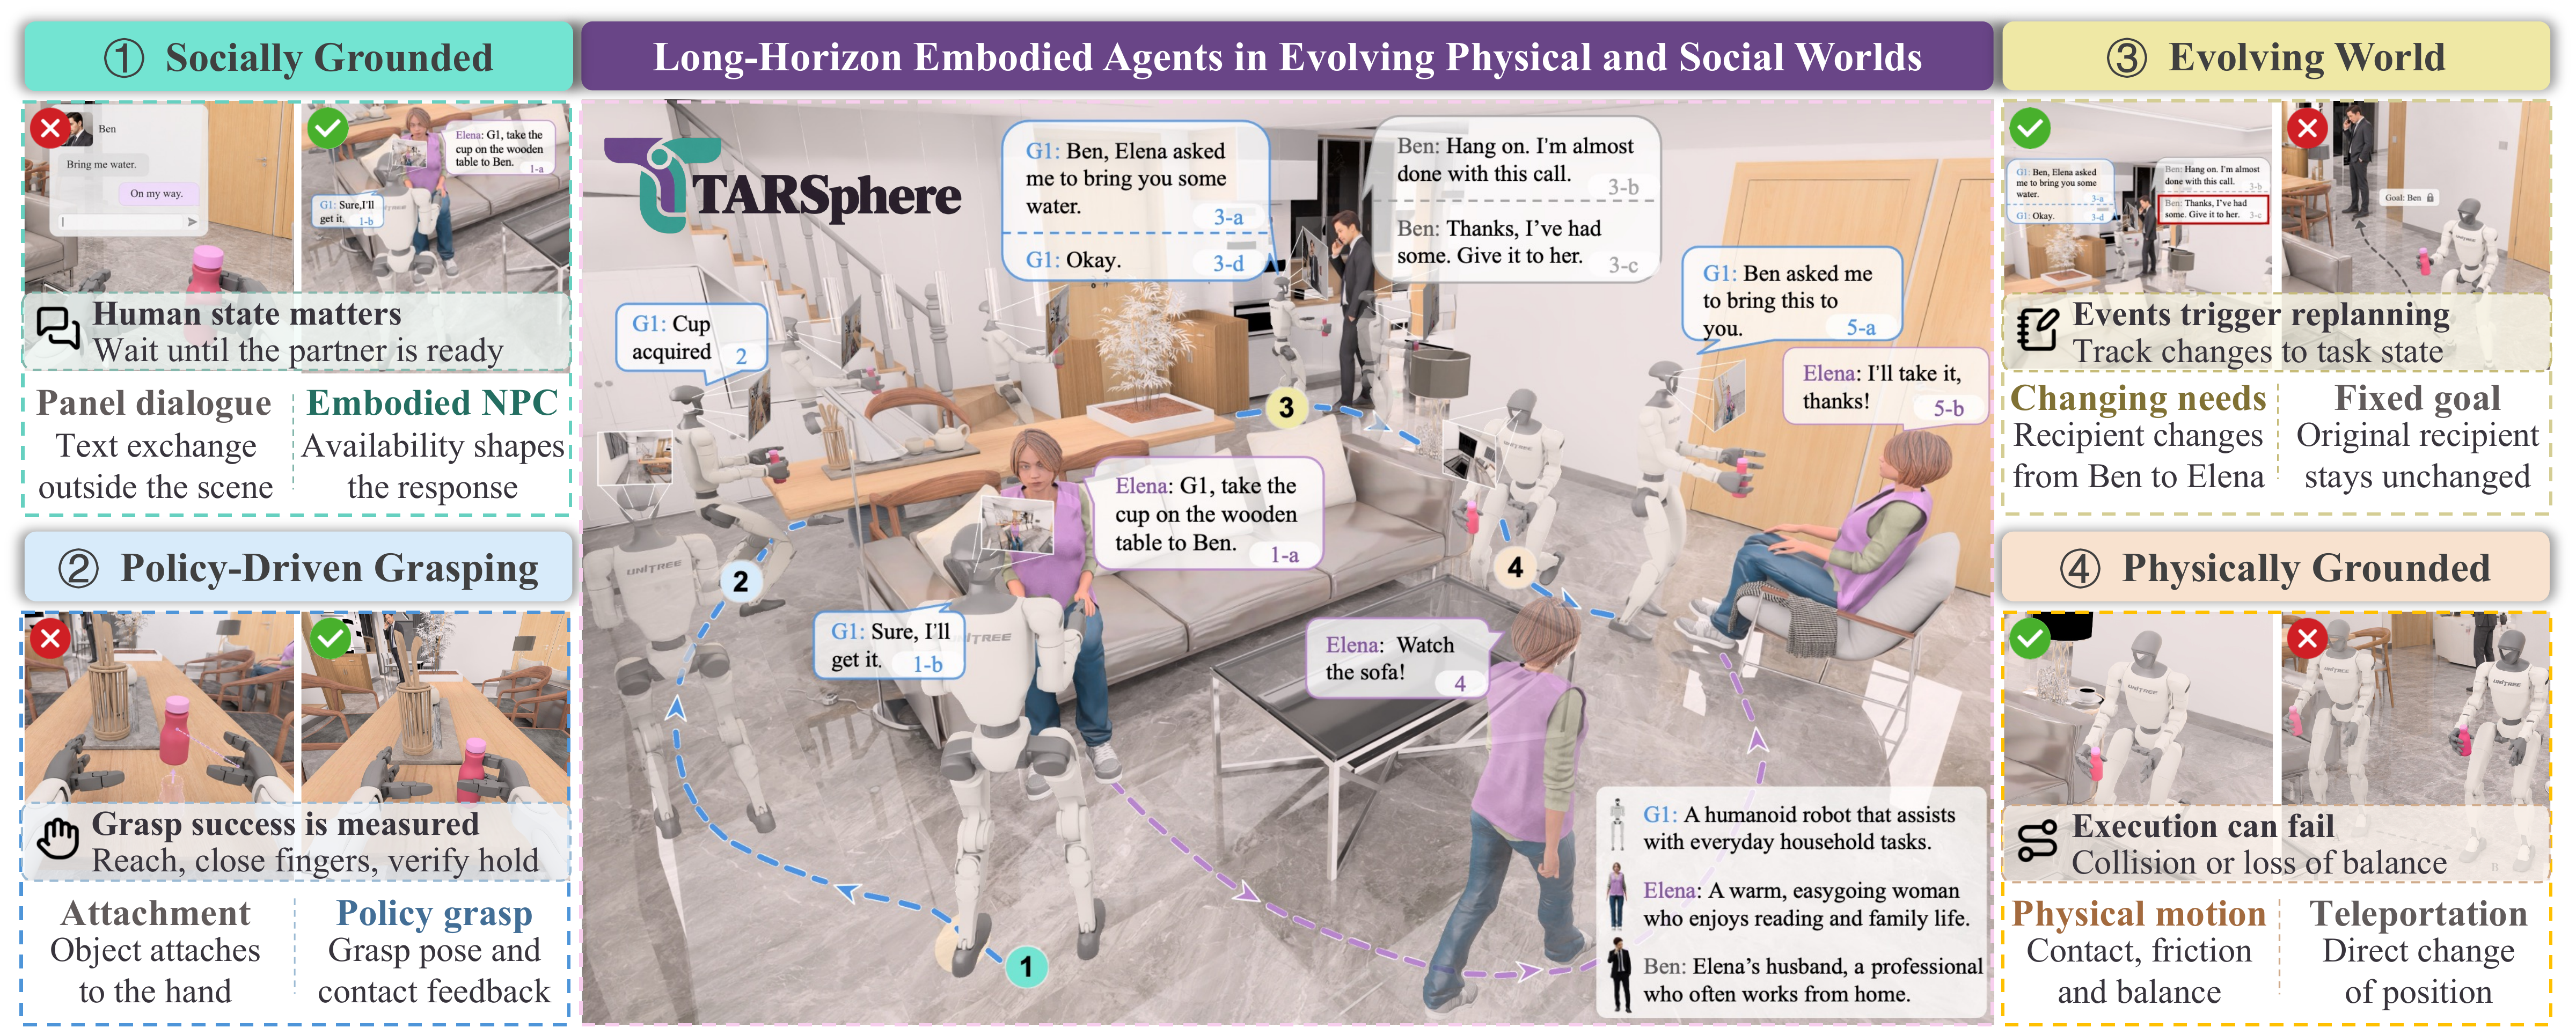
A robot-oriented full-stack framework for long-horizon embodied agents in evolving physical and social environments.
兴趣:world models and video prediction for embodied agents
Python
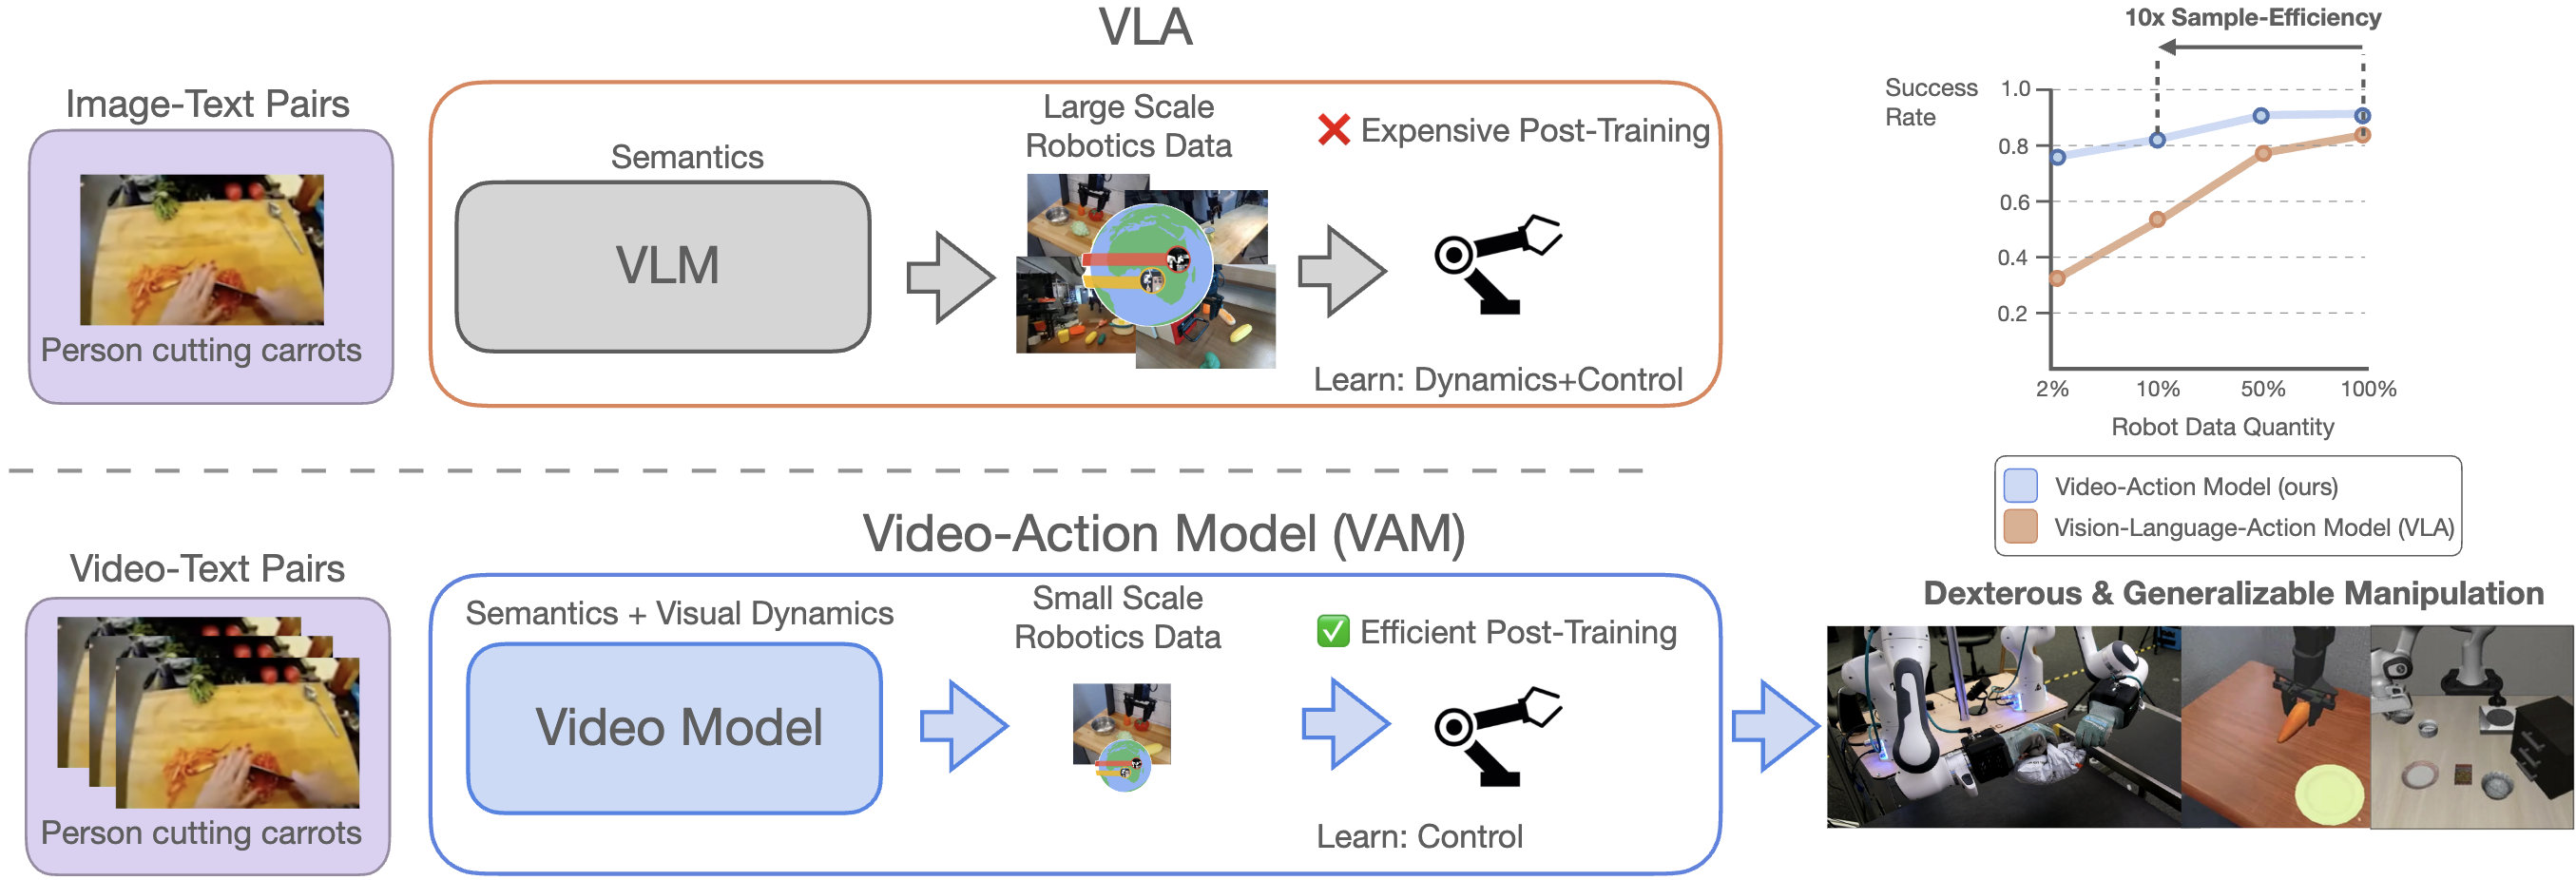
Video-Action Models for Generalizable Robot Control Beyond VLAs
兴趣:imitation learning and diffusion policies for robot control
Python
RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning
兴趣:imitation learning and diffusion policies for robot control
Python
Synapsa Commons: free, hands-on AI courses that run anywhere (Colab, Kaggle, Binder, Codespaces, Jupyter). EU AI Act conformity evidence, model validation, predictive maintenance, document extraction, retrieval and RAG, AI agents and MCP, a simulated humanoid. Every lesson autograded. From the team building Synapsa.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
The first exam for code agents in the physical world: frozen robot tasks from many benchmark suites, each answered with a program and verified in a separate sandbox. Runs on Harbor.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
2,000 curated embodied AI and robotics resources with bilingual metadata and transparent ranking
兴趣:world models and video prediction for embodied agents
Python
StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Learn AI Engineering! Learn it. Build it. Ship it for others.
兴趣:multi-agent systems and LLM agents