Tech Station

2026-10-31

0 篇论文 · 30 个项目 ← 2026-10-30 · 2026-11-01 →

GitHub 项目

#12026-10-29★ 63 +41新项目76

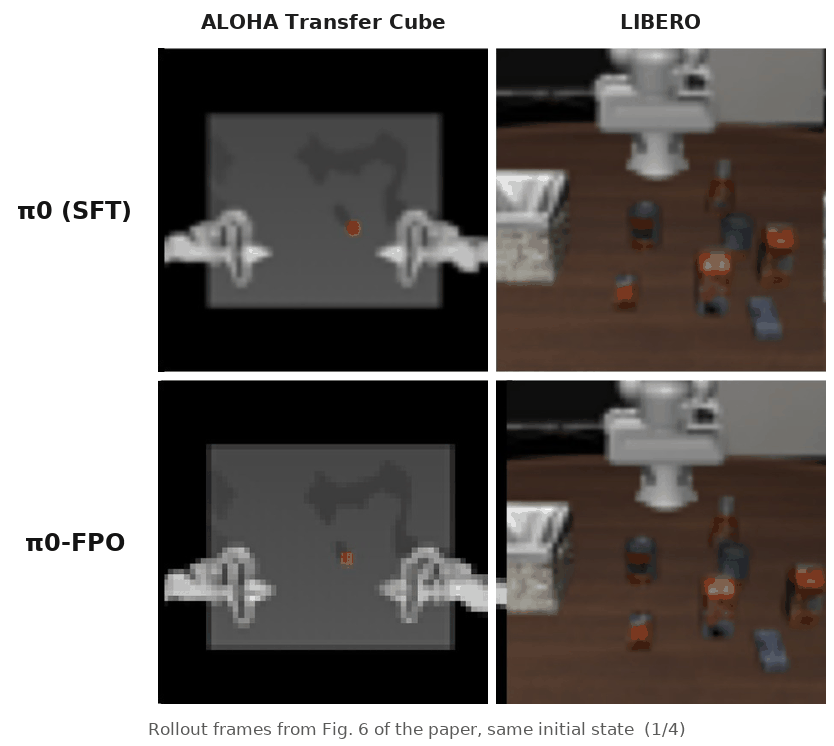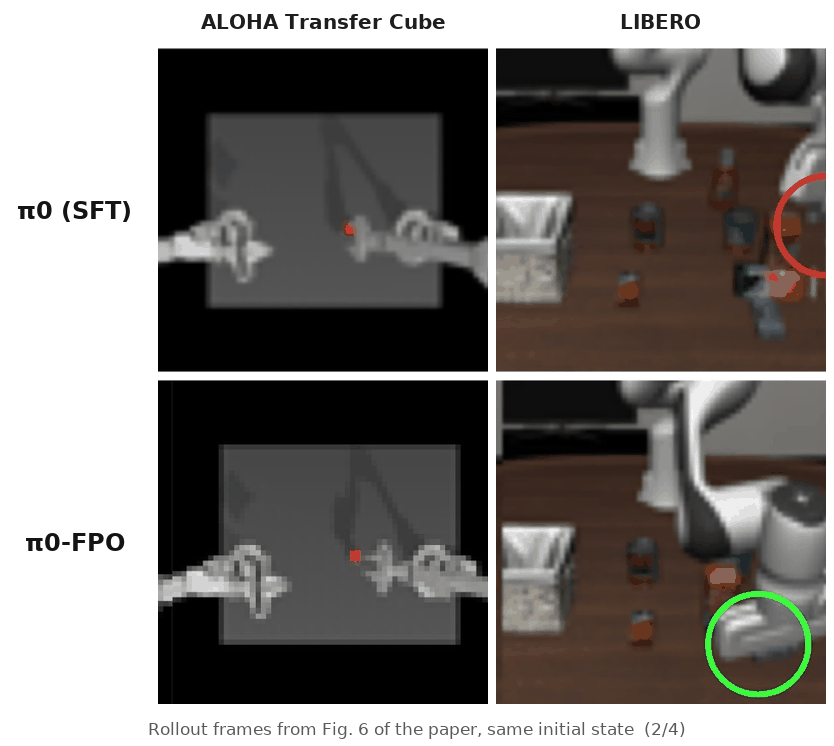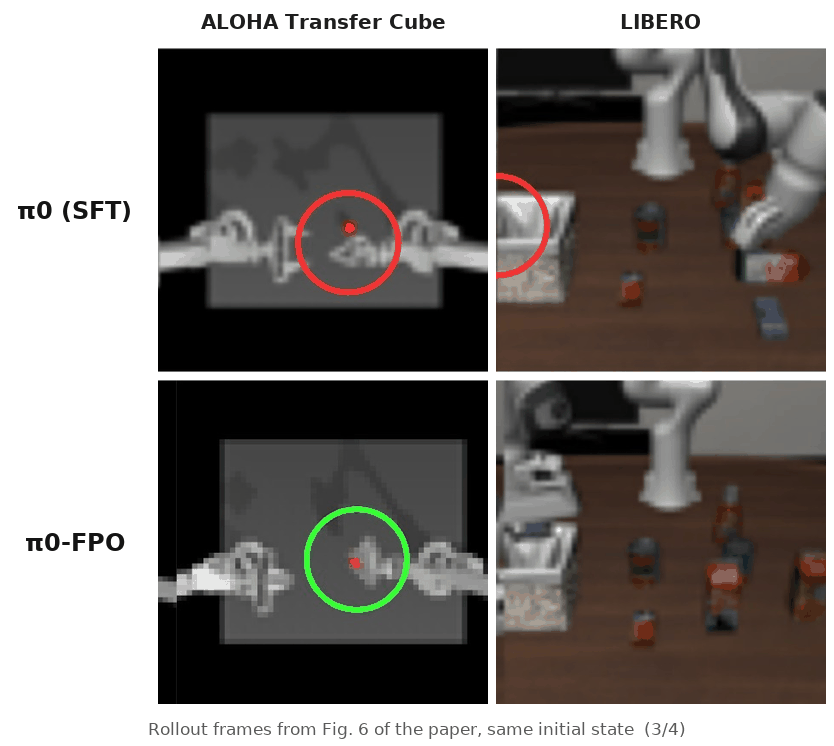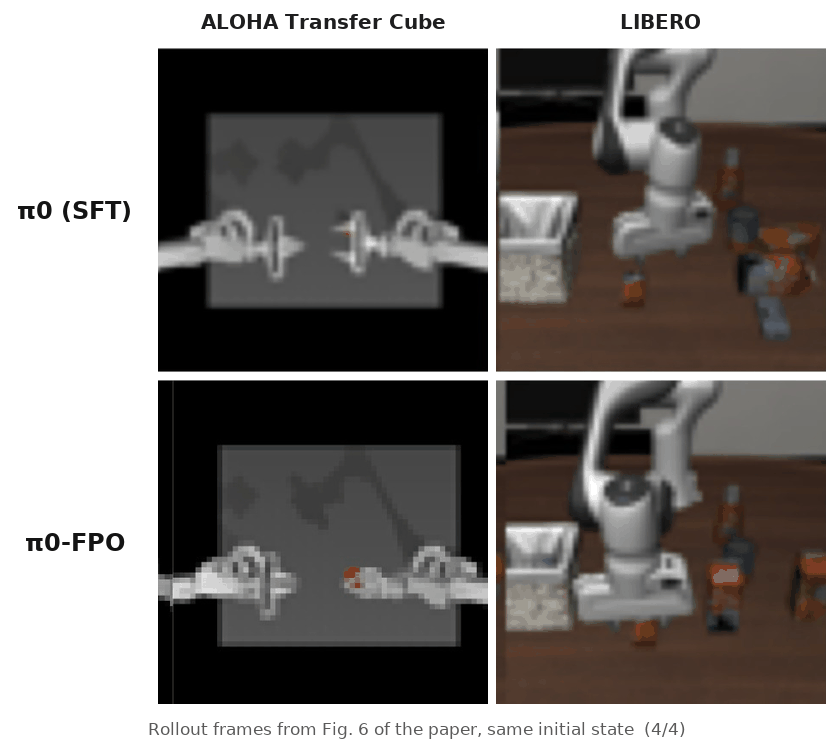
tuotuoLyu/FPO

Python

Official code for "Reinforcement Fine-Tuning of Flow-Matching Policies for Vision-Language-Action Models" (ICRA 2026): Flow Policy Optimization for pi0

Official code for "Reinforcement Fine-Tuning of Flow-Matching Policies for Vision-Language-Action Models" (ICRA 2026): Flow Policy Optimization for pi0

alohaflow-matchingicra2026jaxliberoreinforcement-learningrobot-learningvision-language-actionrobotvision-language-action

兴趣:vision-language-action (VLA) models and foundation models for robots
#22025-10-09★ 3.9k +473

starVLA/starVLA

Python

StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing

StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing

robotic-foundation-modelroboticsvision-language-action-modelworld-action-modelvision-language-action

兴趣:vision-language-action (VLA) models and foundation models for robots

#32025-11-23★ 755 +373

sou350121/VLA-Handbook

HTML

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

chinesedeep-learningembodied-aillmrobot-learningroboticsvision-language-actionvlarobotVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#42024-12-08★ 4.3k +873

datawhalechina/every-embodied

Jupyter Notebook

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

embodied-agentembodied-aiembodied-intelligenceopenvlasmolvlavision-language-action-modelVLAvision-language-actionembodied

兴趣:world models and video prediction for embodied agents

#52026-10-18★ 33 +7新项目71

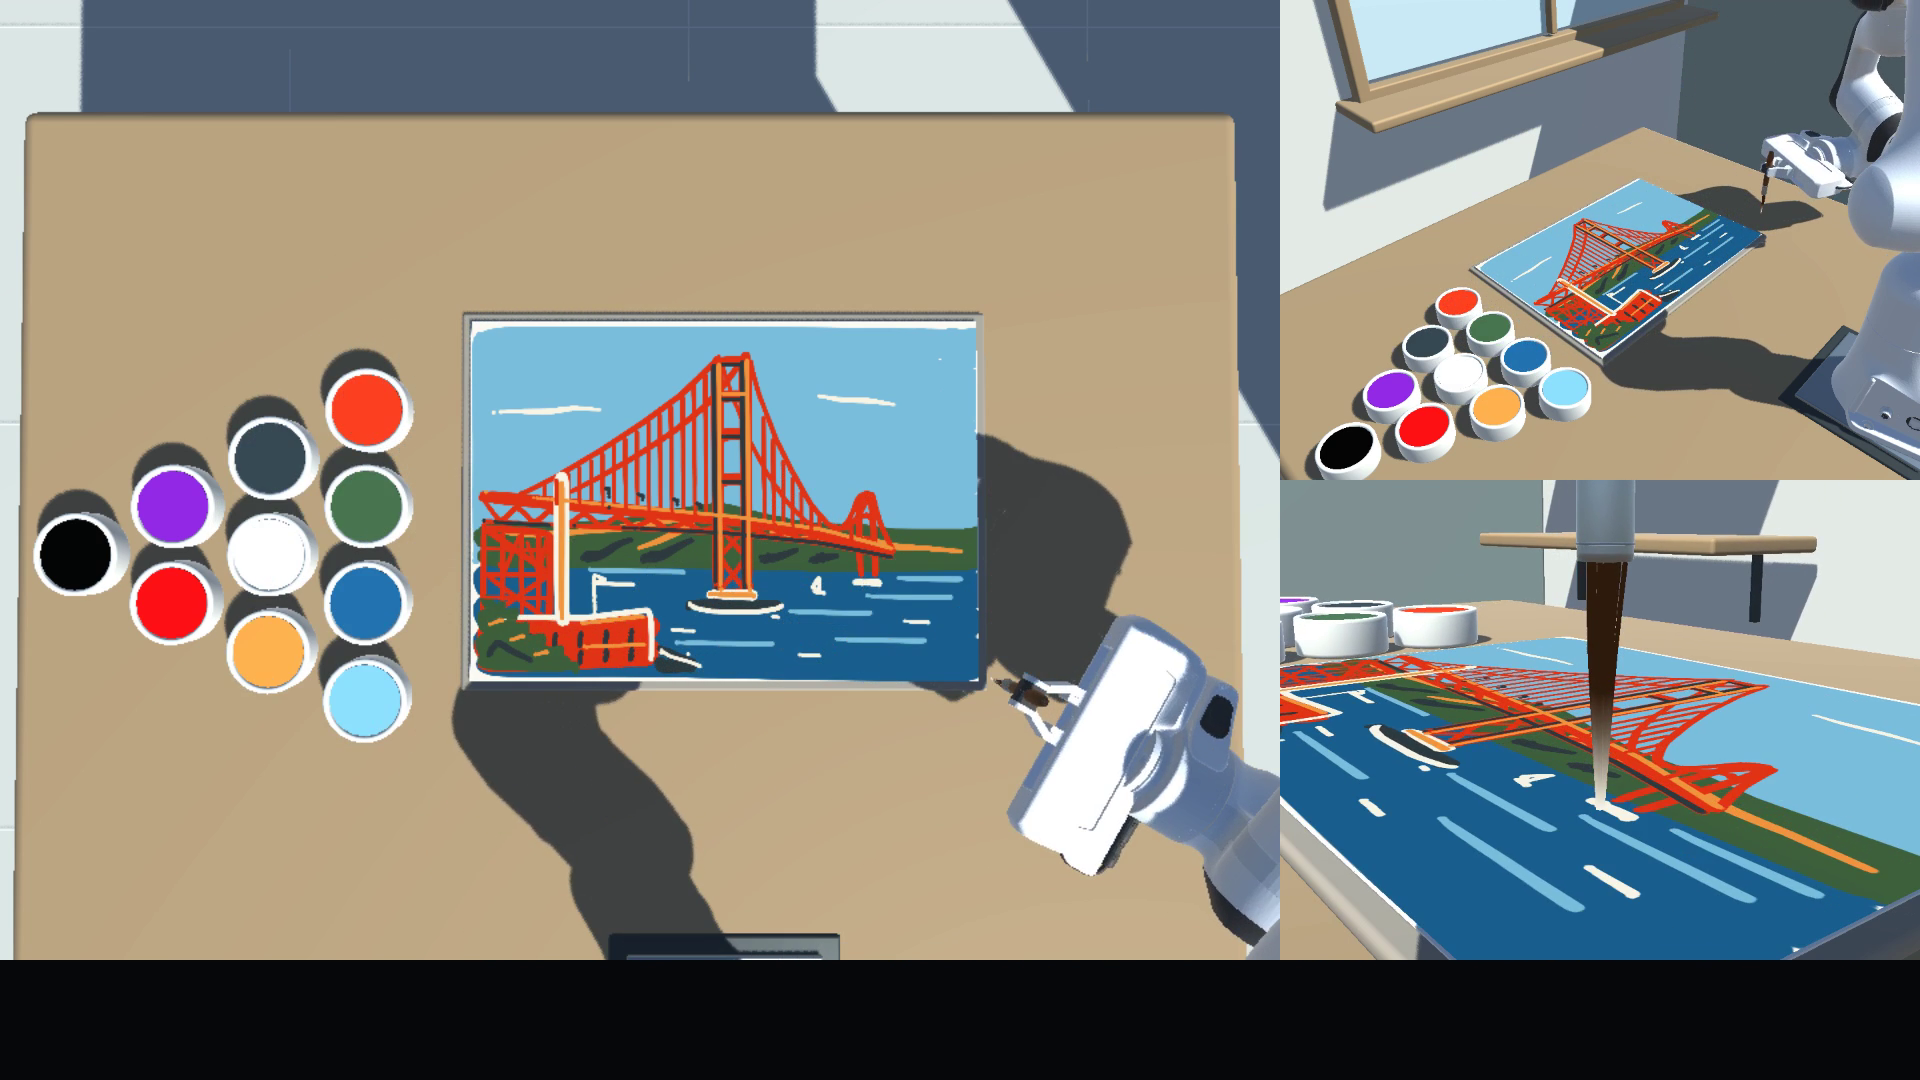
P90-RushB/robopaint-bench

Jupyter Notebook

A robot-painting benchmark for multimodal language models: reference images, text prompts, and custom goals. Built on AgentArk.

A robot-painting benchmark for multimodal language models: reference images, text prompts, and custom goals. Built on AgentArk.

agentarkbenchmarkembodied-aimultimodalroboticssimulationrobotembodied

兴趣:large language models for robot task planning and reasoning

#62026-10-29★ 85 +41新项目71

tuotuoLyu/ForesightSafety-VLA

Python

Official code for ForesightSafety-VLA (IROS 2026): a unified diagnostic safety benchmark for vision-language-action models on RoboTwin

Official code for ForesightSafety-VLA (IROS 2026): a unified diagnostic safety benchmark for vision-language-action models on RoboTwin

benchmarkembodied-aiiros2026robot-safetyroboticsrobotwinsafety-evaluationvision-language-actionrobotVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#72026-10-05★ 221 +2新项目71

AetherLabsAI/Video2World

Python

Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective

Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective

benchmarkcoding-agentembodied-aifoundation-modelsreal-to-simrobot-learningroboticssimulationrobotembodied

兴趣:world models and video prediction for embodied agents

#82024-01-26★ 28.6k +1770

huggingface/lerobot

Python

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

兴趣:imitation learning and diffusion policies for robot control

#92026-09-08★ 7170

lok-i/vibe

Python

Post-training humanoid whole-body trackers for perceptive control tasks

Post-training humanoid whole-body trackers for perceptive control tasks

humanoid-controlmjlabperceptive-locomotionpporeinforcement-learningrobot-learningviberobothumanoidlocomotion

兴趣:humanoid robots and whole-body control

#102026-10-21★ 24 +1新项目70

xuyicheng-zju/TARSphere

Python

A robot-oriented full-stack framework for long-horizon embodied agents in evolving physical and social environments.

A robot-oriented full-stack framework for long-horizon embodied agents in evolving physical and social environments.

benchmarkembodied-aiisaac-simroboticsrobotembodied

兴趣:world models and video prediction for embodied agents

#112026-10-12★ 279 +4新项目70

robosimstudio/robosimstudio

Python

An open interactive toolkit that accelerates human and agentic physics-based Real2Sim of Robot Manipulation Tasks

An open interactive toolkit that accelerates human and agentic physics-based Real2Sim of Robot Manipulation Tasks

agentinverse-physicsreal2simreal2sim2realroboticssimulationrobotmanipulation

兴趣:vision-language-action (VLA) models and foundation models for robots
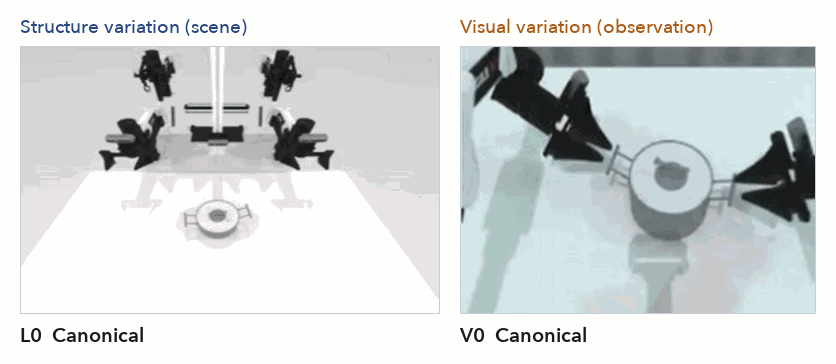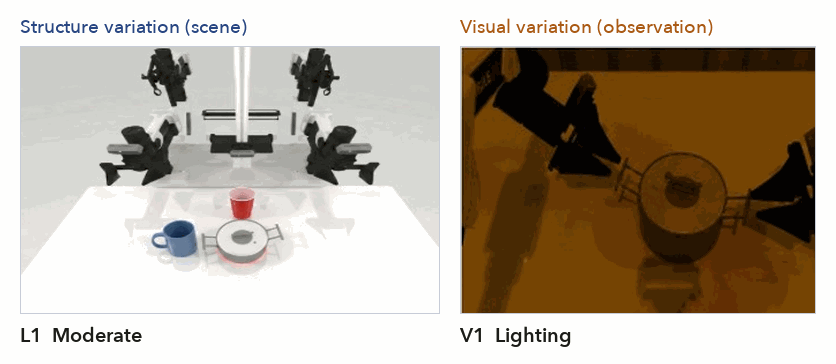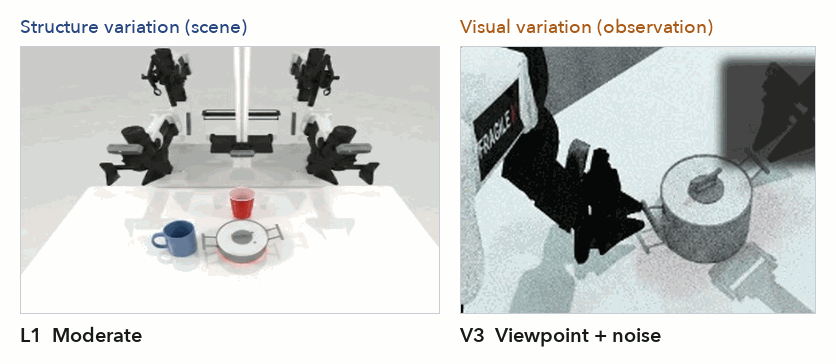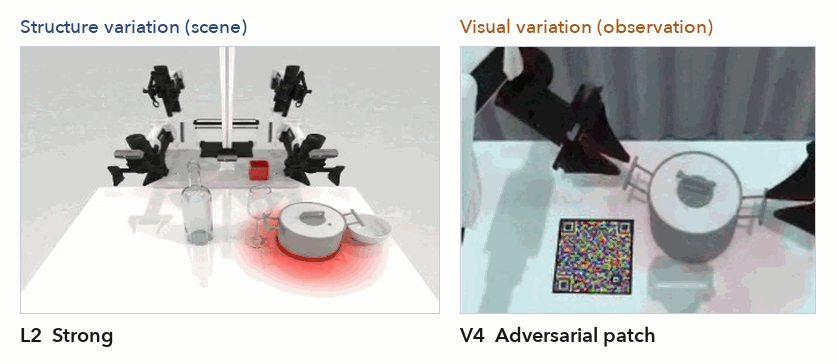
#122026-07-06★ 2.3k +370

dexmal/opendm

Python

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

embodied-aiembodied-intelligenceroboticsvision-language-actionvlaVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#132024-02-29★ 17069

RobotControlStack/robot-control-stack

Python

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for…

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e, xArm, SO101, YAM and Rizon.

frankagymnasiummujocoreinforcement-learningrobot-learningrobot-manipulationsim-to-realvision-language-actions-modelsrobotmanipulationVLAvision-language-actionsim-to-real

兴趣:vision-language-action (VLA) models and foundation models for robots

#142026-08-29★ 10269

OpenBMB/SimpleMemVLA

Python

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

embodied-ailong-horizon-roboticsmultimodal-learningnative-video-memoryrobot-learningrobot-manipulationstreaming-inferencevideo-understandingrobotmanipulationVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#152026-10-20★ 106 +41新项目69

Ta0p1/ResolveLab

Python

Fault-injected tool environments with side-effect grading for evaluating and post-training LLM agents

Fault-injected tool environments with side-effect grading for evaluating and post-training LLM agents

agent-evaluationai-agentsdaggerfastapifault-injectionllm-agentsollamapost-training

兴趣:multi-agent systems and LLM agents

#162026-09-30★ 268 +1668

groundingpi/GroundingPI

Python

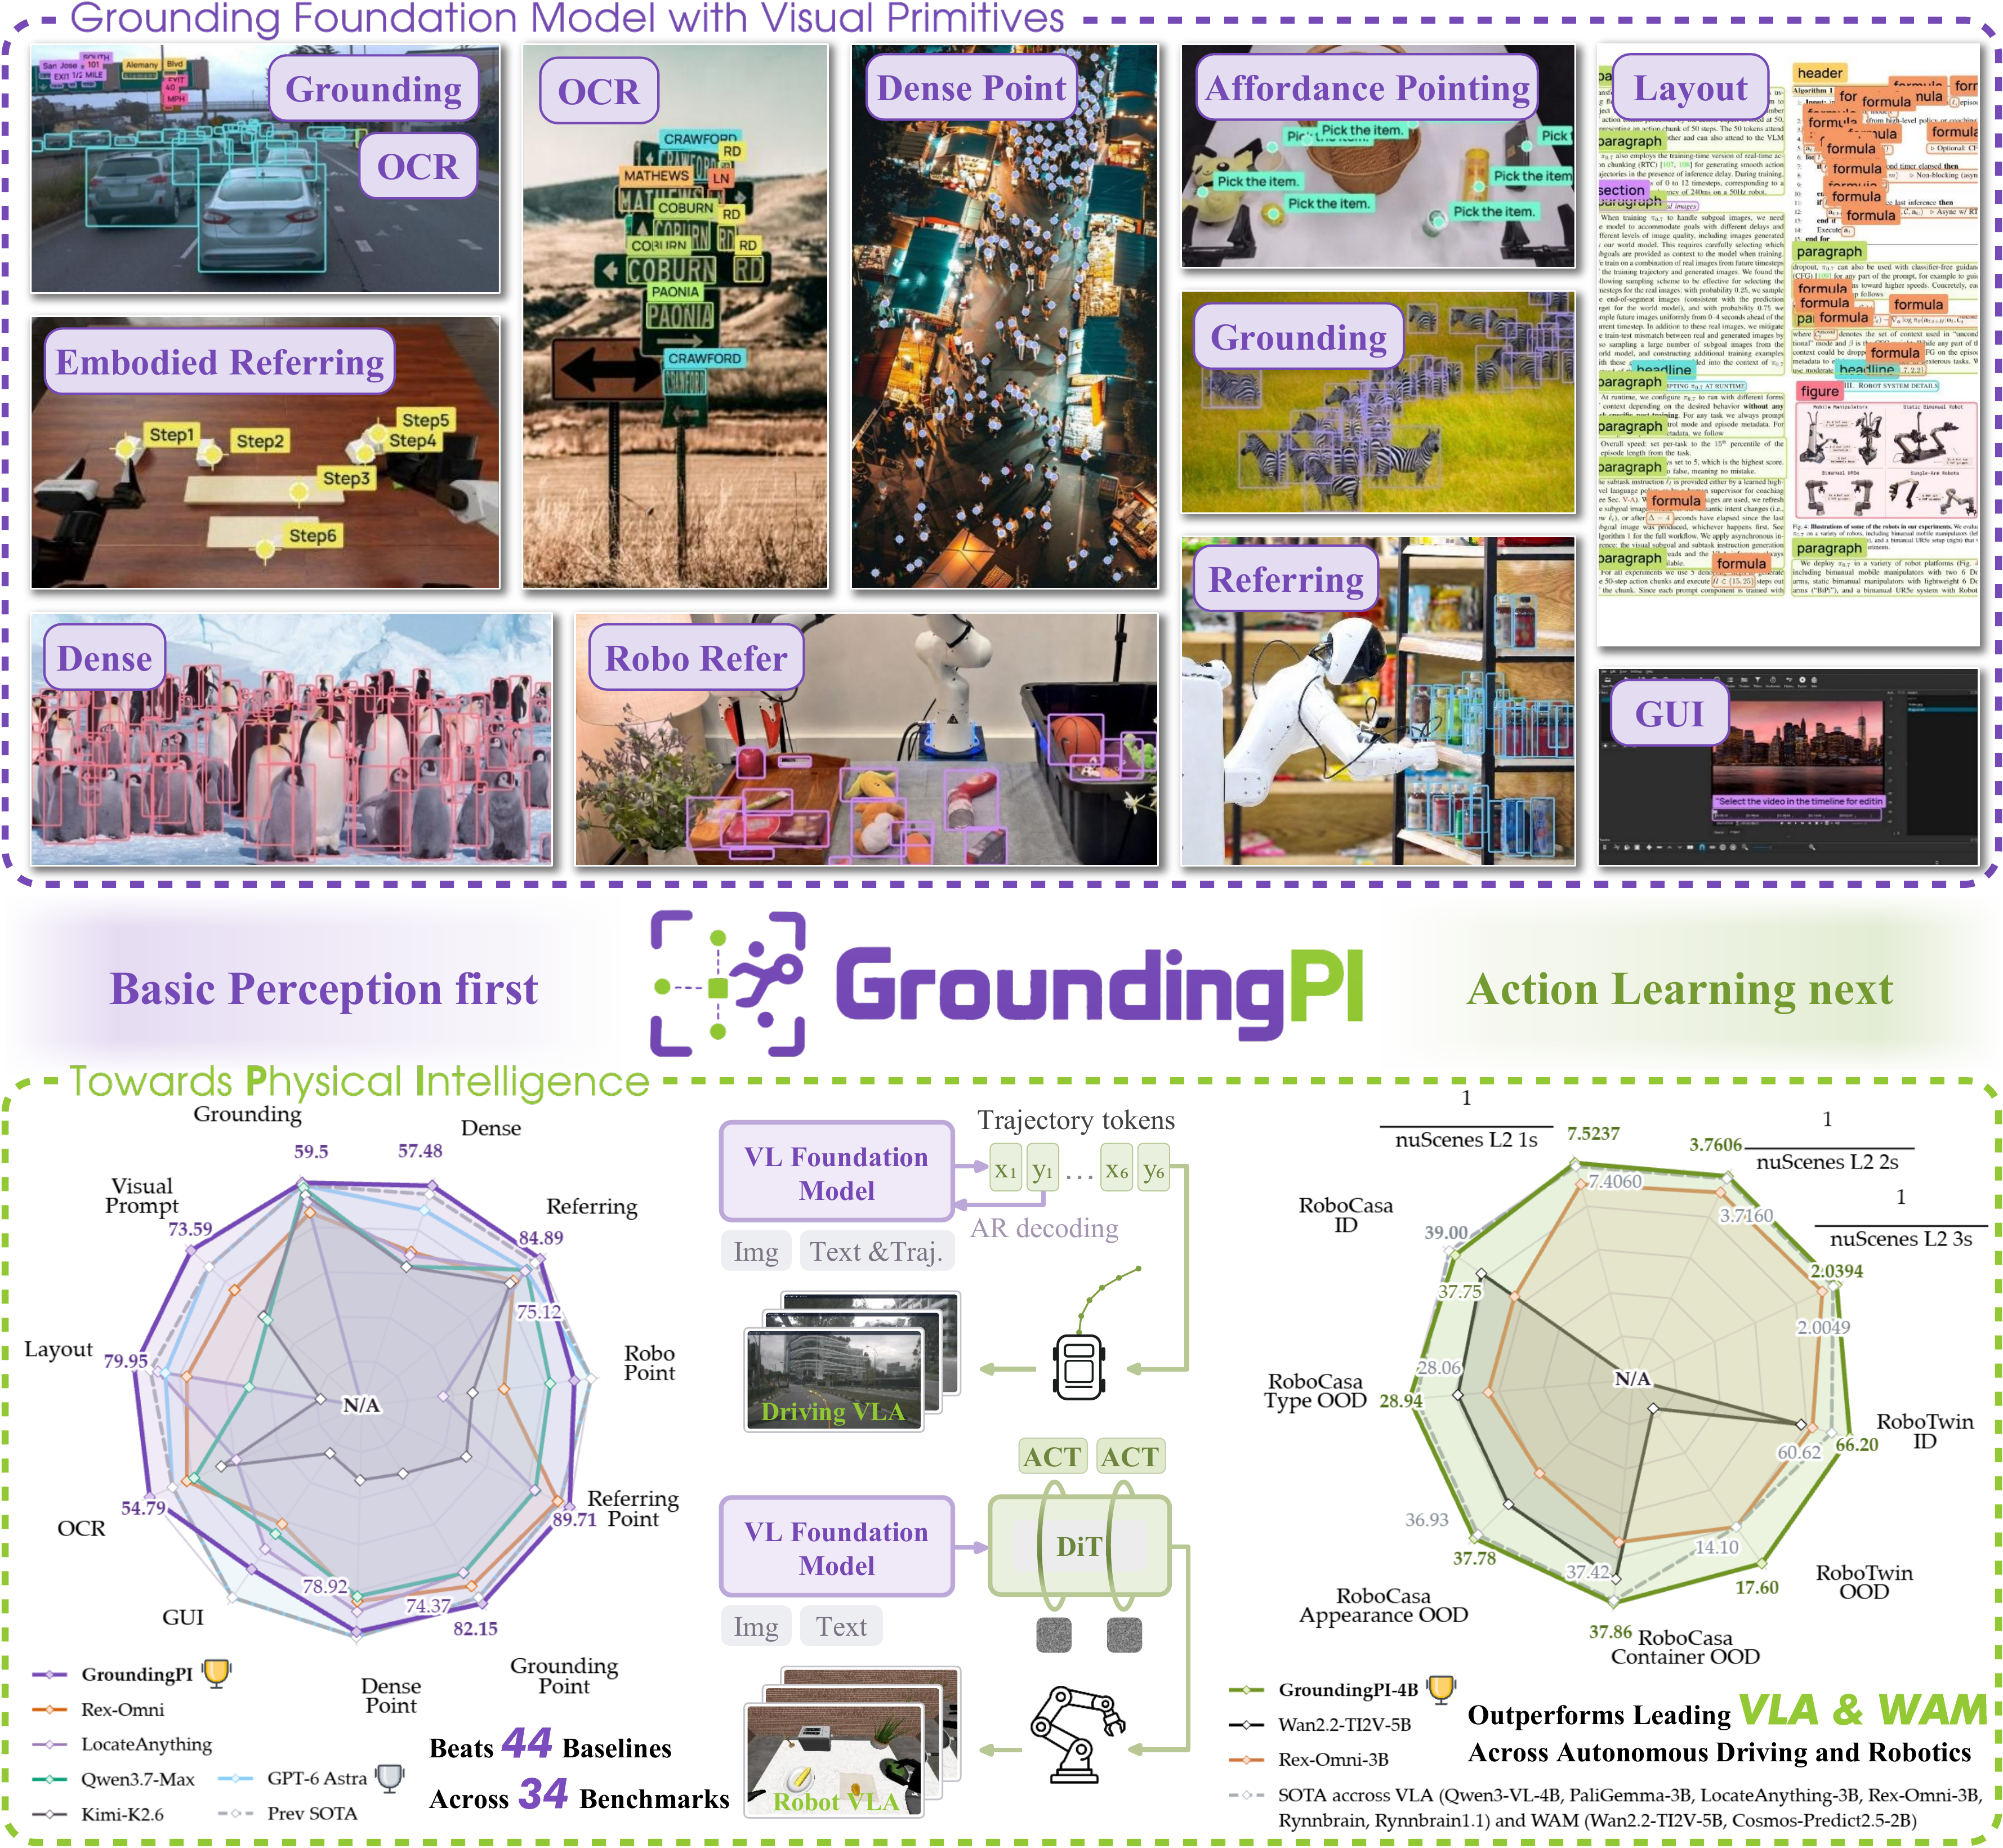
A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and i…

A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and improving robot generalization and data efficiency in controlled evaluations.

embodied-aigui-groundingobject-detectionocrphysical-intelligencepointingrobot-learningvision-language-modelrobotVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#172025-04-04★ 1.9k68

RoboVerseOrg/RoboVerse

Python

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

imitation-learningreinforcement-learningroboticssimulationrobot

兴趣:imitation learning and diffusion policies for robot control

#182024-12-24★ 38768

manumerous/wb_humanoid_mpc

C++

Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control

Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control

aidata-generationhumanoidhumanoid-robotlocomotionmpcnonlinearoptimizationrobotmanipulationhumanoidlocomotion

兴趣:humanoid robots and whole-body control

#192025-09-11★ 7.4k +2368

vllm-project/vllm-omni

Python

A framework for efficient model inference with omni-modality models

A framework for efficient model inference with omni-modality models

audio-generationdiffusionimage-generationinferencemodel-servingmultimodalpytorchtransformer

兴趣:vision-language-action (VLA) models and foundation models for robots
#202026-10-09★ 184 +14新项目68

fendouai/awesome-embodied-ai

Python

2,000 curated embodied AI and robotics resources with bilingual metadata and transparent ranking

2,000 curated embodied AI and robotics resources with bilingual metadata and transparent ranking

awesomeawesome-listbenchmarksdatasetsembodied-aiembodied-intelligencefoundation-modelshumanoid-robotsrobotmanipulationVLAvision-language-actionhumanoidembodied

兴趣:world models and video prediction for embodied agents

#212026-02-08★ 511 +468

XPolicyLab/XPolicyLab

Python

[IROS 26 ScaleInfra Workshop Best Tool Paper] Involving over 50 Advanced Manipulation Policies

[IROS 26 ScaleInfra Workshop Best Tool Paper] Involving over 50 Advanced Manipulation Policies

embodied-aimanipulationpolicymanipulationembodied

兴趣:robot manipulation and grasping with learned policies

#232026-06-29★ 94 +667

Open-X-Humanoid/BICMap

JavaScript

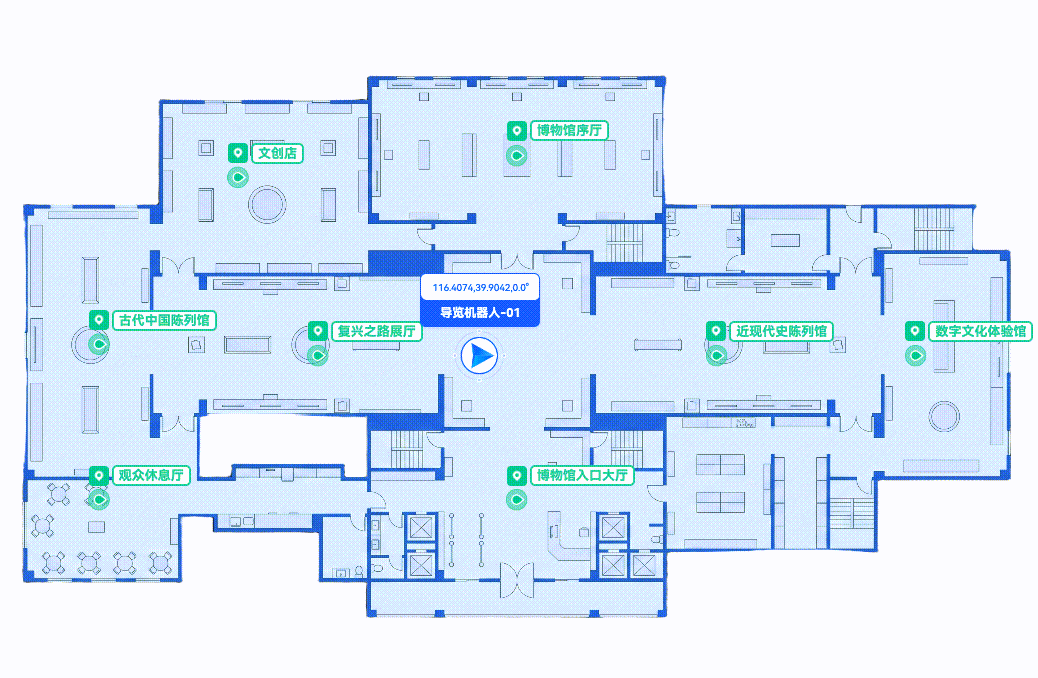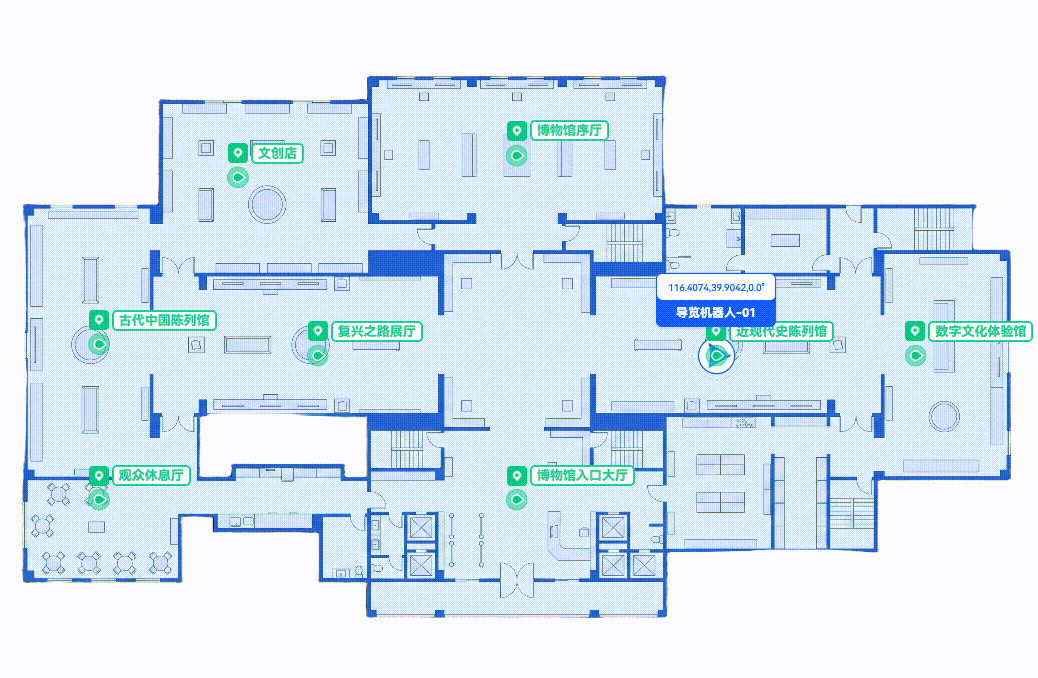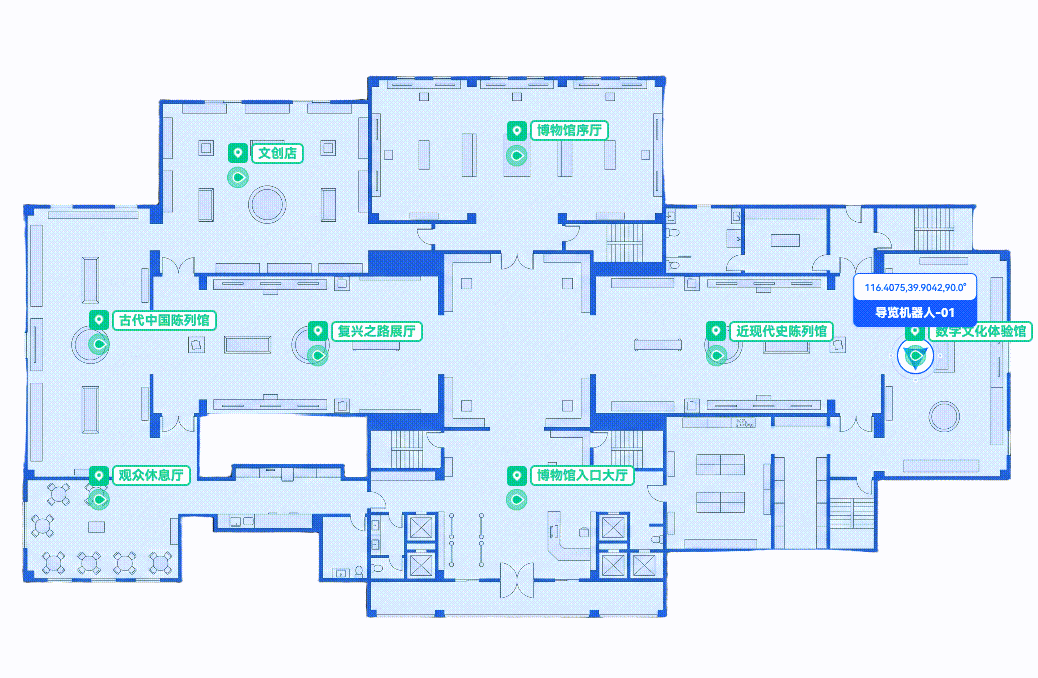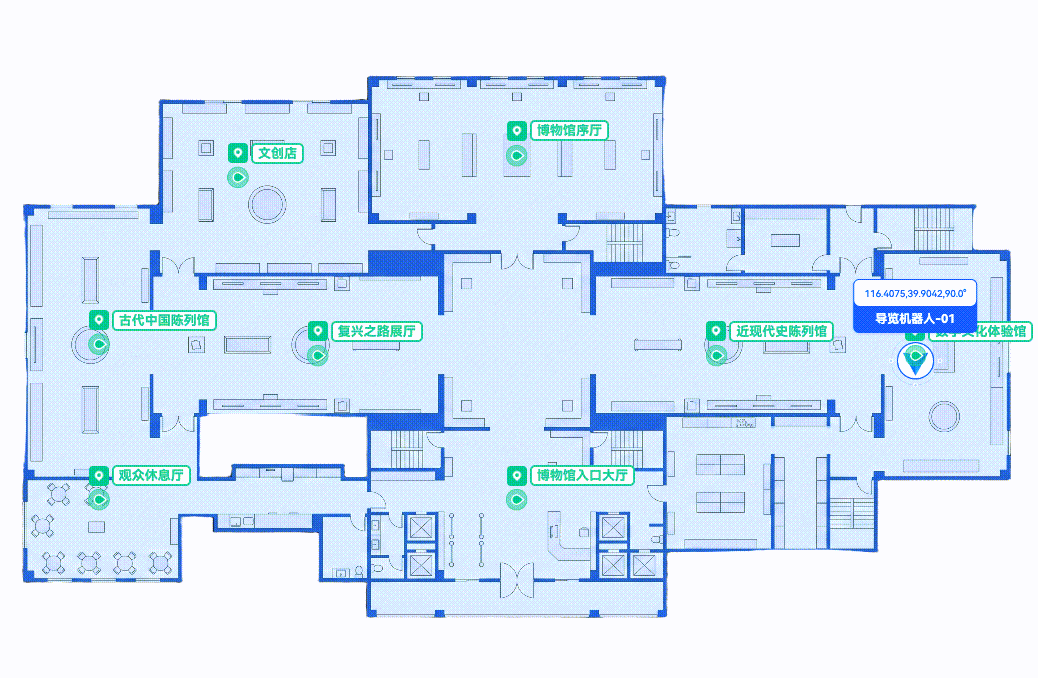
A WebGL-based robotics map visualization SDK for SLAM maps, point clouds, 3D models, and robot navigation.

A WebGL-based robotics map visualization SDK for SLAM maps, point clouds, 3D models, and robot navigation.

3d-visualizationgeojsonhumanoid-robotindoor-outdoormaplibremappingpath-planningpoint-cloudrobothumanoid

兴趣:3D perception, point clouds and scene understanding for robotics

#242022-11-16★ 8.5k +767

isaac-sim/IsaacLab

Python

Unified framework for robot learning with multi-physics/renderer support

Unified framework for robot learning with multi-physics/renderer support

isaac-simomniverse-kit-extensionrobot-learningroboticsrobot

兴趣:3D perception, point clouds and scene understanding for robotics

#252024-05-11★ 1.9k +167

robocasa/robocasa

Python

RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots

RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots

humanoid-robotphysics-simulationrobot-learningroboticsrobothumanoid

兴趣:humanoid robots and whole-body control

#262025-08-14★ 5.6k +466

RLinf/RLinf

Python

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

agentic-aiembodied-aireinforcement-learningrl-infrarlinfvla-rlVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#272026-10-21★ 16 +1新项目66

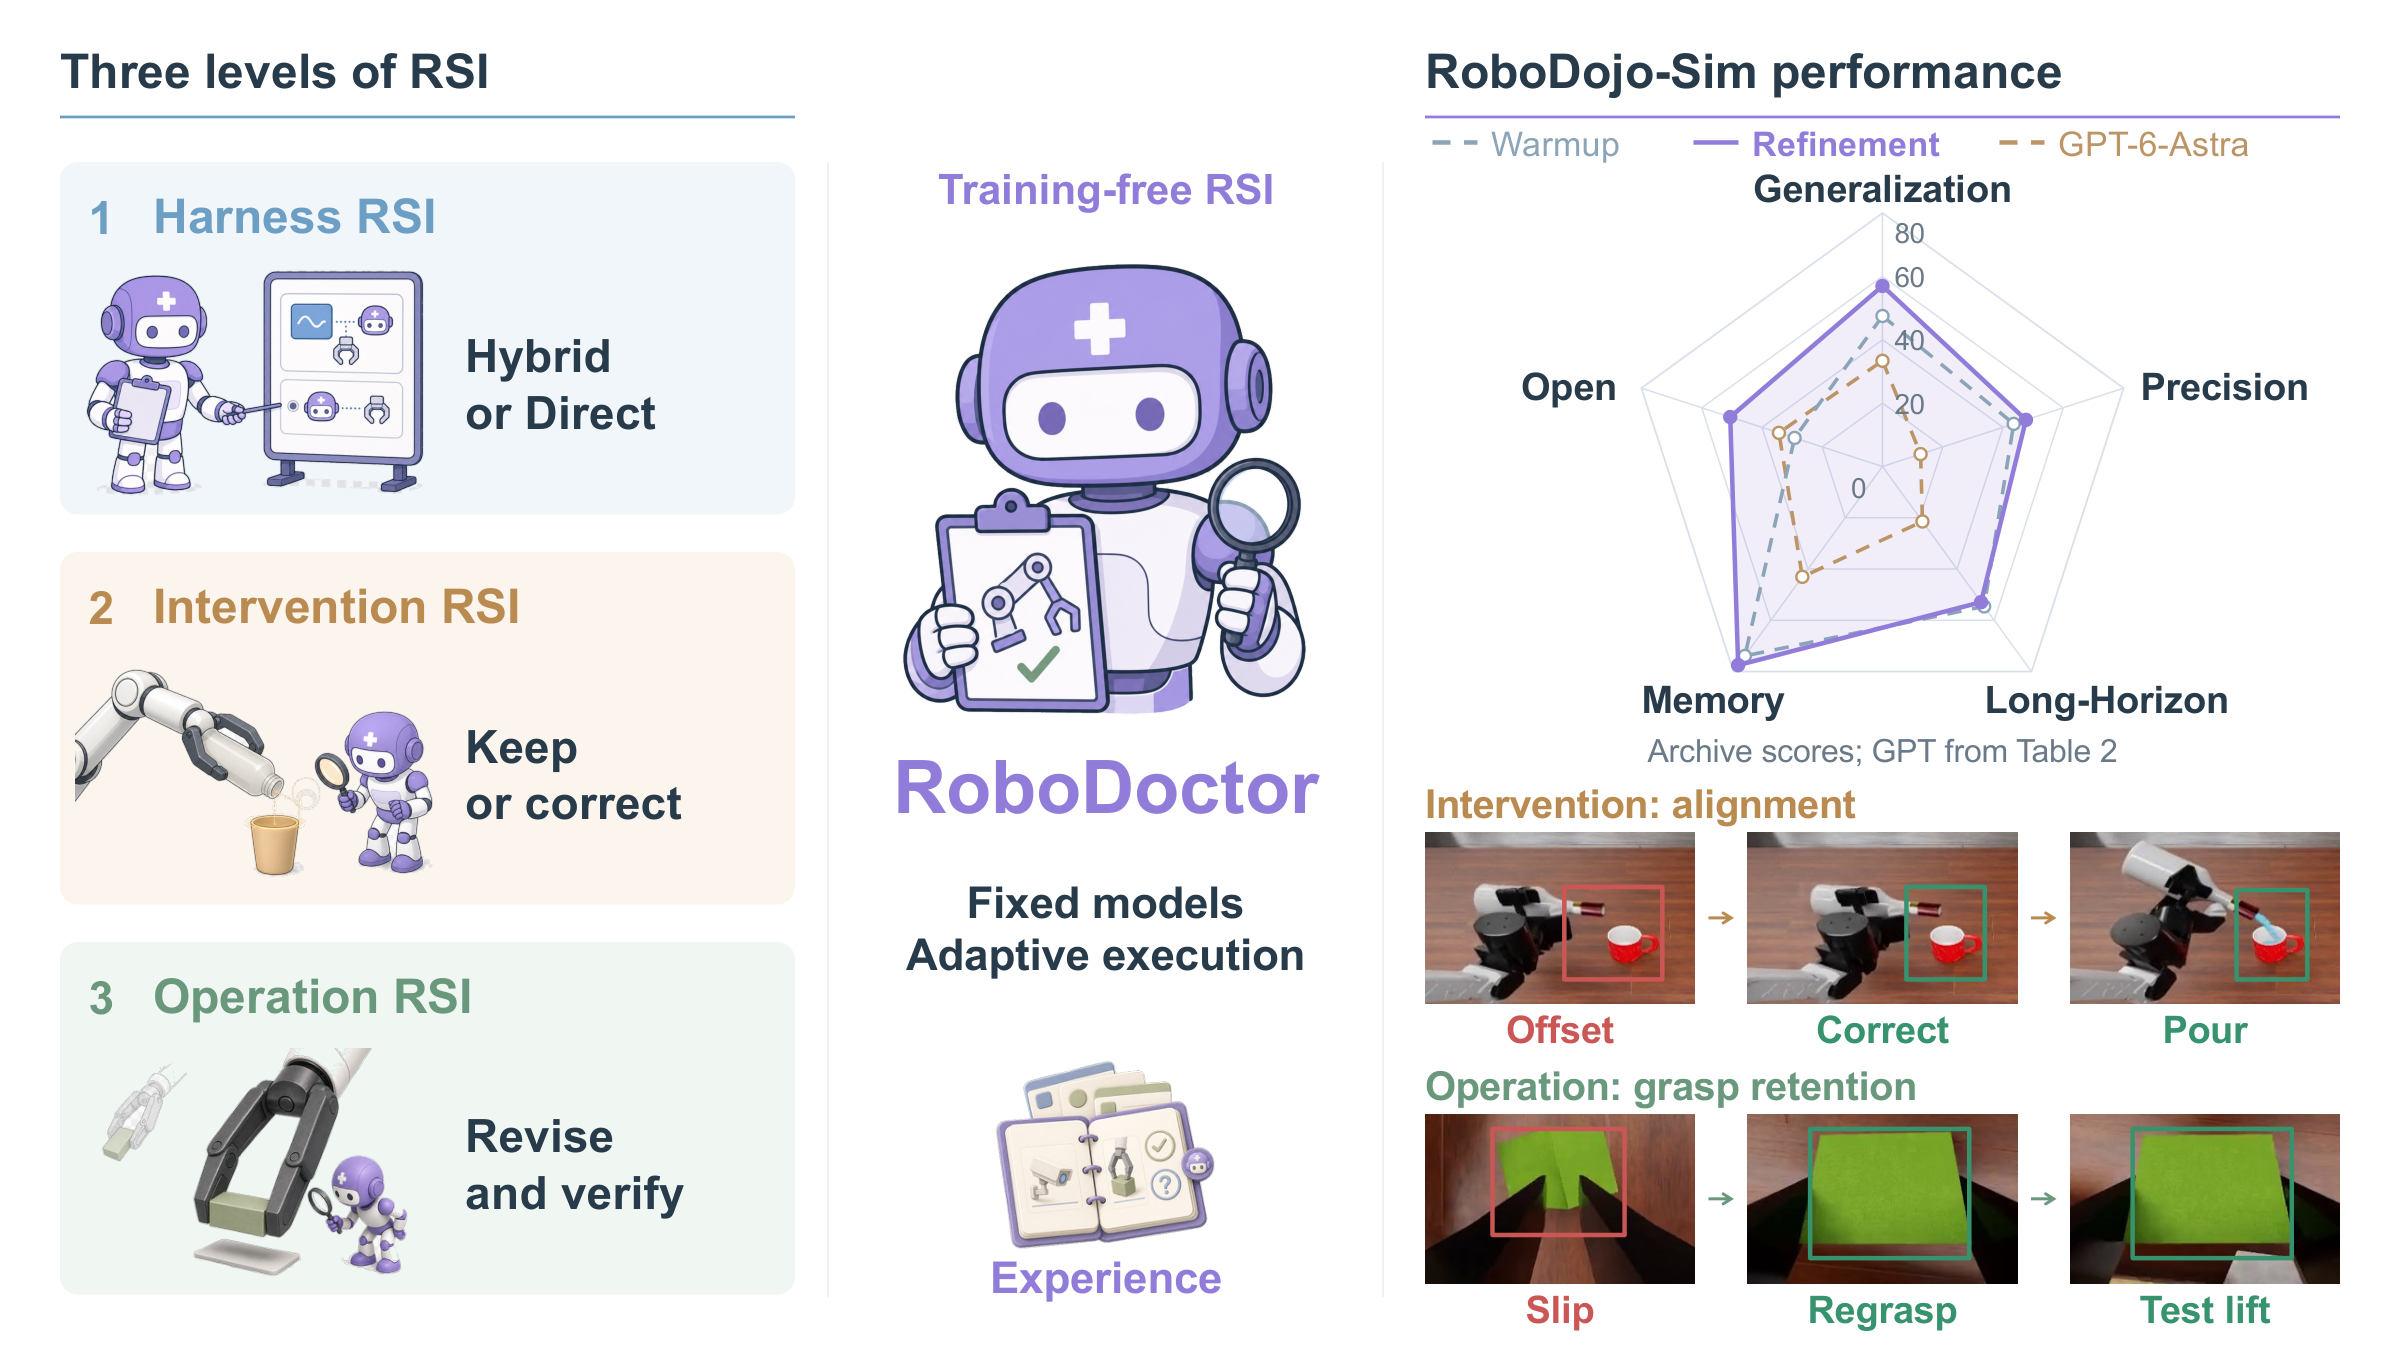
THUSI-Lab/RoboDoctor

Python

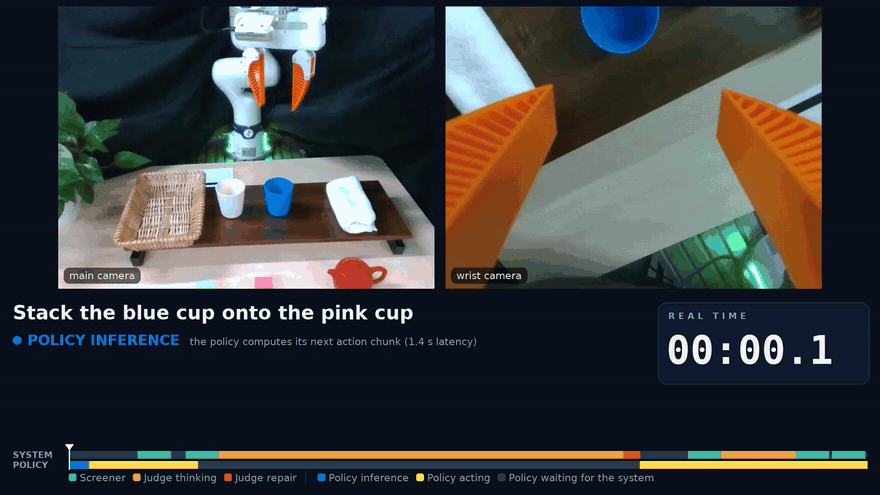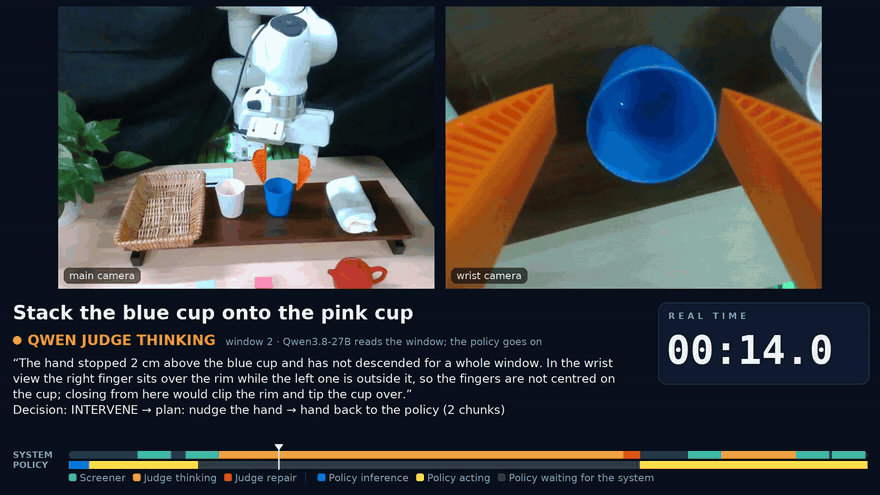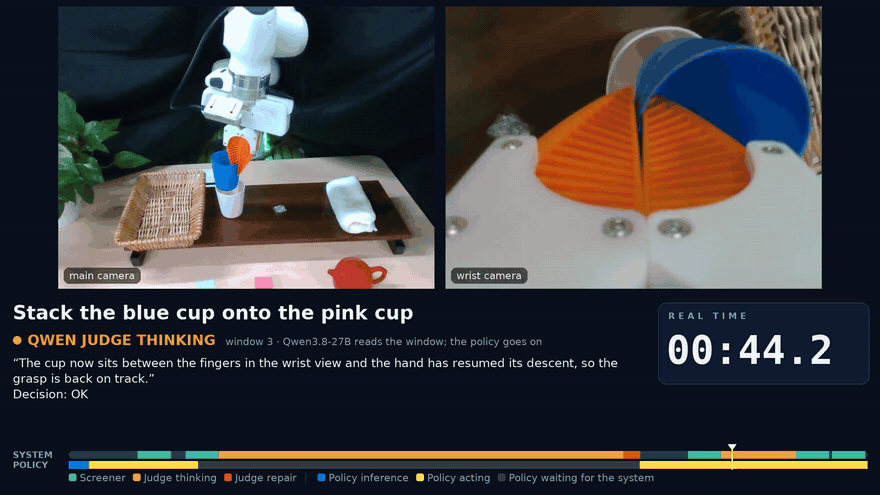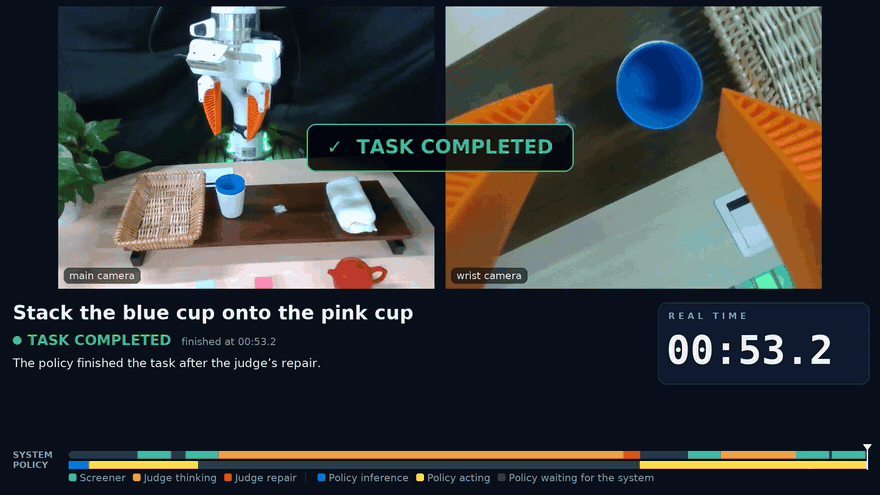
The official code implementation for RoboDoctor: Training-Free Recursive Self-Improvement for Robot Policies

The official code implementation for RoboDoctor: Training-Free Recursive Self-Improvement for Robot Policies

embodied-agentembodied-airecursive-self-improvementroboticsrsirobotembodied

兴趣:imitation learning and diffusion policies for robot control

#282026-09-29★ 168 +366

zqc3117/Spotter

Python

Official codebase for Spotter: Let the Embodied Model Lead, and the VLM Reflect for It

Official codebase for Spotter: Let the Embodied Model Lead, and the VLM Reflect for It

embodied-aillm-agentqwenrobocasarobodojorobot-learningrobot-manipulationroboticsrobotmanipulationembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#292025-07-30★ 75066

HorizonRobotics/HoloMotion

Python

A Foundation Model for Whole-Body Humanoid Control

A Foundation Model for Whole-Body Humanoid Control

foundation-modelshumanoid-robotmotion-trackingroboticswhole-body-controlrobothumanoid

兴趣:humanoid robots and whole-body control

#302026-04-22★ 24.4k +14466

earthtojake/text-to-cad

Python

Design physical products with AI

Design physical products with AI

agentsai-agentscadmechanical-engineeringroboticsstepstlstp

兴趣:humanoid robots and whole-body control