Tech Station

2026-09-26

0 篇论文 · 30 个项目 ← 2026-09-25 · 2026-09-27 →

GitHub 项目

#12026-08-31★ 5.7k +505新项目79

Human-Agent-Society/reef

Python

Infrastructure for continually self‑improving agents

Infrastructure for continually self‑improving agents

agent-infrastructureai-agentscontinual-learninginferencellmllm-trainingreinforcement-learningself-improving-agents

兴趣:multi-agent systems and LLM agents

#22026-07-17★ 14976

phi-monster/Galahad

Python

A counterfactual battery for instruction following in vision-language-action policies: change one word of the instruction, hold the scene, and record which object the arm reaches. …

A counterfactual battery for instruction following in vision-language-action policies: change one word of the instruction, hold the scene, and record which object the arm reaches. Ships the deconfounded demonstration generators and their confounded control.

benchmarkcausal-confusioncounterfactual-evaluationembodied-aiinstruction-followinglanguage-groundingliberolorarobotmanipulationvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#32026-07-02★ 8476

ZJU-OmniAI/vla-corrector

Python

[NeurIPS 2026] VLA-Corrector: Lightweight Detect-and-Correct Inference for Adaptive Action Horizon

[NeurIPS 2026] VLA-Corrector: Lightweight Detect-and-Correct Inference for Adaptive Action Horizon

action-chunkingembodied-ailerobotneurips-2026robot-learningrobot-manipulationroboticsvision-language-actionrobotmanipulationVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#42026-08-26★ 344 +573

OpenMOSS/EasyWAM

Python

A unified framework for training, fine-tuning, and evaluating World Action Models

A unified framework for training, fine-tuning, and evaluating World Action Models

benchmarkcodebaseembodied-aifoundation-modelsloraroboticsvision-language-actionworld-action-modelvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#52026-08-07★ 7.9k73

deeplethe/utopia

Rust

World's first open-source enterprise world model.

World's first open-source enterprise world model.

agent-memorybitemporalgraphragknowledge-baseknowledge-graphllmontologypgvectorworld model

兴趣:multi-agent systems and LLM agents

#62025-10-09★ 3.7k +373

starVLA/starVLA

Python

StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing

StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing

robotic-foundation-modelroboticsvision-language-action-modelworld-action-modelvision-language-action

兴趣:vision-language-action (VLA) models and foundation models for robots

#72026-08-29★ 76 +1新项目72

OpenBMB/SimpleMemVLA

Python

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

embodied-ailong-horizon-roboticsmultimodal-learningnative-video-memoryrobot-learningrobot-manipulationstreaming-inferencevideo-understandingrobotmanipulationVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#82026-07-19★ 604 +272

RealXiaoze/humanoid-motion-intelligence

人形机器人运动智能论文、开源项目、产业与求职知识库

人形机器人运动智能论文、开源项目、产业与求职知识库

embodied-aihumanoid-roboticslocomotionmotion-controlreinforcement-learningrobot-learningsim2realvlarobotVLAhumanoidlocomotionembodied

兴趣:humanoid robots and whole-body control

#92026-03-18★ 57.9k +78872

rohitg00/ai-engineering-from-scratch

Python

Learn it. Build it. Ship it for others.

Learn it. Build it. Ship it for others.

agentsaiai-agentsai-engineeringcomputer-visioncoursedeep-learningfrom-scratch

兴趣:multi-agent systems and LLM agents

#102024-12-08★ 3.9k +571

datawhalechina/every-embodied

Python

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

embodied-agentembodied-aiembodied-intelligenceopenvlasmolvlavision-language-action-modelVLAvision-language-actionembodied

兴趣:world models and video prediction for embodied agents

#112025-11-23★ 653 +171

sou350121/VLA-Handbook

HTML

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

chinesedeep-learningembodied-aillmrobot-learningroboticsvision-language-actionvlarobotVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#122024-01-26★ 27.8k +1670

huggingface/lerobot

Python

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

兴趣:imitation learning and diffusion policies for robot control

#132024-02-29★ 16169

RobotControlStack/robot-control-stack

Python

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for…

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e, xArm, SO101 and YAM.

frankagymnasiummujocoreinforcement-learningrobot-learningrobot-manipulationsim-to-realvision-language-actions-modelsrobotmanipulationVLAvision-language-actionsim-to-real

兴趣:vision-language-action (VLA) models and foundation models for robots
#142026-08-20★ 114 +469

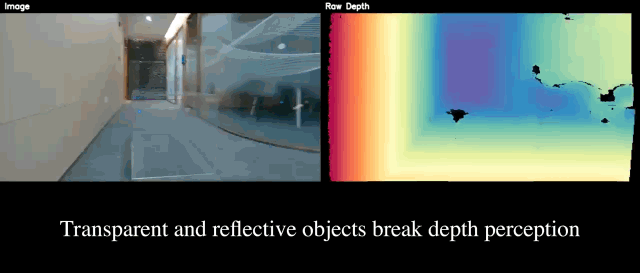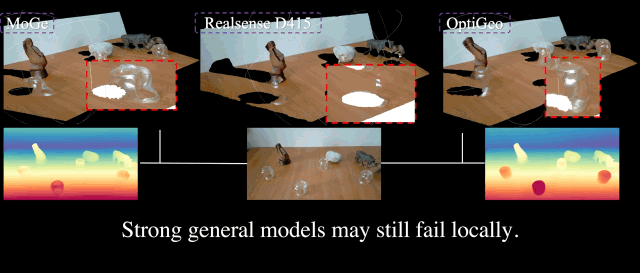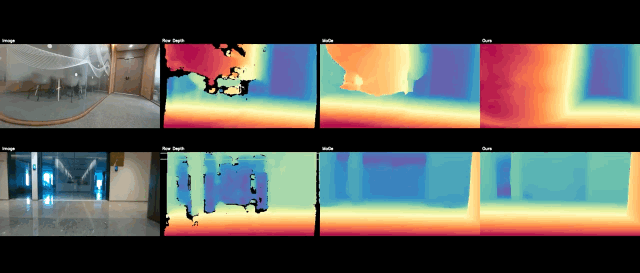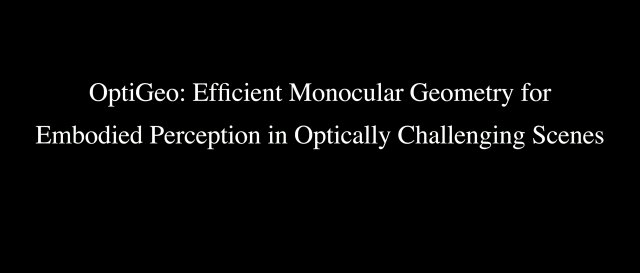
mx-liu6/OptiGeo

Python

[CORL2026] Official implementation of the paper: "OptiGeo: Efficient Monocular Geometry for Embodied Perception in Optically Challenging Scenes"

[CORL2026] Official implementation of the paper: "OptiGeo: Efficient Monocular Geometry for Embodied Perception in Optically Challenging Scenes"

depth-estimationembodied-aigeometry-estimationembodied

兴趣:3D perception, point clouds and scene understanding for robotics

#152025-08-14★ 5.4k +669

RLinf/RLinf

Python

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

agentic-aiembodied-aireinforcement-learningrl-infrarlinfvla-rlVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#162025-04-04★ 1.9k69

RoboVerseOrg/RoboVerse

Python

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

imitation-learningreinforcement-learningroboticssimulationrobot

兴趣:imitation learning and diffusion policies for robot control

#172025-09-09★ 51.1k +19769

bojieli/ai-agent-book

Python

《深入理解 AI Agent:设计原理与工程实践》(李博杰 著)开源主仓库:全书正文、编译版 PDF 与按章配套代码

《深入理解 AI Agent:设计原理与工程实践》(李博杰 著)开源主仓库:全书正文、编译版 PDF 与按章配套代码

agentagent-memoryai-agentbookcoding-agentcontext-engineeringlarge-language-modelsllm

兴趣:multi-agent systems and LLM agents

#182026-07-06★ 2.2k +-4968

dexmal/opendm

Python

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

embodied-aiembodied-intelligenceroboticsvision-language-actionvlaVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#192026-09-22★ 15新项目67

shapsider/OmniJev

Python

OmniJev — multimodal finite-choice decision interface and MuJoCo embodied workbench: trajectory replays, decision probes, benchmark panels, 60s walkthrough.

OmniJev — multimodal finite-choice decision interface and MuJoCo embodied workbench: trajectory replays, decision probes, benchmark panels, 60s walkthrough.

decision-makingembodied-aimujocomultimodalroboticsvlmembodied

兴趣:world models and video prediction for embodied agents

#202024-09-29★ 3.5k +467

enactic/openarm

MDX

A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.

A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.

bilateral-teleoperationforce-feedbackgenesisgravity-compensationhumanoid-robotimitation-learningmachine-learningmoveit2robothumanoid

兴趣:humanoid robots and whole-body control

#212026-09-15★ 38 +13新项目67

1173591564/Dynamics-memory

TypeScript

LLM agent 的有界自纠错长期记忆层:把连续、含矛盾的项目交互日志蒸馏成有界、可自更新的记忆库。Bounded, self-correcting long-term memory for LLM agents — candidate pool + value dynamics + tension adjudication + causal-replay…

LLM agent 的有界自纠错长期记忆层:把连续、含矛盾的项目交互日志蒸馏成有界、可自更新的记忆库。Bounded, self-correcting long-term memory for LLM agents — candidate pool + value dynamics + tension adjudication + causal-replay evals.

agent-memoryagentsllmllm-agentslong-term-memorymemorymemory-managementpythonLLM agent

兴趣:multi-agent systems and LLM agents

#222022-11-16★ 8.2k +566

isaac-sim/IsaacLab

Python

Unified framework for robot learning with multi-physics/renderer support

Unified framework for robot learning with multi-physics/renderer support

isaac-simomniverse-kit-extensionrobot-learningroboticsrobot

兴趣:3D perception, point clouds and scene understanding for robotics

#232026-06-26★ 606 +266

robocurve/inspect-robots

Python

Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.

Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.

benchmarkembodied-aievaluationphysical-airerunroboticsvision-language-actionvlaVLAvision-language-actionhumanoidembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#242026-02-21★ 21966

RoboTwin-Platform/RMBench

Python

Memory-Dependent Manipulation Benchmark based on RoboTwin

Memory-Dependent Manipulation Benchmark based on RoboTwin

benchmarkembodied-aimanipulationmemoryroboticsmanipulationembodied

兴趣:robot manipulation and grasping with learned policies

#252026-04-22★ 16.4k +2966

earthtojake/text-to-cad

Python

A library of agent skills for CAD, CAE and CAM

A library of agent skills for CAD, CAE and CAM

agentsai-agentscadmechanical-engineeringroboticsstepstlstp

兴趣:large language models for robot task planning and reasoning

#262026-04-16★ 1.4k +266

OpenMOSS/Awesome-WAM

HTML

A curated collection of papers, explainers, and resources on World Action Models for embodied AI

A curated collection of papers, explainers, and resources on World Action Models for embodied AI

awesome-listembodied-aipaper-listroboticssurveyvision-language-actionworld-action-modelworld-modelsvision-language-actionembodied

兴趣:world models and video prediction for embodied agents

#272026-09-06★ 890 +7新项目66

OpenWAM-Official/OpenWAM

Python

Official repository for "OpenWAM: An Open, Modular Exploration Towards Systematic World–Action Model Pretraining".

Official repository for "OpenWAM: An Open, Modular Exploration Towards Systematic World–Action Model Pretraining".

generalist-robot-policiespretrainingroboticsworld-action-modelrobot

兴趣:vision-language-action (VLA) models and foundation models for robots
#282024-10-31★ 23.6k +2565

verl-project/verl

Python

verl/HybridFlow: A Flexible and Efficient RL Post-Training Framework

verl/HybridFlow: A Flexible and Efficient RL Post-Training Framework

兴趣:vision-language-action (VLA) models and foundation models for robots

#292024-05-11★ 1.8k65

robocasa/robocasa

Python

RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots

RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots

humanoid-robotphysics-simulationrobot-learningroboticsrobothumanoid

兴趣:humanoid robots and whole-body control

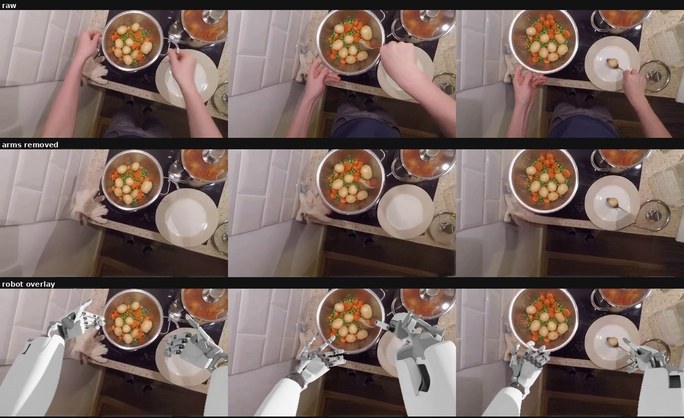
#302026-09-12★ 44新项目65

3587jjh/HuRo

Python

HuRo: Robotizing Human Videos for Scalable VLA Pretraining (CoRL 2026)

HuRo: Robotizing Human Videos for Scalable VLA Pretraining (CoRL 2026)

egocentric-videomotion-retargetingrobot-learningrobotizationvision-language-actionvlarobotVLAvision-language-action

兴趣:vision-language-action (VLA) models and foundation models for robots