Tech Station

2026-10-18

0 篇论文 · 30 个项目 ← 2026-10-17 · 2026-10-19 →

GitHub 项目

#12025-10-08★ 2.4k83

xbpeng/MimicKit

Python

A lightweight suite of motion imitation methods for training controllers.

A lightweight suite of motion imitation methods for training controllers.

animationmotion-imitationreinforcement-learningrobotics

兴趣:imitation learning and diffusion policies for robot control

#22026-10-05★ 171 +2新项目75

AetherLabsAI/Video2World

Python

Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective

Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective

benchmarkcoding-agentembodied-aifoundation-modelsreal-to-simrobot-learningroboticssimulationrobotembodied

兴趣:world models and video prediction for embodied agents

#32026-09-30★ 119 +16新项目73

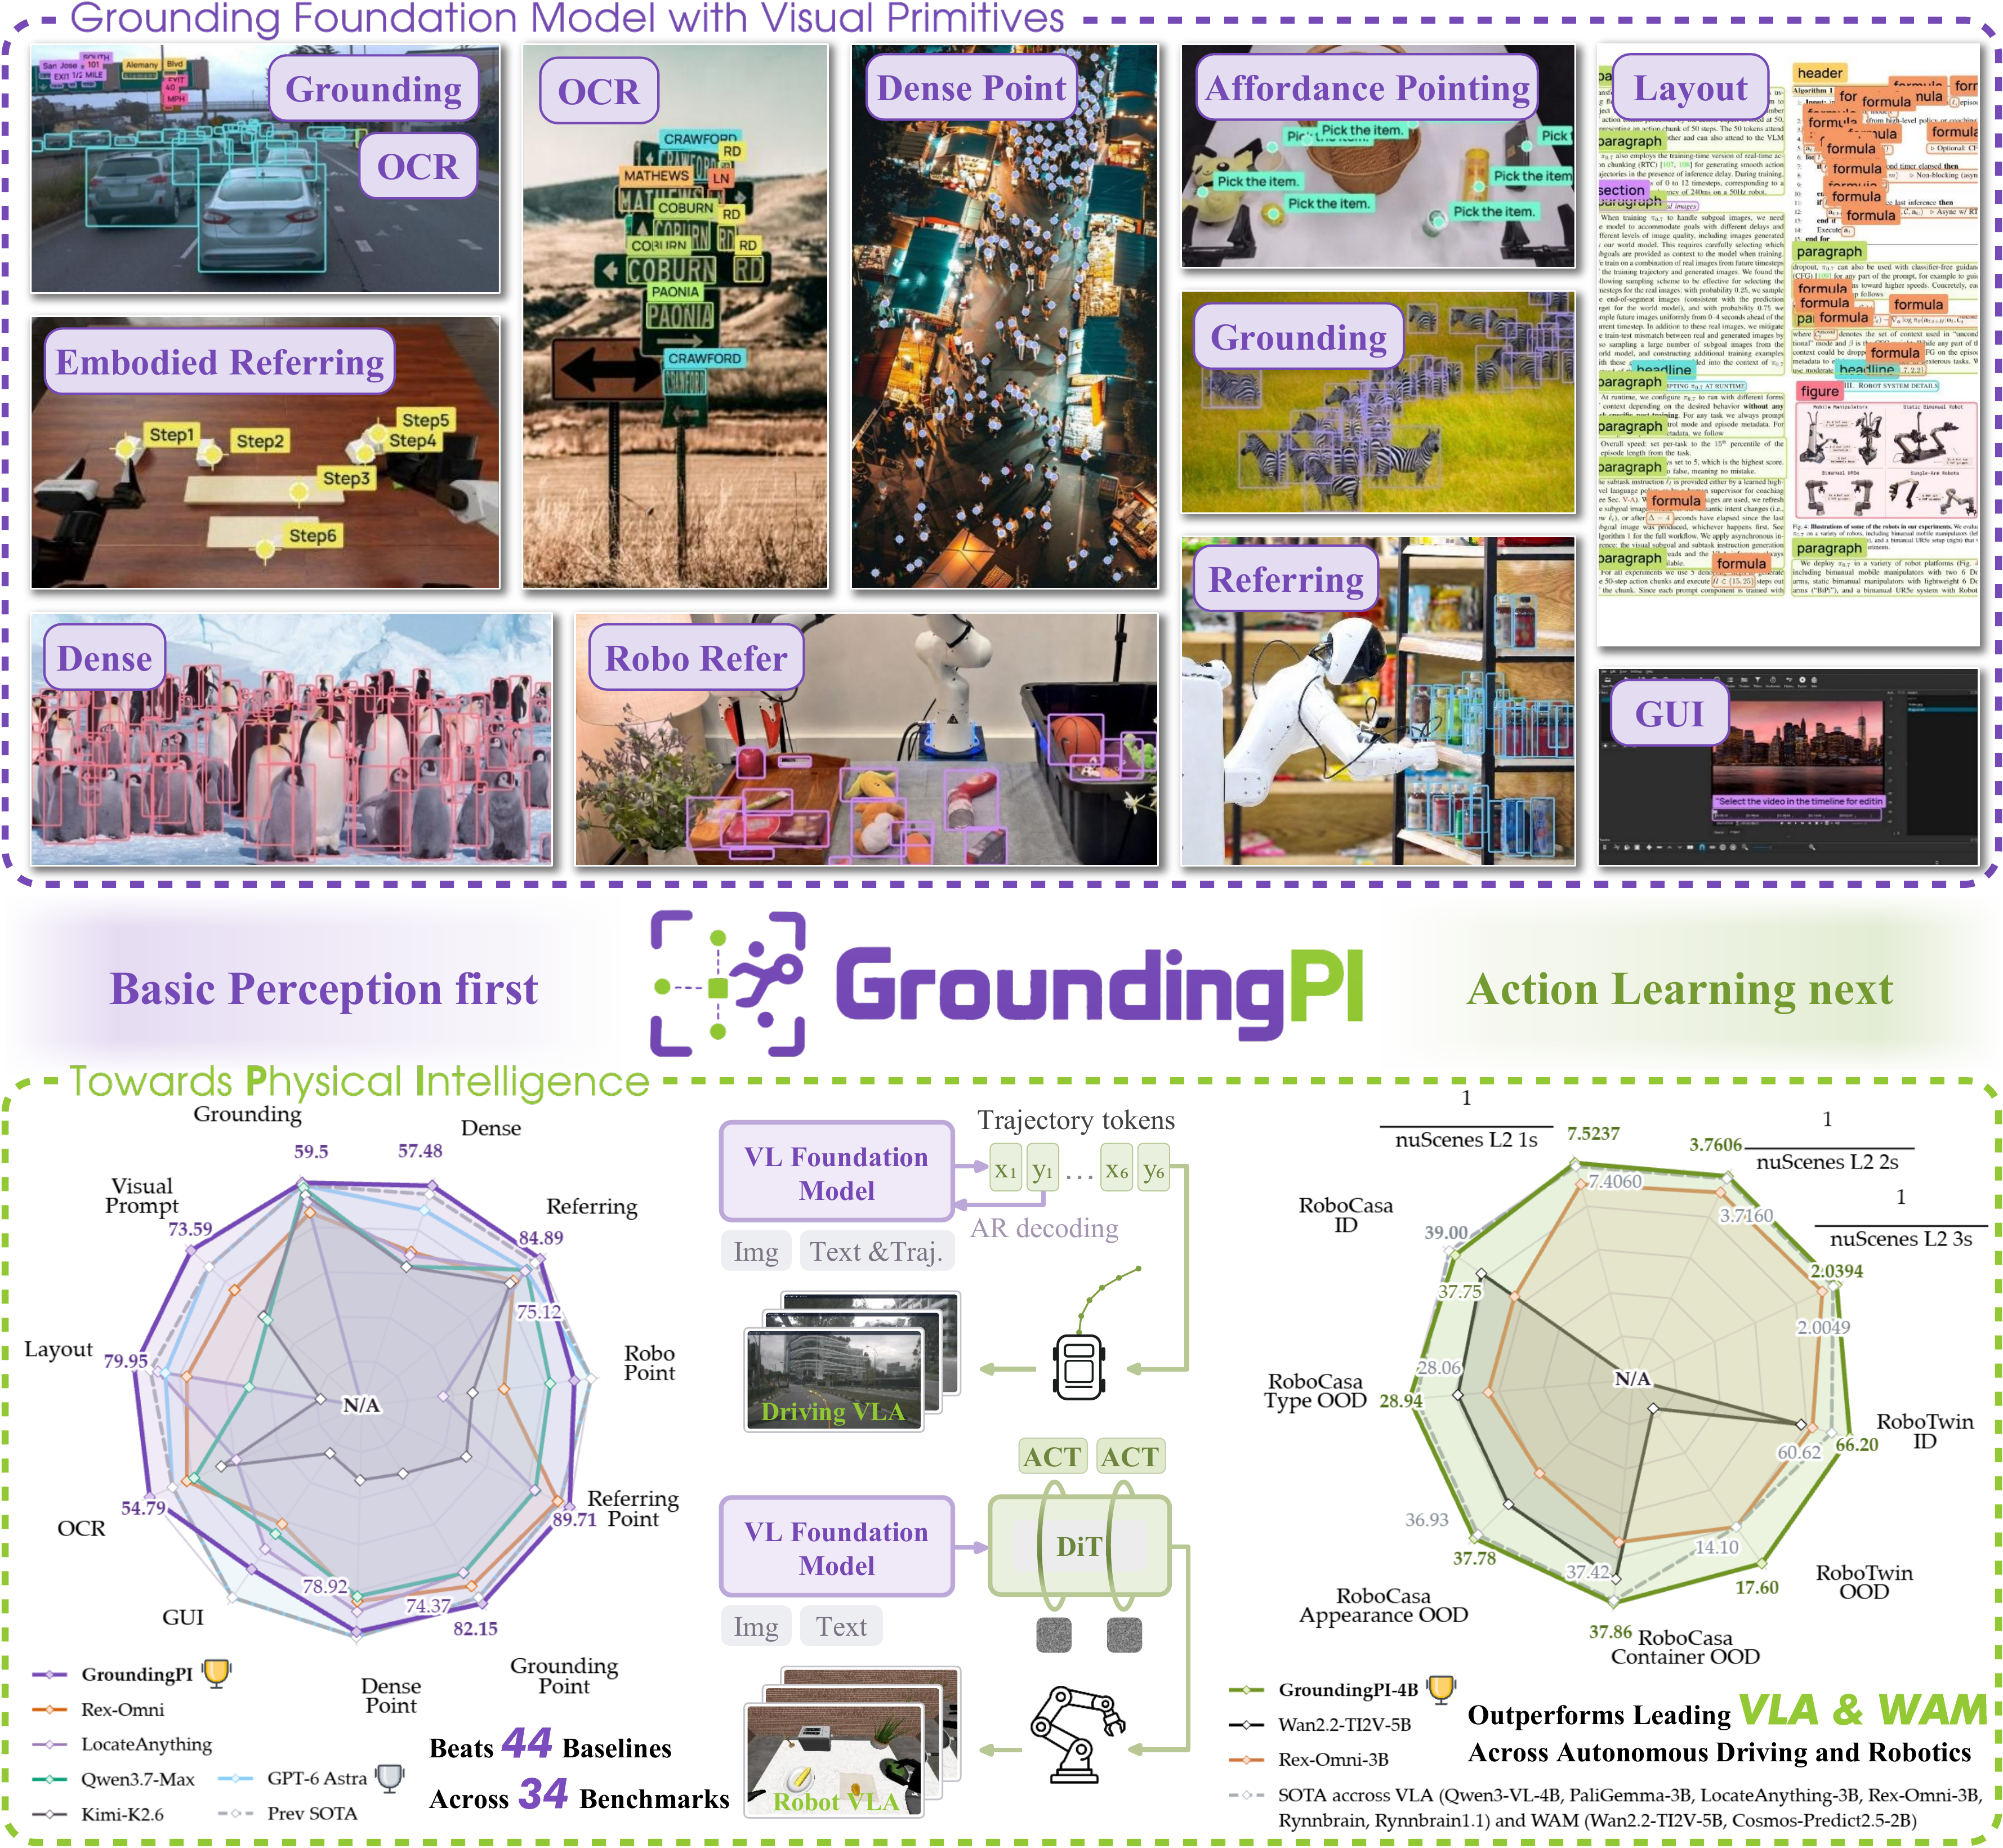
groundingpi/GroundingPI

Python

A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and i…

A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and improving robot generalization and data efficiency in controlled evaluations.

embodied-aigui-groundingobject-detectionocrphysical-intelligencepointingrobot-learningvision-language-modelrobotVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#42024-12-08★ 4.1k +973

datawhalechina/every-embodied

Jupyter Notebook

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

embodied-agentembodied-aiembodied-intelligenceopenvlasmolvlavision-language-action-modelVLAvision-language-actionembodied

兴趣:world models and video prediction for embodied agents

#52024-01-26★ 28.3k +2372

huggingface/lerobot

Python

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

兴趣:imitation learning and diffusion policies for robot control

#62026-08-29★ 90 +172

OpenBMB/SimpleMemVLA

Python

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

embodied-ailong-horizon-roboticsmultimodal-learningnative-video-memoryrobot-learningrobot-manipulationstreaming-inferencevideo-understandingrobotmanipulationVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#72024-12-24★ 38372

manumerous/wb_humanoid_mpc

C++

Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control

Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control

aidata-generationhumanoidhumanoid-robotlocomotionmpcnonlinearoptimizationrobotmanipulationhumanoidlocomotion

兴趣:humanoid robots and whole-body control

#92026-08-26★ 403 +271

OpenMOSS/EasyWAM

Python

A unified framework for training, fine-tuning, and evaluating World Action Models

A unified framework for training, fine-tuning, and evaluating World Action Models

benchmarkcodebaseembodied-aifoundation-modelsloraroboticsvision-language-actionworld-action-modelvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#102025-11-23★ 716 +171

sou350121/VLA-Handbook

HTML

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

chinesedeep-learningembodied-aillmrobot-learningroboticsvision-language-actionvlarobotVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#112026-10-04★ 61 +5新项目70

Roboparty/P-BFM

Python

Perceptive behavioral foundation models for terrain-adaptive humanoid control: motion tracking, goal reaching, reward inference and teleoperation.

Perceptive behavioral foundation models for terrain-adaptive humanoid control: motion tracking, goal reaching, reward inference and teleoperation.

behavioral-foundation-modelshumanoid-controlmjlabmujocoperceptionreinforcement-learningteleoperationunsupervised-learninghumanoid

兴趣:humanoid robots and whole-body control

#122026-07-06★ 2.3k +170

dexmal/opendm

Python

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

embodied-aiembodied-intelligenceroboticsvision-language-actionvlaVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#132026-10-07★ 249 +27新项目70

fudan-generative-vision/Remory

Python

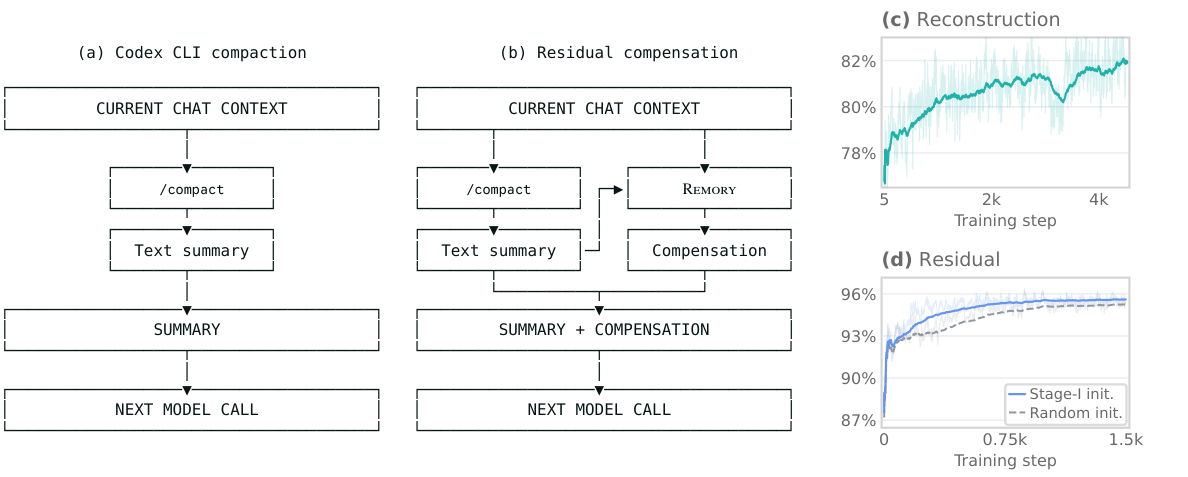
Remory: Learning Residual Memory for Context Compaction

Remory: Learning Residual Memory for Context Compaction

context-compactioninferencellm-agentsresidual-memory

兴趣:world models and video prediction for embodied agents

#142025-10-09★ 3.8k +370

starVLA/starVLA

Python

StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing

StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing

robotic-foundation-modelroboticsvision-language-action-modelworld-action-modelvision-language-action

兴趣:vision-language-action (VLA) models and foundation models for robots

#152026-04-22★ 21.4k +22870

earthtojake/text-to-cad

Python

Give your agent CAD superpowers.

Give your agent CAD superpowers.

agentsai-agentscadmechanical-engineeringroboticsstepstlstp

兴趣:multi-agent systems and LLM agents

#162026-08-14★ 1.6k +22769

soumatheusgomes/vibe-coding-toolkit

JavaScript

A curated, battle-tested AI-coding toolkit: Claude Code plugins, subagent orchestration, quality gates, and ready-to-copy prompts, extracted from real production use.

A curated, battle-tested AI-coding toolkit: Claude Code plugins, subagent orchestration, quality gates, and ready-to-copy prompts, extracted from real production use.

ai-agentsai-codingclaude-codedeveloper-toolsllm-agentsprompts

兴趣:multi-agent systems and LLM agents

#172024-02-29★ 16669

RobotControlStack/robot-control-stack

Python

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for…

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e, xArm, SO101 and YAM.

frankagymnasiummujocoreinforcement-learningrobot-learningrobot-manipulationsim-to-realvision-language-actions-modelsrobotmanipulationVLAvision-language-actionsim-to-real

兴趣:vision-language-action (VLA) models and foundation models for robots

#182026-10-15★ 15新项目69

RM-Arena/Arena-1

Python

A RoboMaster-inspired arena for agent strategy, programming and multi-robot cooperation · Non-commercial learning only

A RoboMaster-inspired arena for agent strategy, programming and multi-robot cooperation · Non-commercial learning only

electronroboticssimulationsource-availablerobot

兴趣:multi-agent systems and LLM agents

#192026-09-02★ 88 +969

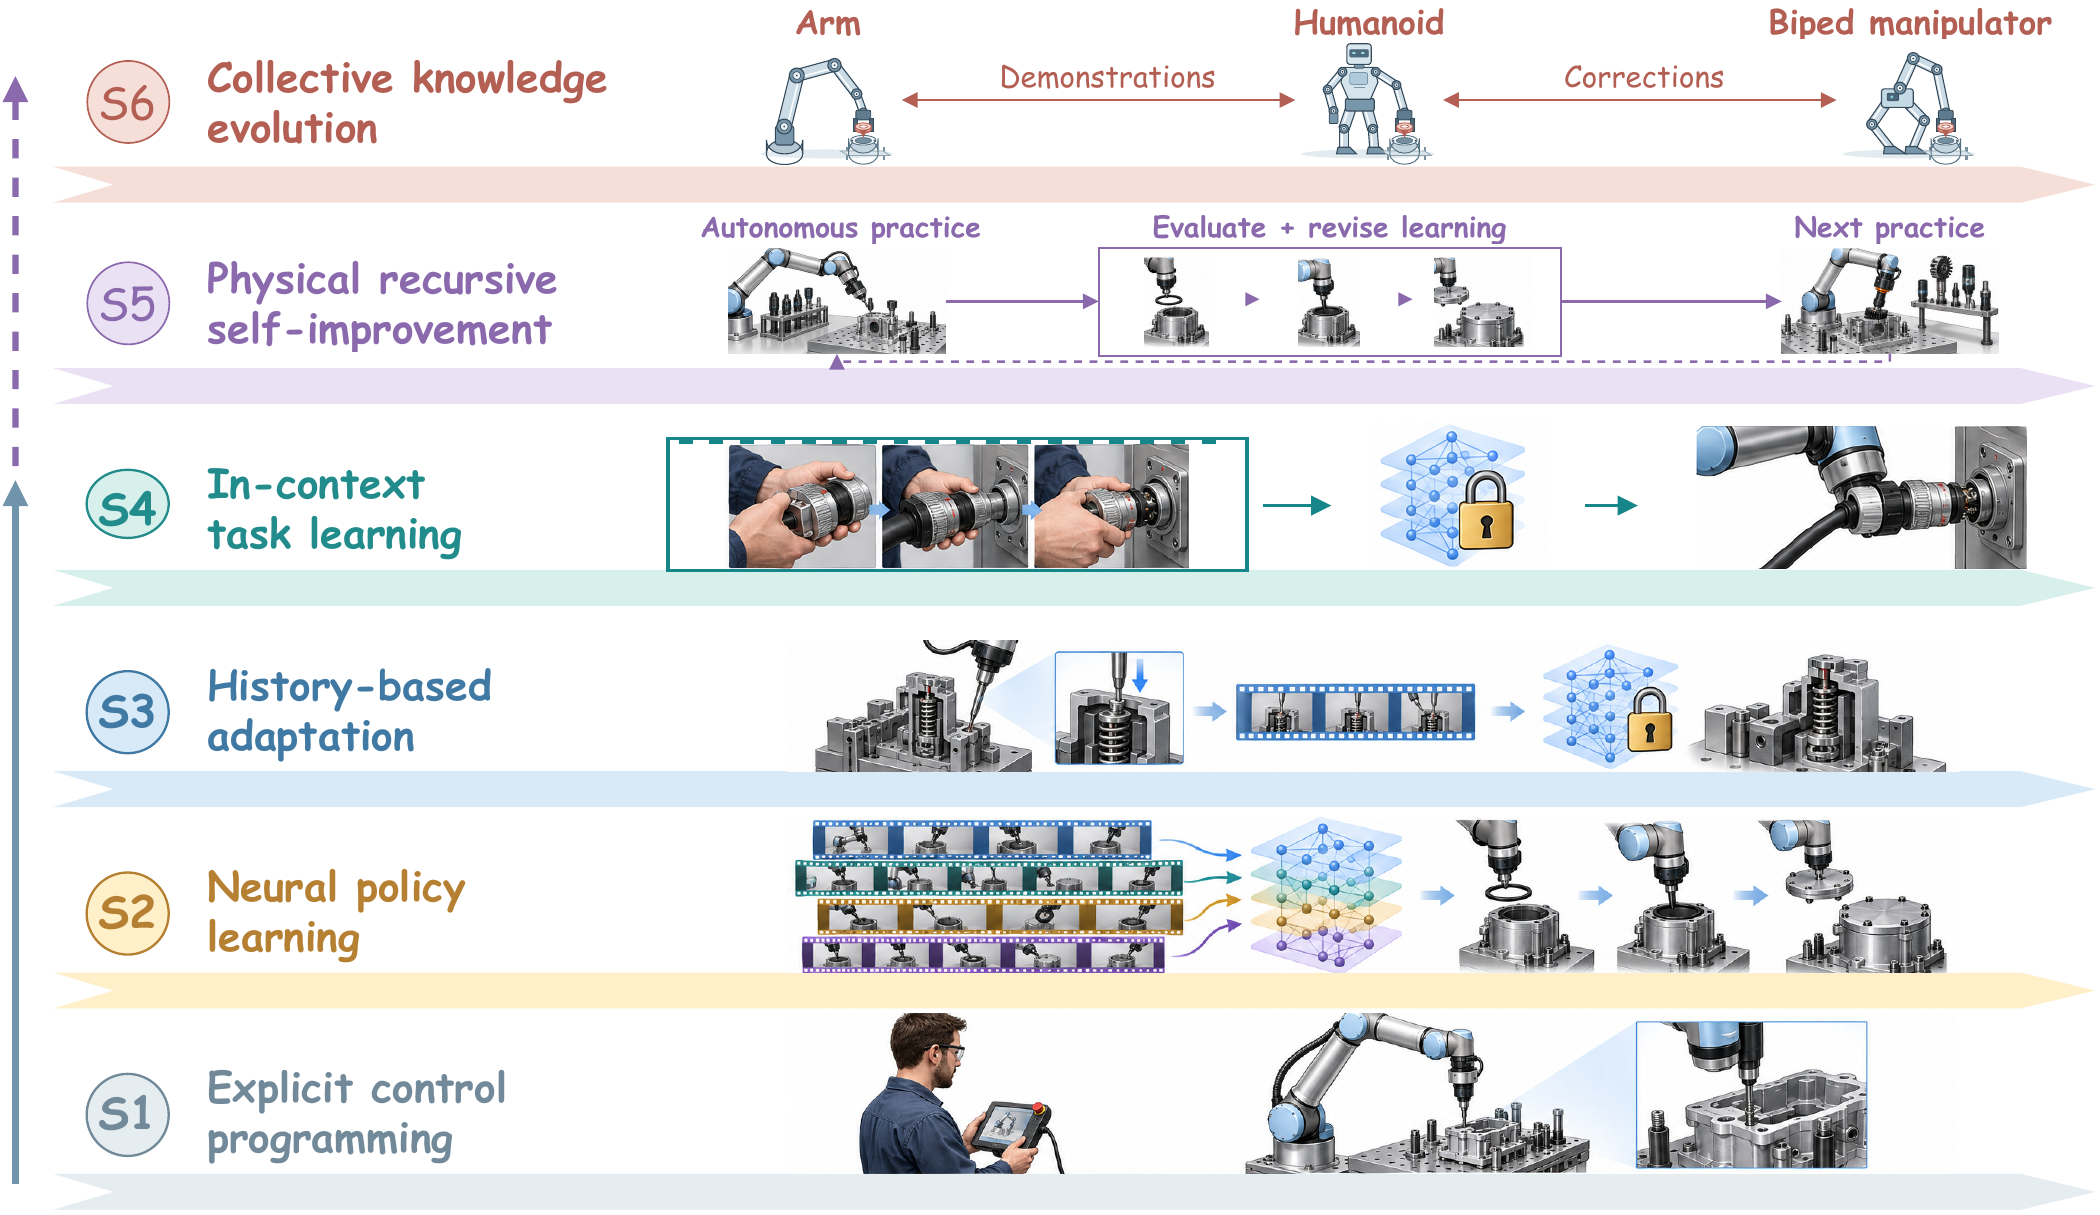
JethroJames/awesome-robots-icl

Python

Companion repository for “In-Context Learning for Robots: Methods and Applications” — methods, datasets, and benchmarks organized by taxonomy and release date.

Companion repository for “In-Context Learning for Robots: Methods and Applications” — methods, datasets, and benchmarks organized by taxonomy and release date.

awesome-listembodied-aiimitation-learningin-context-learningrobot-learningroboticsvision-language-actionworld-modelsrobotvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#202026-10-08★ 79 +1新项目68

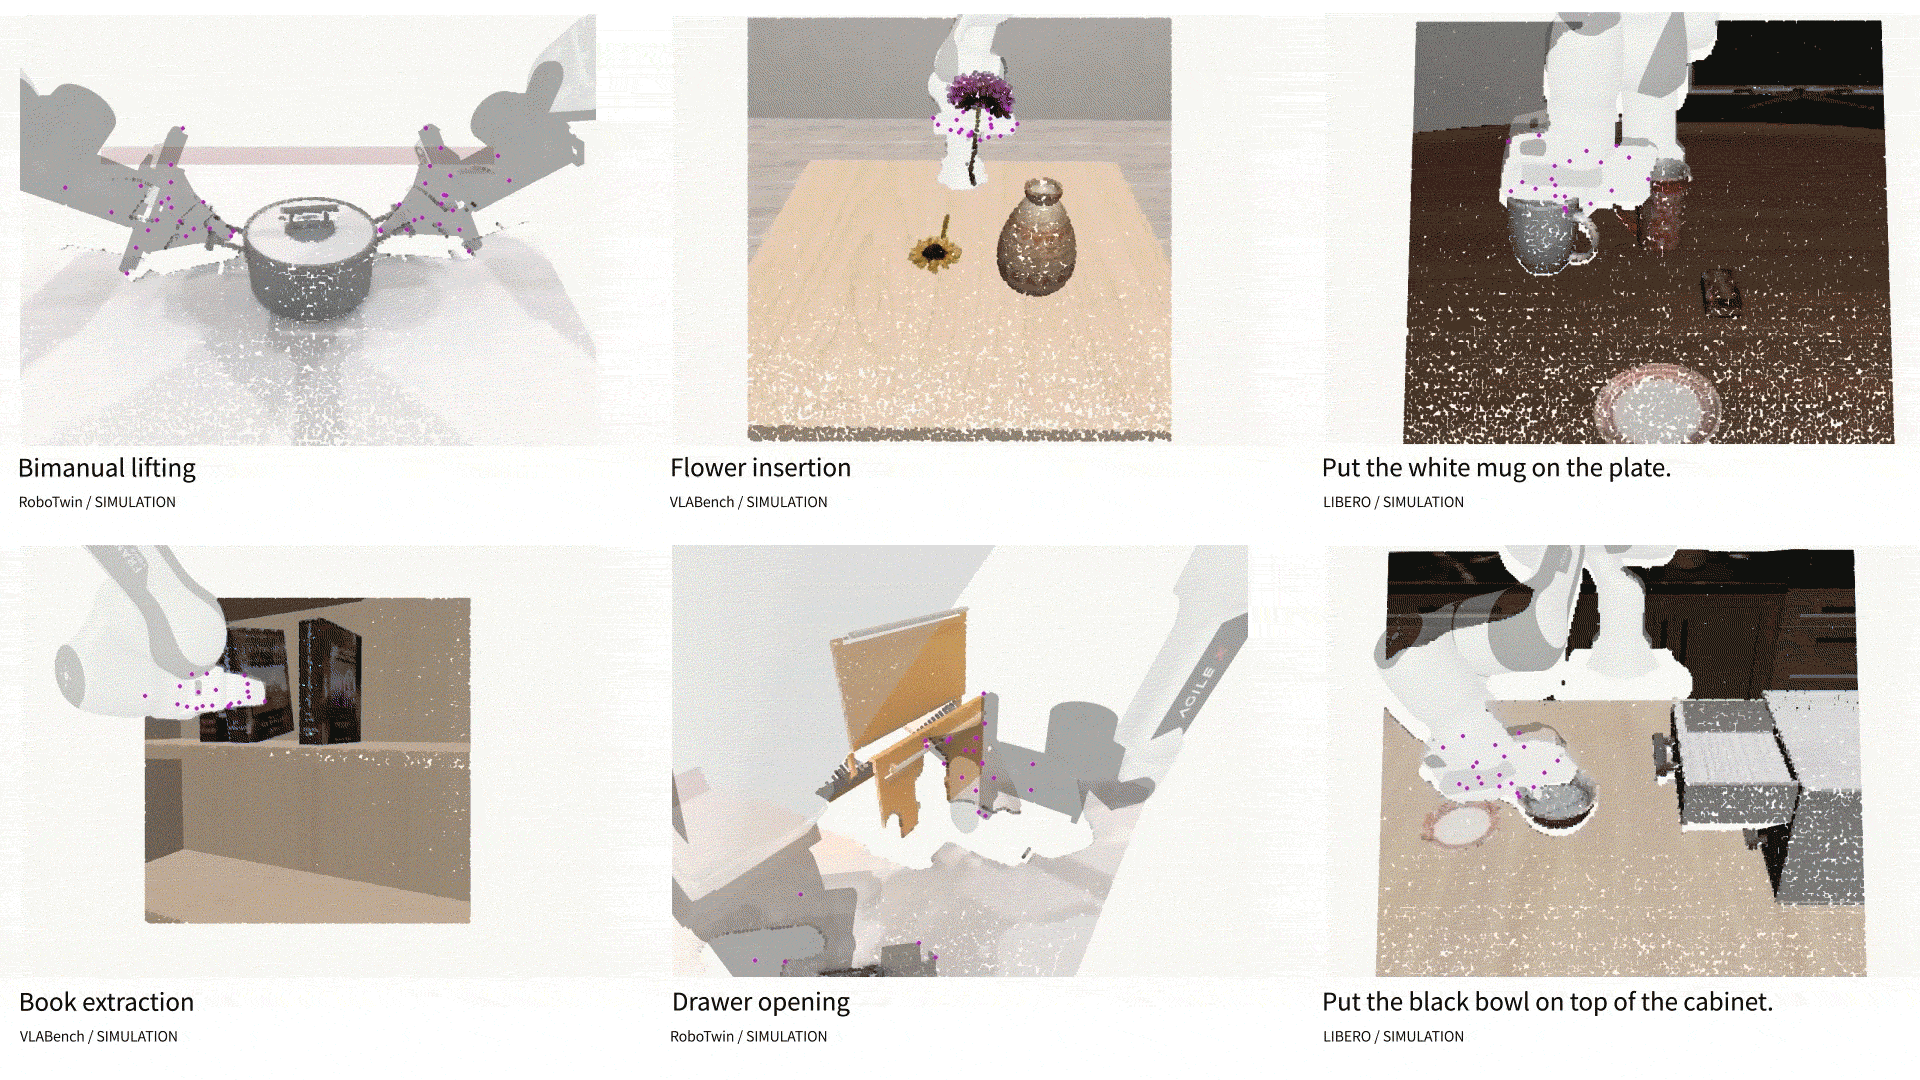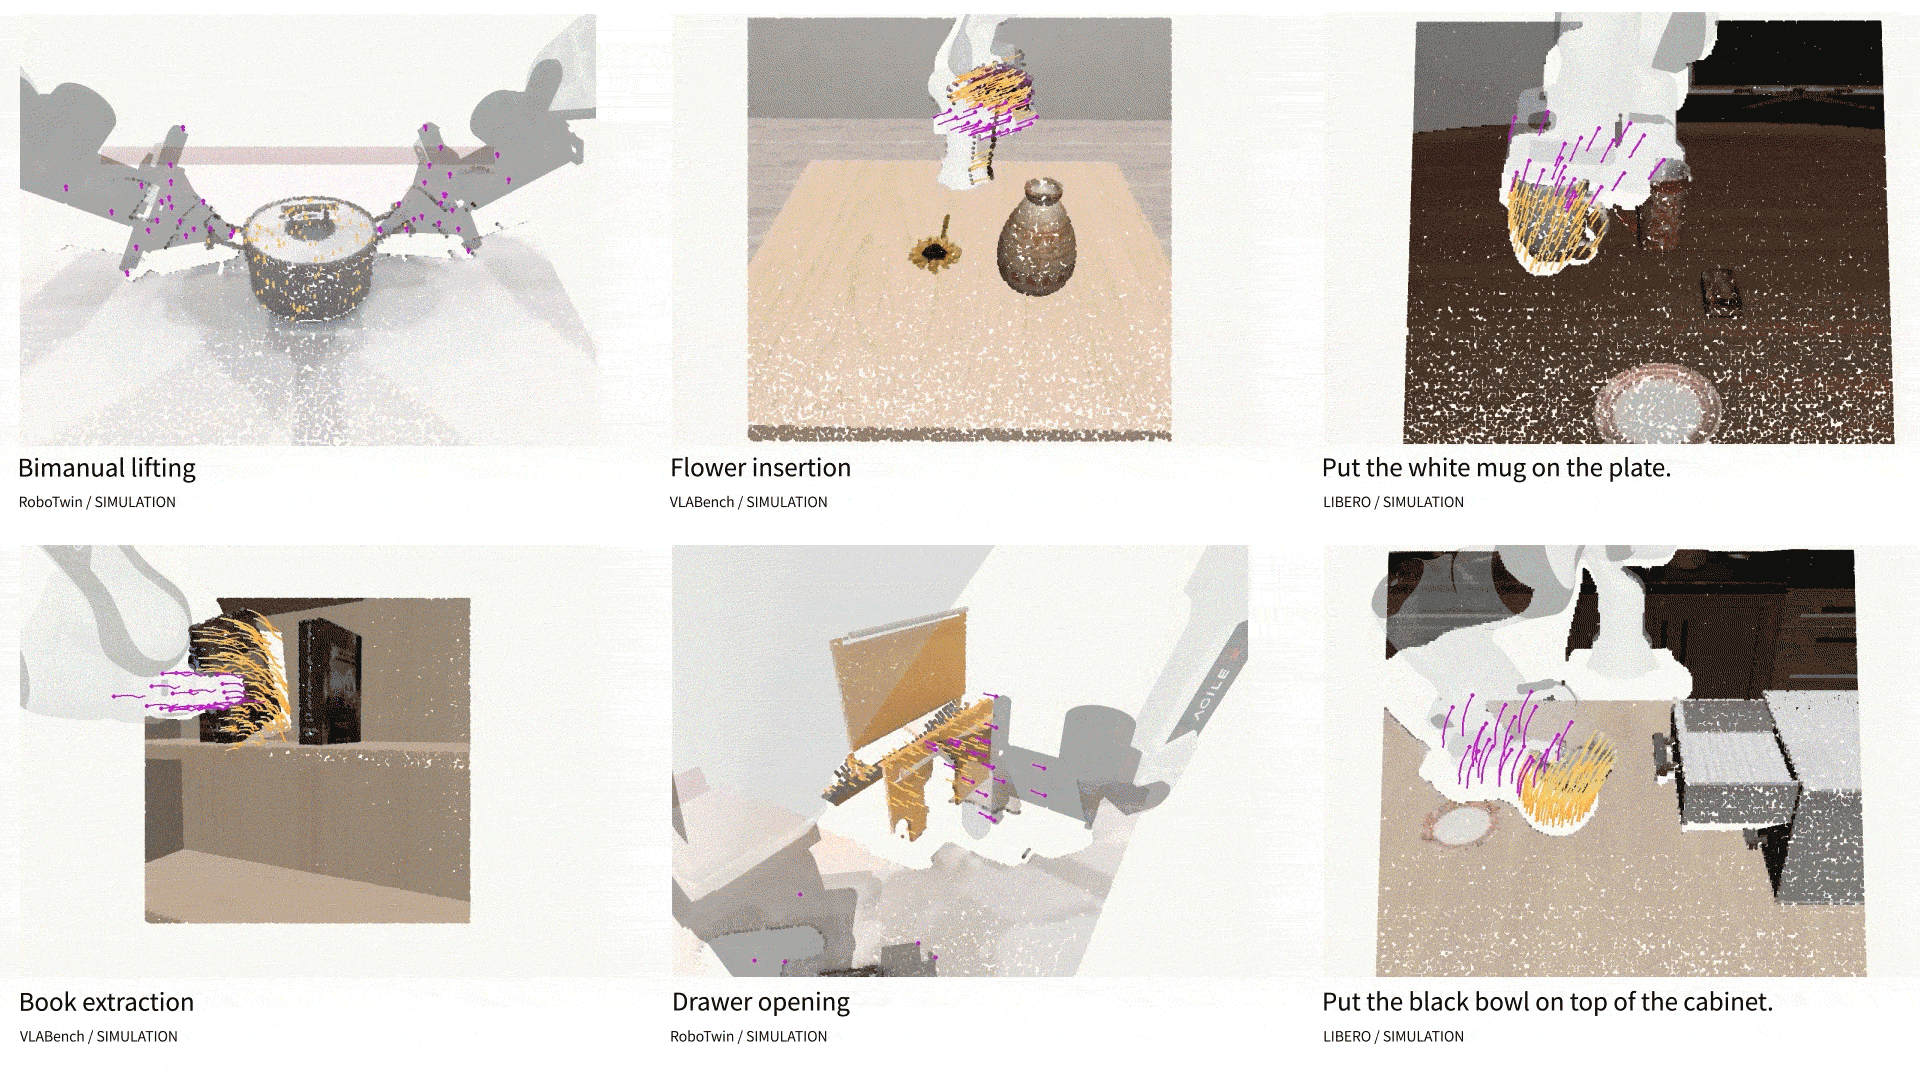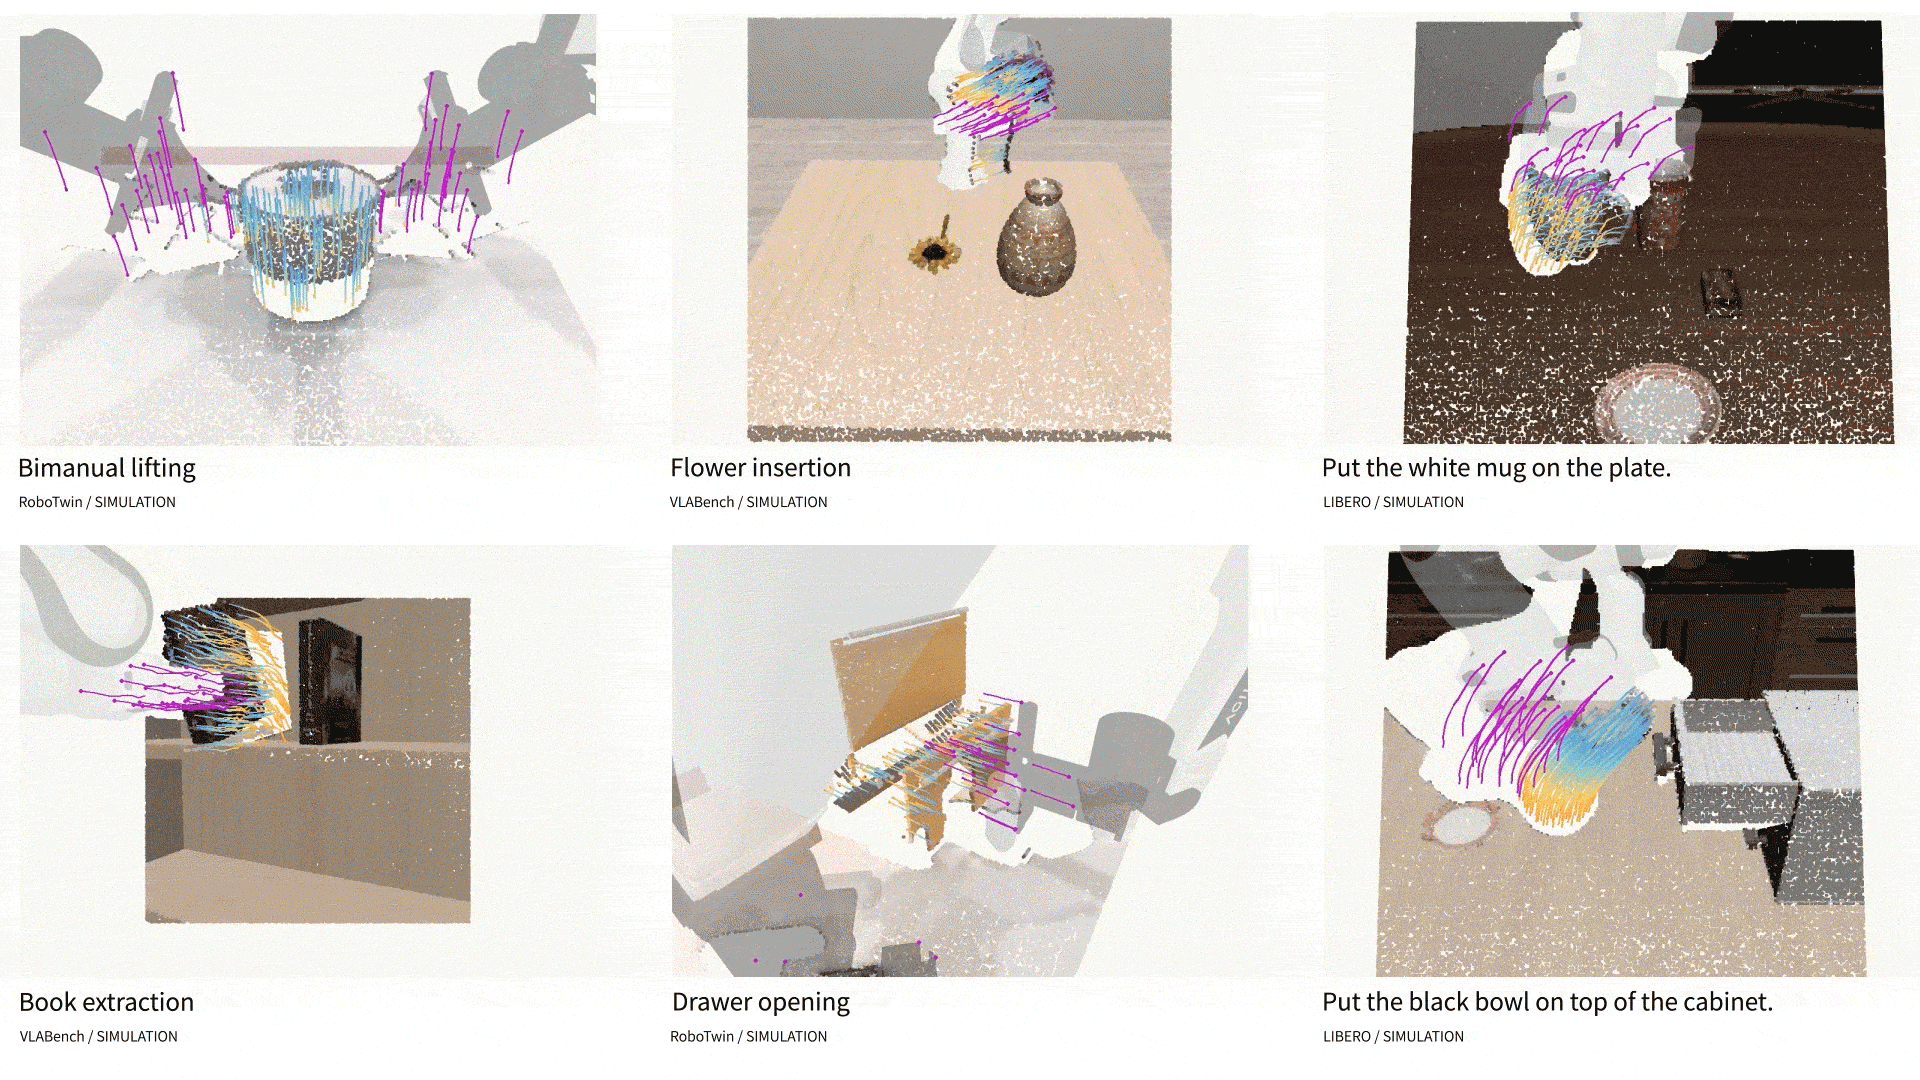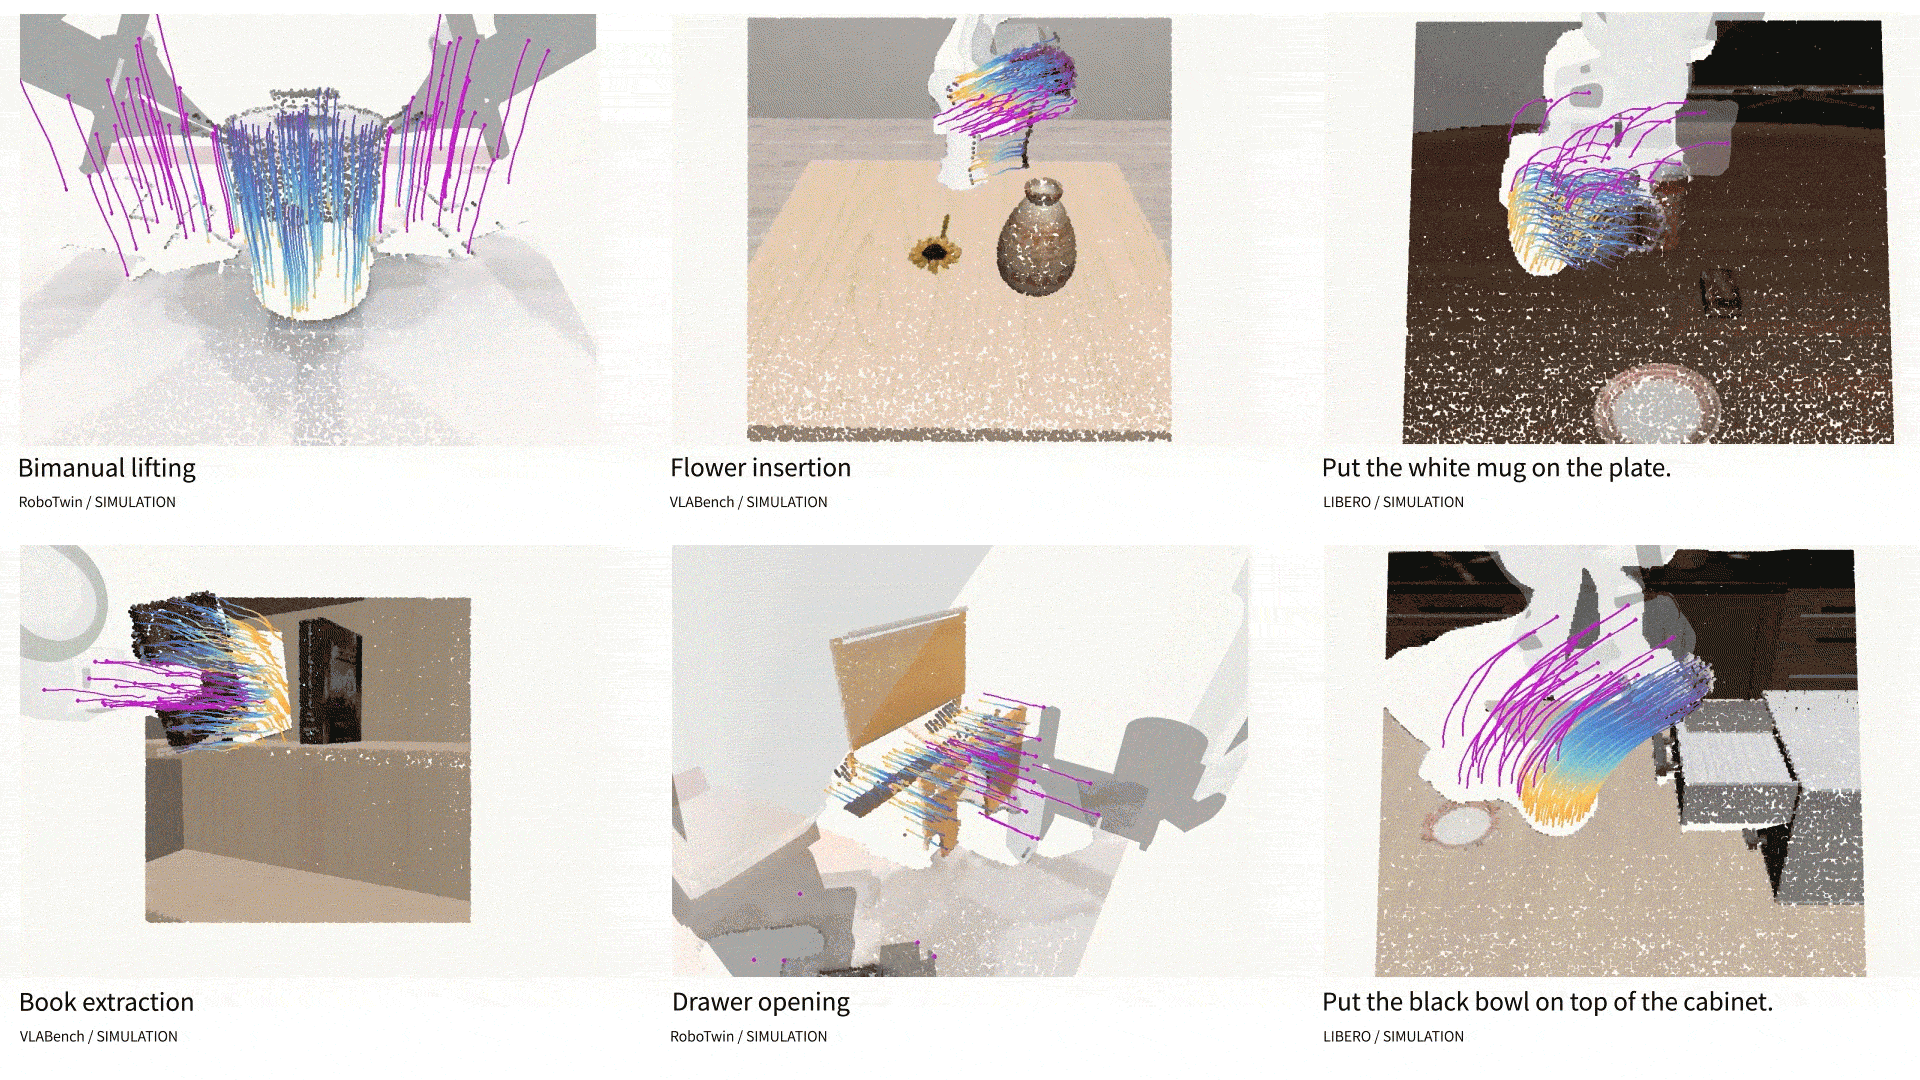
DexForce/UNITAS

Python

Official codebase for Unitas: A 3D-Native World Action Model for Embodied Manipulation

Official codebase for Unitas: A 3D-Native World Action Model for Embodied Manipulation

robot-learningrobot-manipulationroboticsvision-language-action-modelworld-action-modelsworld-modelsrobotmanipulationvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#212026-08-29★ 147 +268

nssmd/RoboRSI

Python

Robot-agent harness with a CLI and local Web console for LIBERO short evaluation

Robot-agent harness with a CLI and local Web console for LIBERO short evaluation

agentsembodied-aievaluationliberorobot-learningroboticsself-evolutionrobotembodied

兴趣:multi-agent systems and LLM agents

#222025-08-14★ 5.4k +568

RLinf/RLinf

Python

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

agentic-aiembodied-aireinforcement-learningrl-infrarlinfvla-rlVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#232026-03-18★ 70.8k +35668

rohitg00/ai-engineering-from-scratch

Python

Learn AI Engineering! Learn it. Build it. Ship it for others.

Learn AI Engineering! Learn it. Build it. Ship it for others.

agentsaiai-agentsai-engineeringcomputer-visioncoursedeep-learningdsh

兴趣:multi-agent systems and LLM agents

#242024-05-11★ 1.8k +267

robocasa/robocasa

Python

RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots

RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots

humanoid-robotphysics-simulationrobot-learningroboticsrobothumanoid

兴趣:humanoid robots and whole-body control

#252026-06-24★ 267 +667

MinghaoFu/lewam

Python

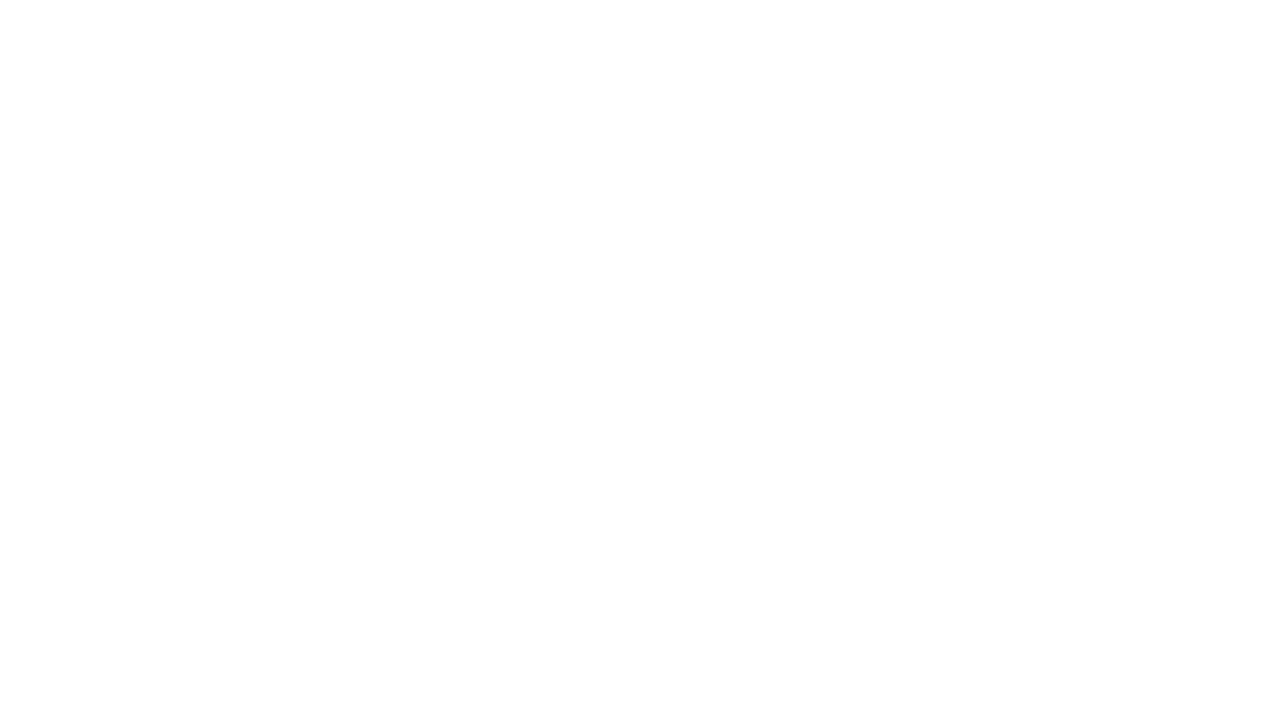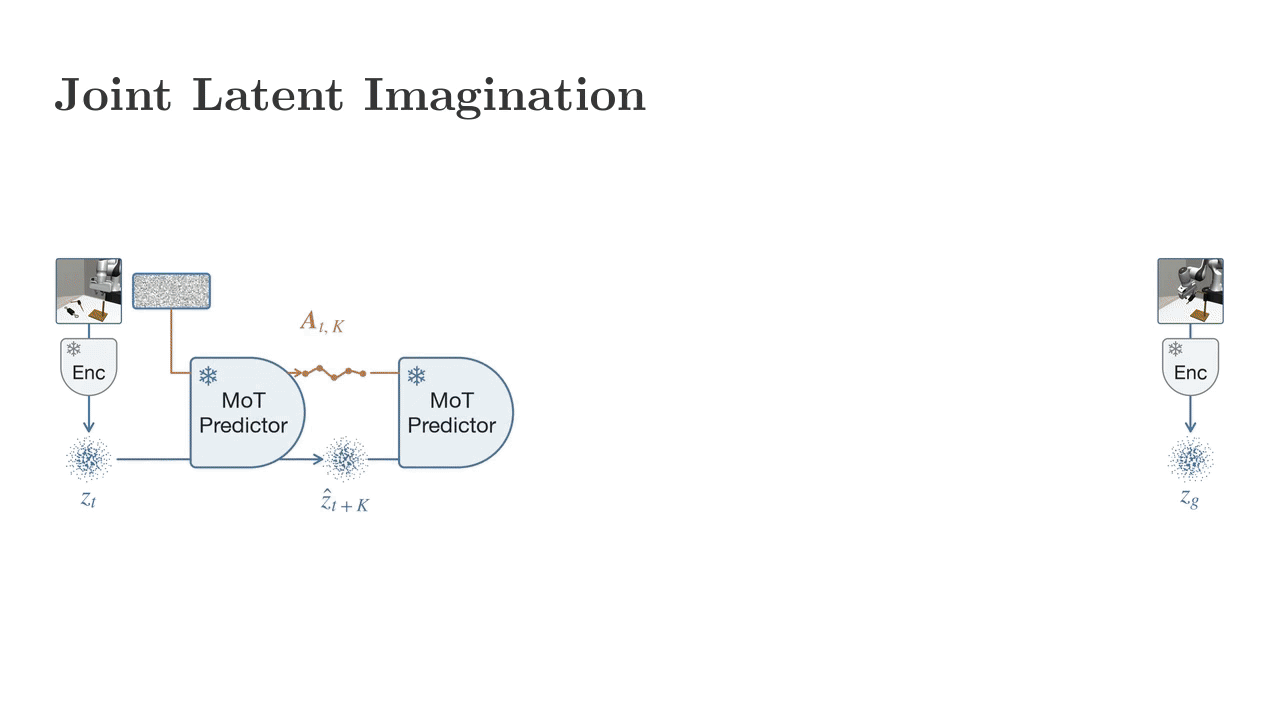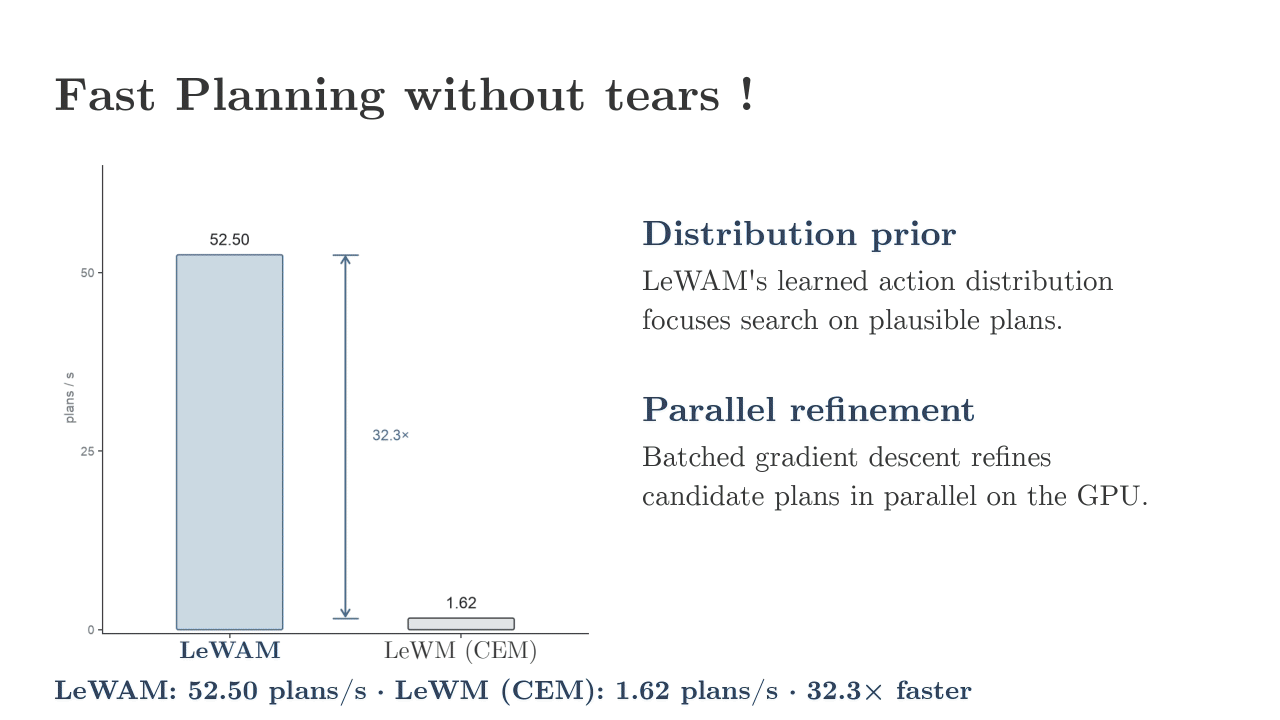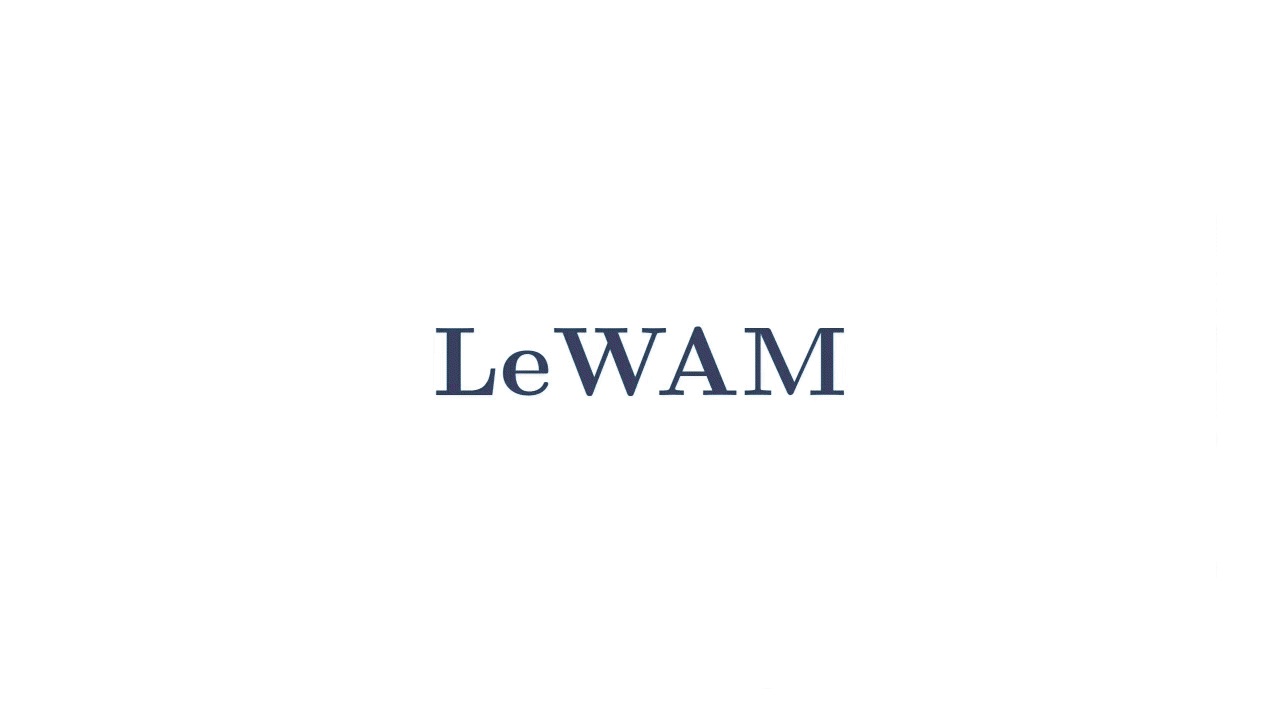
LeWAM: End-to-End World and Action Modeling with JEPAs

LeWAM: End-to-End World and Action Modeling with JEPAs

jeparobot-learningworld-modelsrobot

兴趣:vision-language-action (VLA) models and foundation models for robots
#262026-07-25★ 204 +167

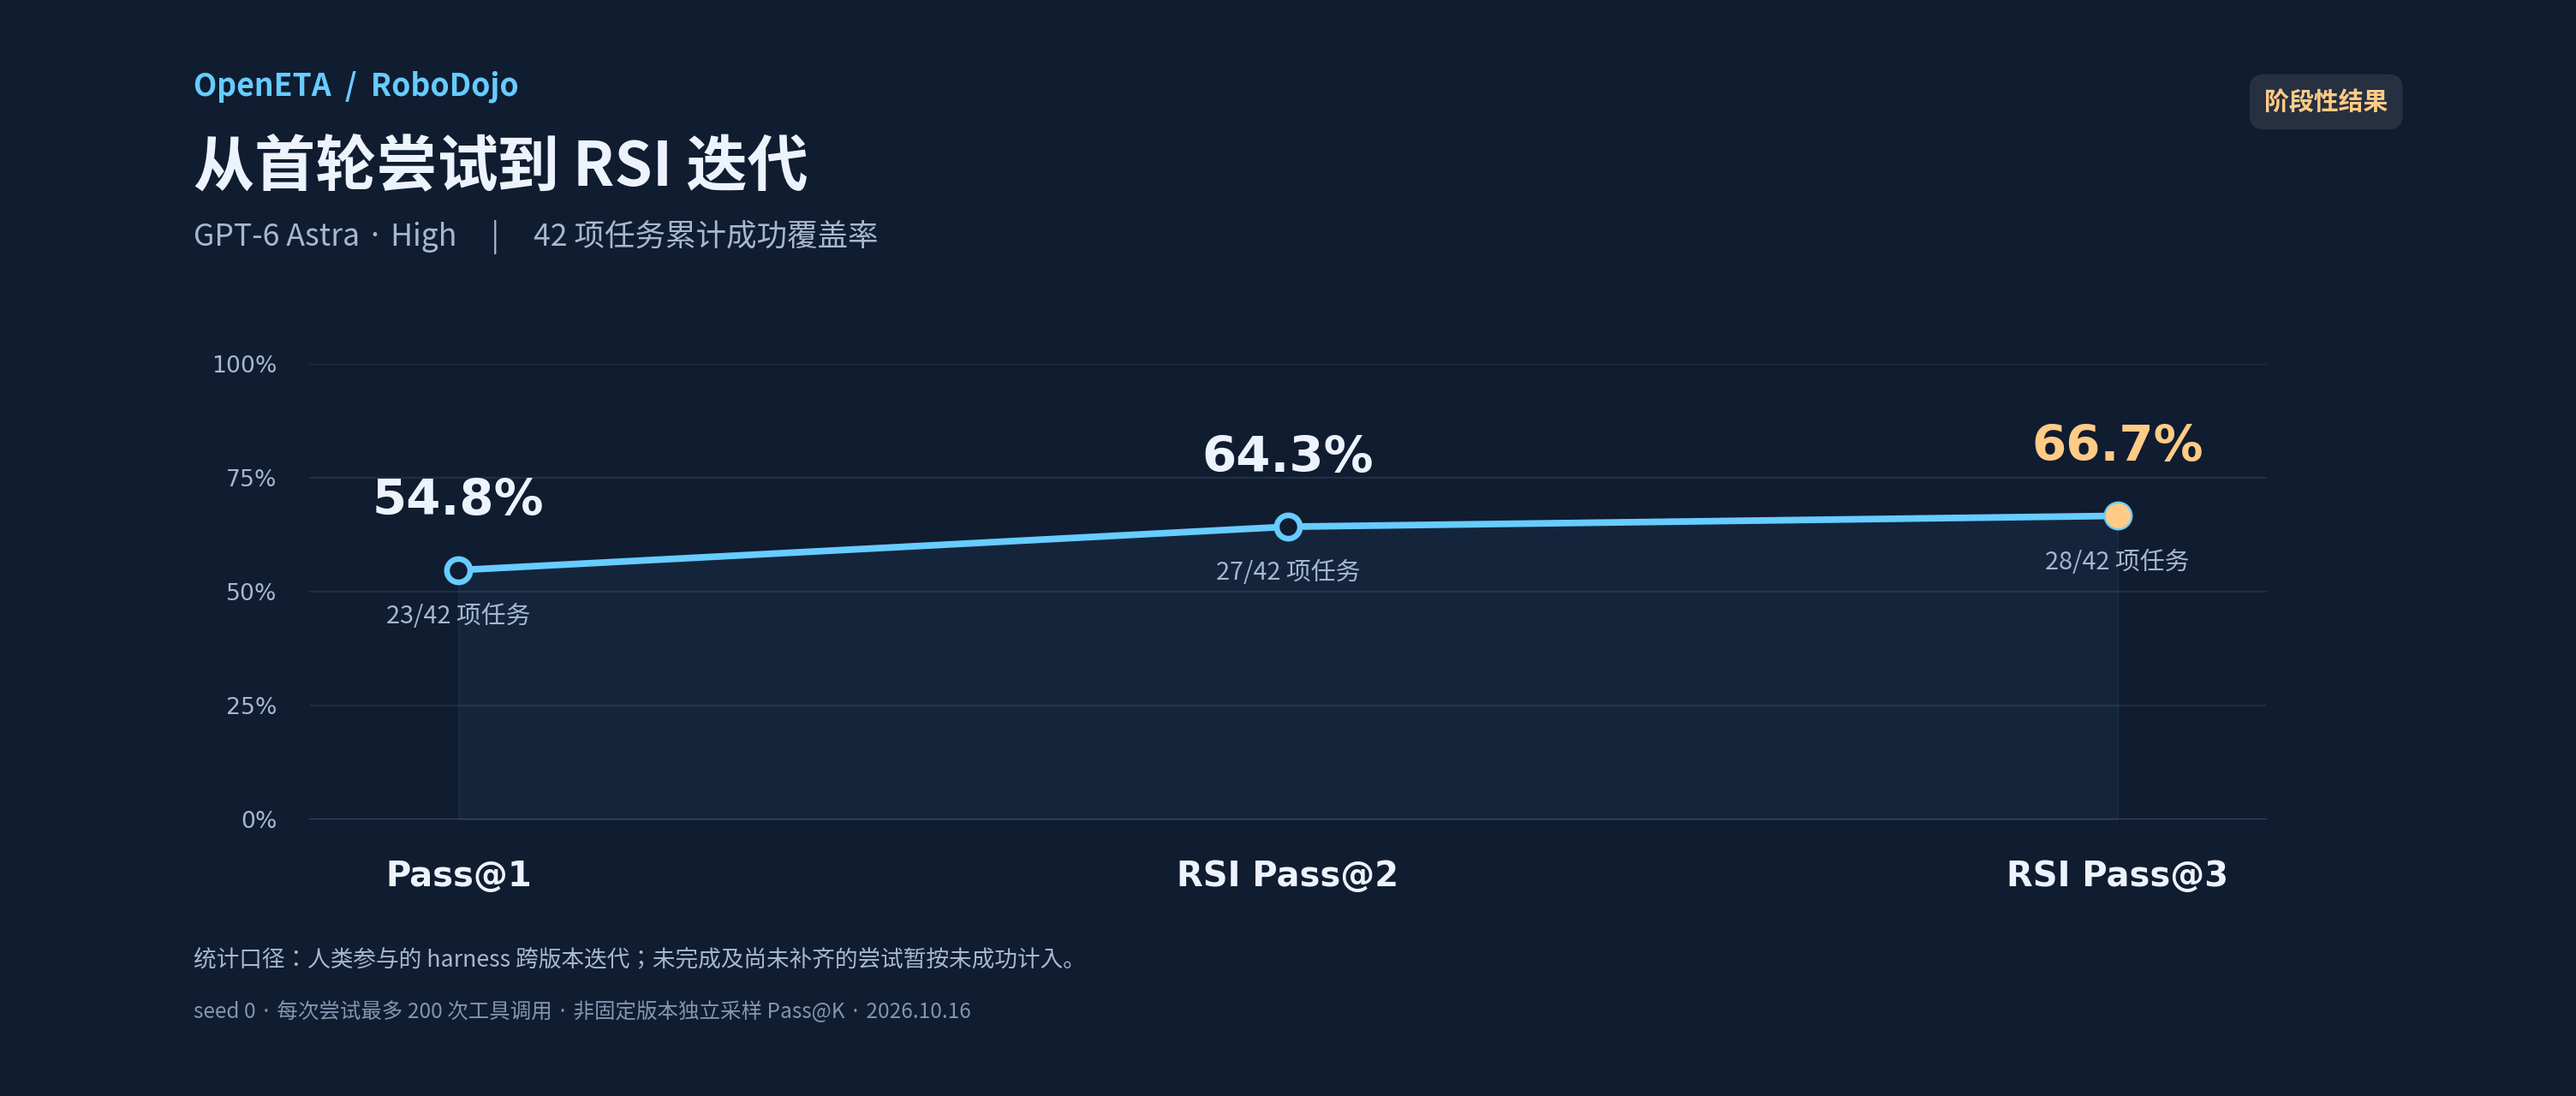
OpenMOSS/OpenETA

Python

An embodied task agent that connects perception, action, verification, and learning in a continuous physical-world loop

An embodied task agent that connects perception, action, verification, and learning in a continuous physical-world loop

agentembodied-agentembodied-agentsembodied-aiembodied-artificial-intelligenceembodied-intelligencephysical-airoboticsVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#272026-10-04★ 60 +1新项目67

Holiday-Robot/FlashDexRetarget

Python

FlashDexRetarget: Accelerating Dexterous Manipulation Data Generation through Multi-Motion Retargeting

FlashDexRetarget: Accelerating Dexterous Manipulation Data Generation through Multi-Motion Retargeting

dexterous-manipulationreinforcement-learningroboticsrobotmanipulationdexterous

兴趣:robot manipulation and grasping with learned policies

#282026-06-26★ 685 +367

robocurve/inspect-robots

Python

Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.

Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.

benchmarkembodied-aievaluationphysical-airerunroboticsvision-language-actionvlaVLAvision-language-actionhumanoidembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#292025-04-04★ 1.9k +-167

RoboVerseOrg/RoboVerse

Python

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

imitation-learningreinforcement-learningroboticssimulationrobot

兴趣:imitation learning and diffusion policies for robot control

#302025-09-11★ 7.2k +1467

vllm-project/vllm-omni

Python

A framework for efficient model inference with omni-modality models

A framework for efficient model inference with omni-modality models

audio-generationdiffusionimage-generationinferencemodel-servingmultimodalpytorchtransformer

兴趣:vision-language-action (VLA) models and foundation models for robots