manumerous/wb_humanoid_mpc
C++
Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control
Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control
兴趣:humanoid robots and whole-body control
C++
Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control
兴趣:humanoid robots and whole-body control
Python
仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能
兴趣:world models and video prediction for embodied agents
Python
A Paper List for Humanoid Robot Learning.
兴趣:humanoid robots and whole-body control
Python
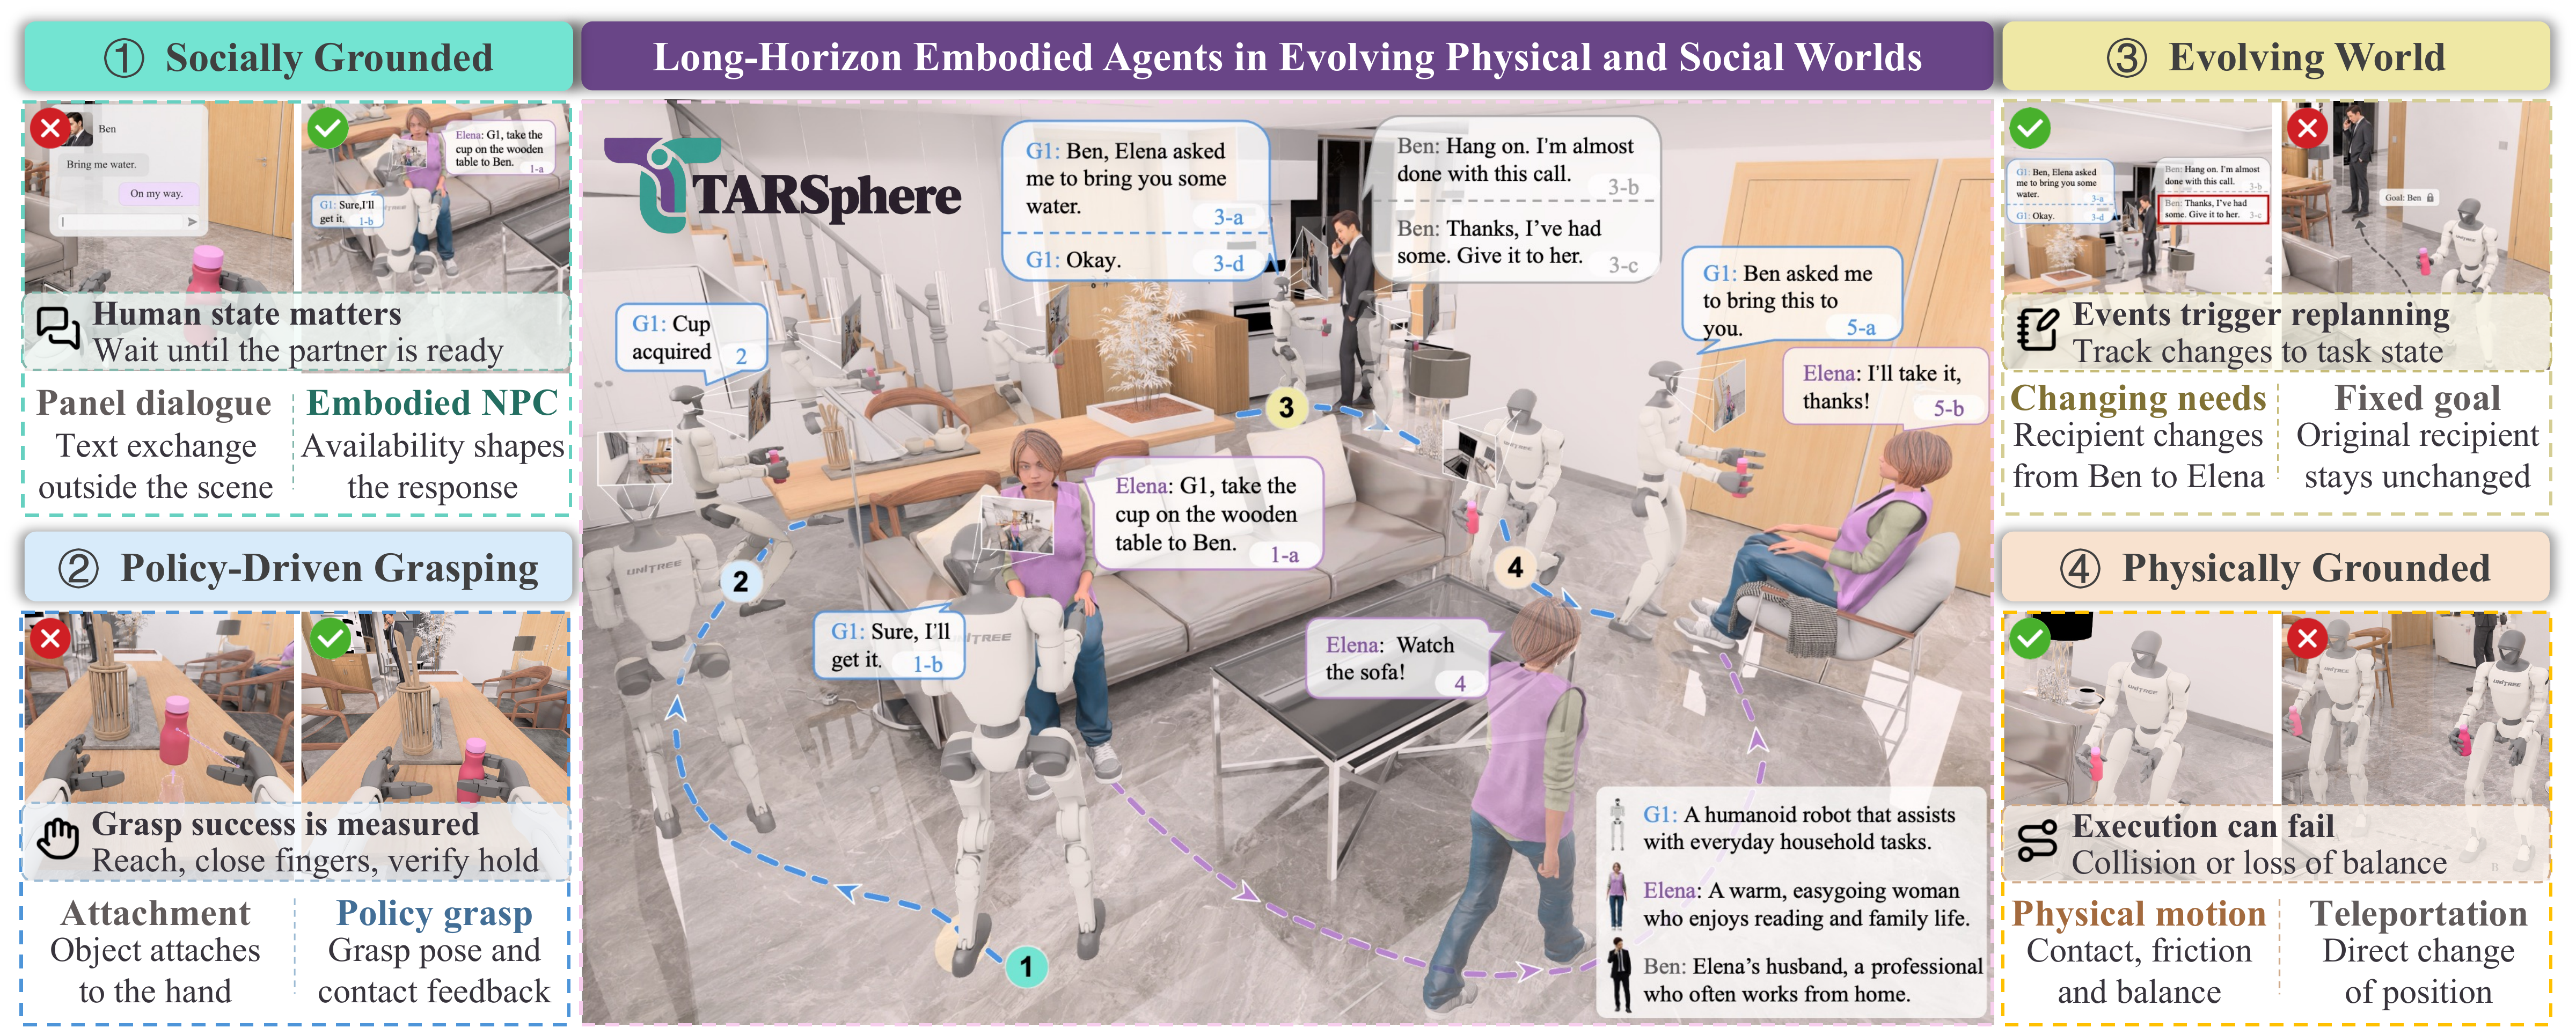
A robot-oriented full-stack framework for long-horizon embodied agents in evolving physical and social environments.
兴趣:world models and video prediction for embodied agents
Python
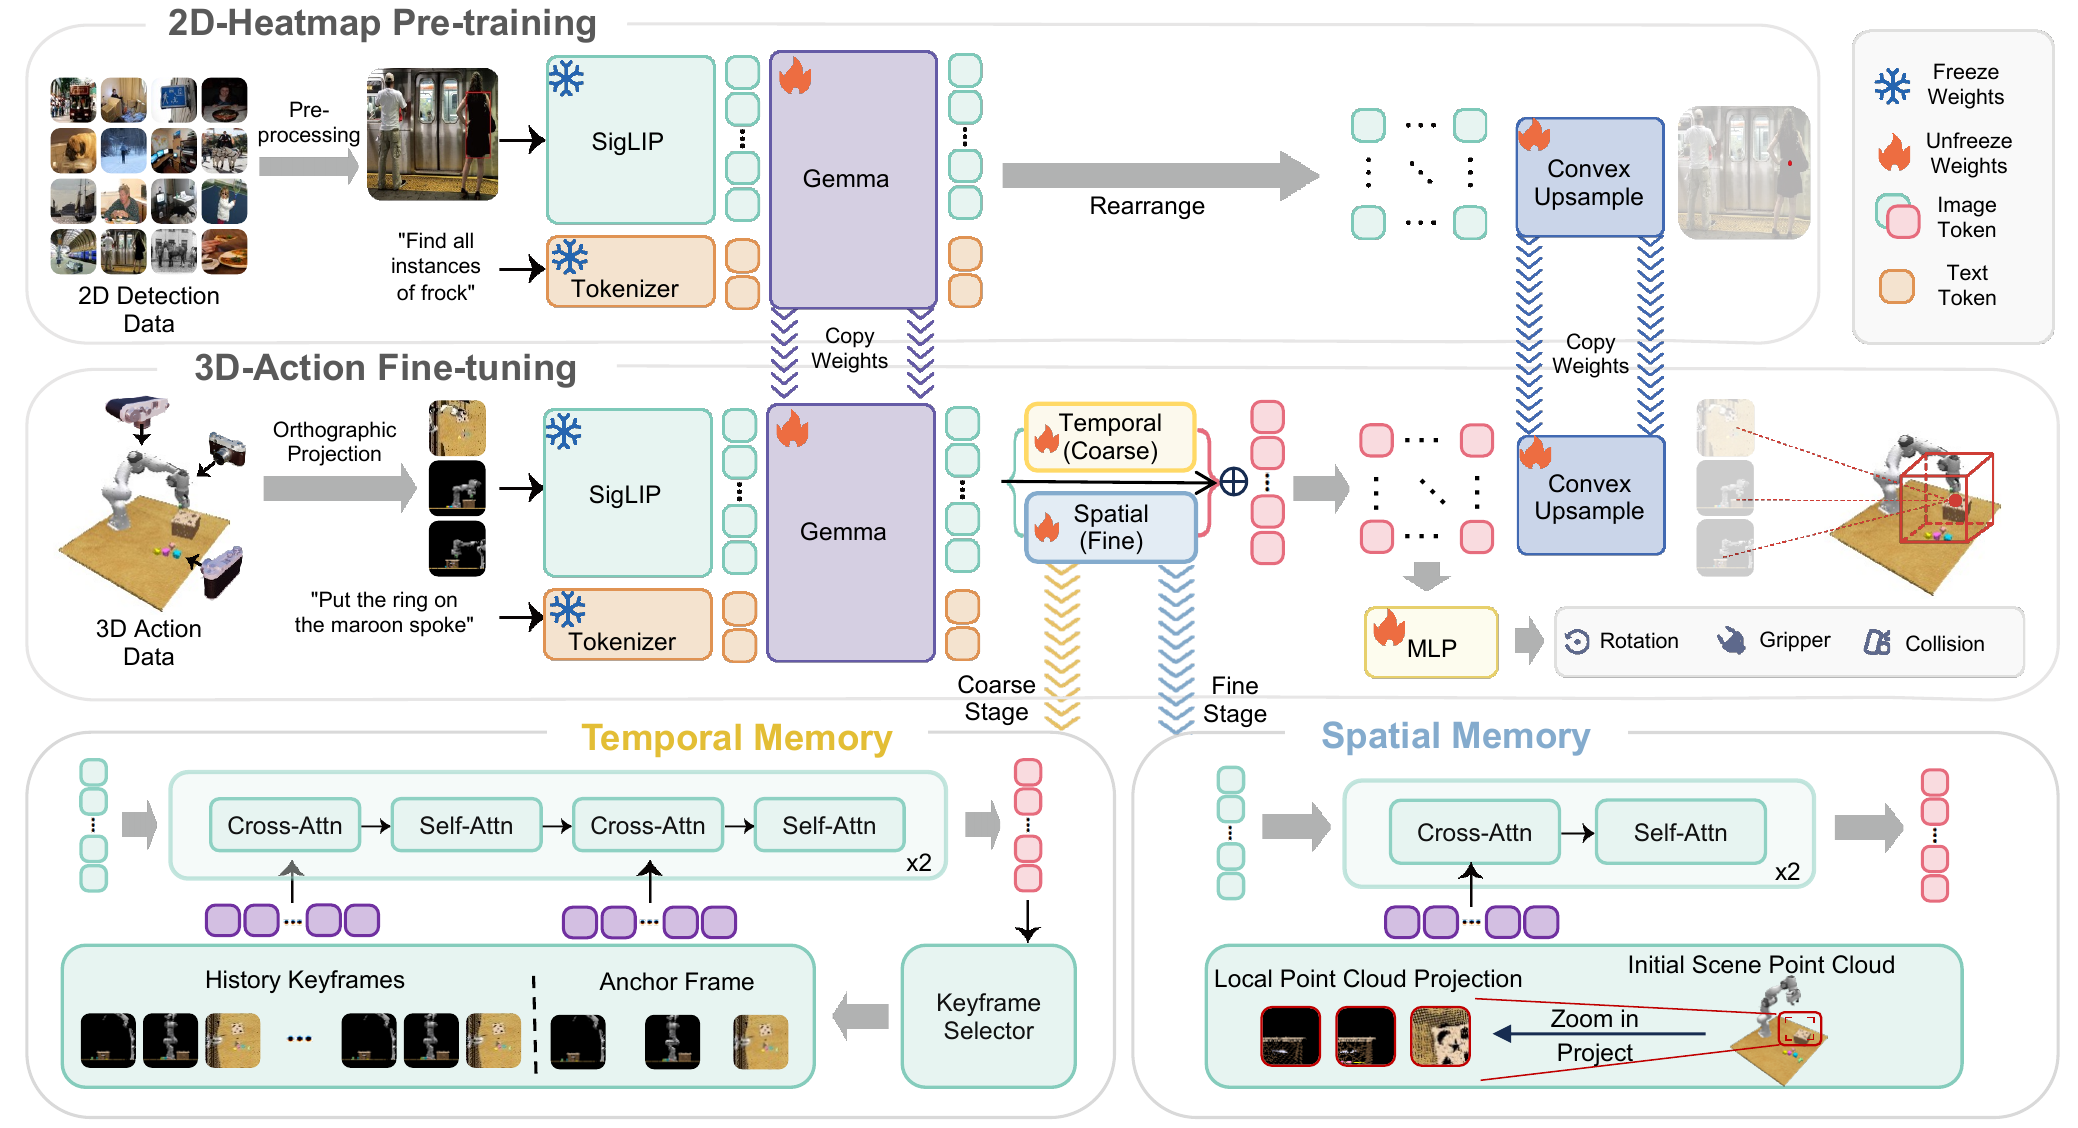
✨✨Official implementation of BridgeVLA and BridgeVLA++
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective
兴趣:world models and video prediction for embodied agents
Python
A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e, xArm, SO101 and YAM.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning
兴趣:imitation learning and diffusion policies for robot control
Python
A Foundation Model for Whole-Body Humanoid Control
兴趣:humanoid robots and whole-body control
Python
An Open-World Foundation Model for General-Purpose Embodied Intelligence.
兴趣:vision-language-action (VLA) models and foundation models for robots
HTML
本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
A unified framework for training, fine-tuning, and evaluating World Action Models
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
RoboCasa: Large-Scale Simulation of Everyday Tasks for Generalist Robots
兴趣:humanoid robots and whole-body control
Python
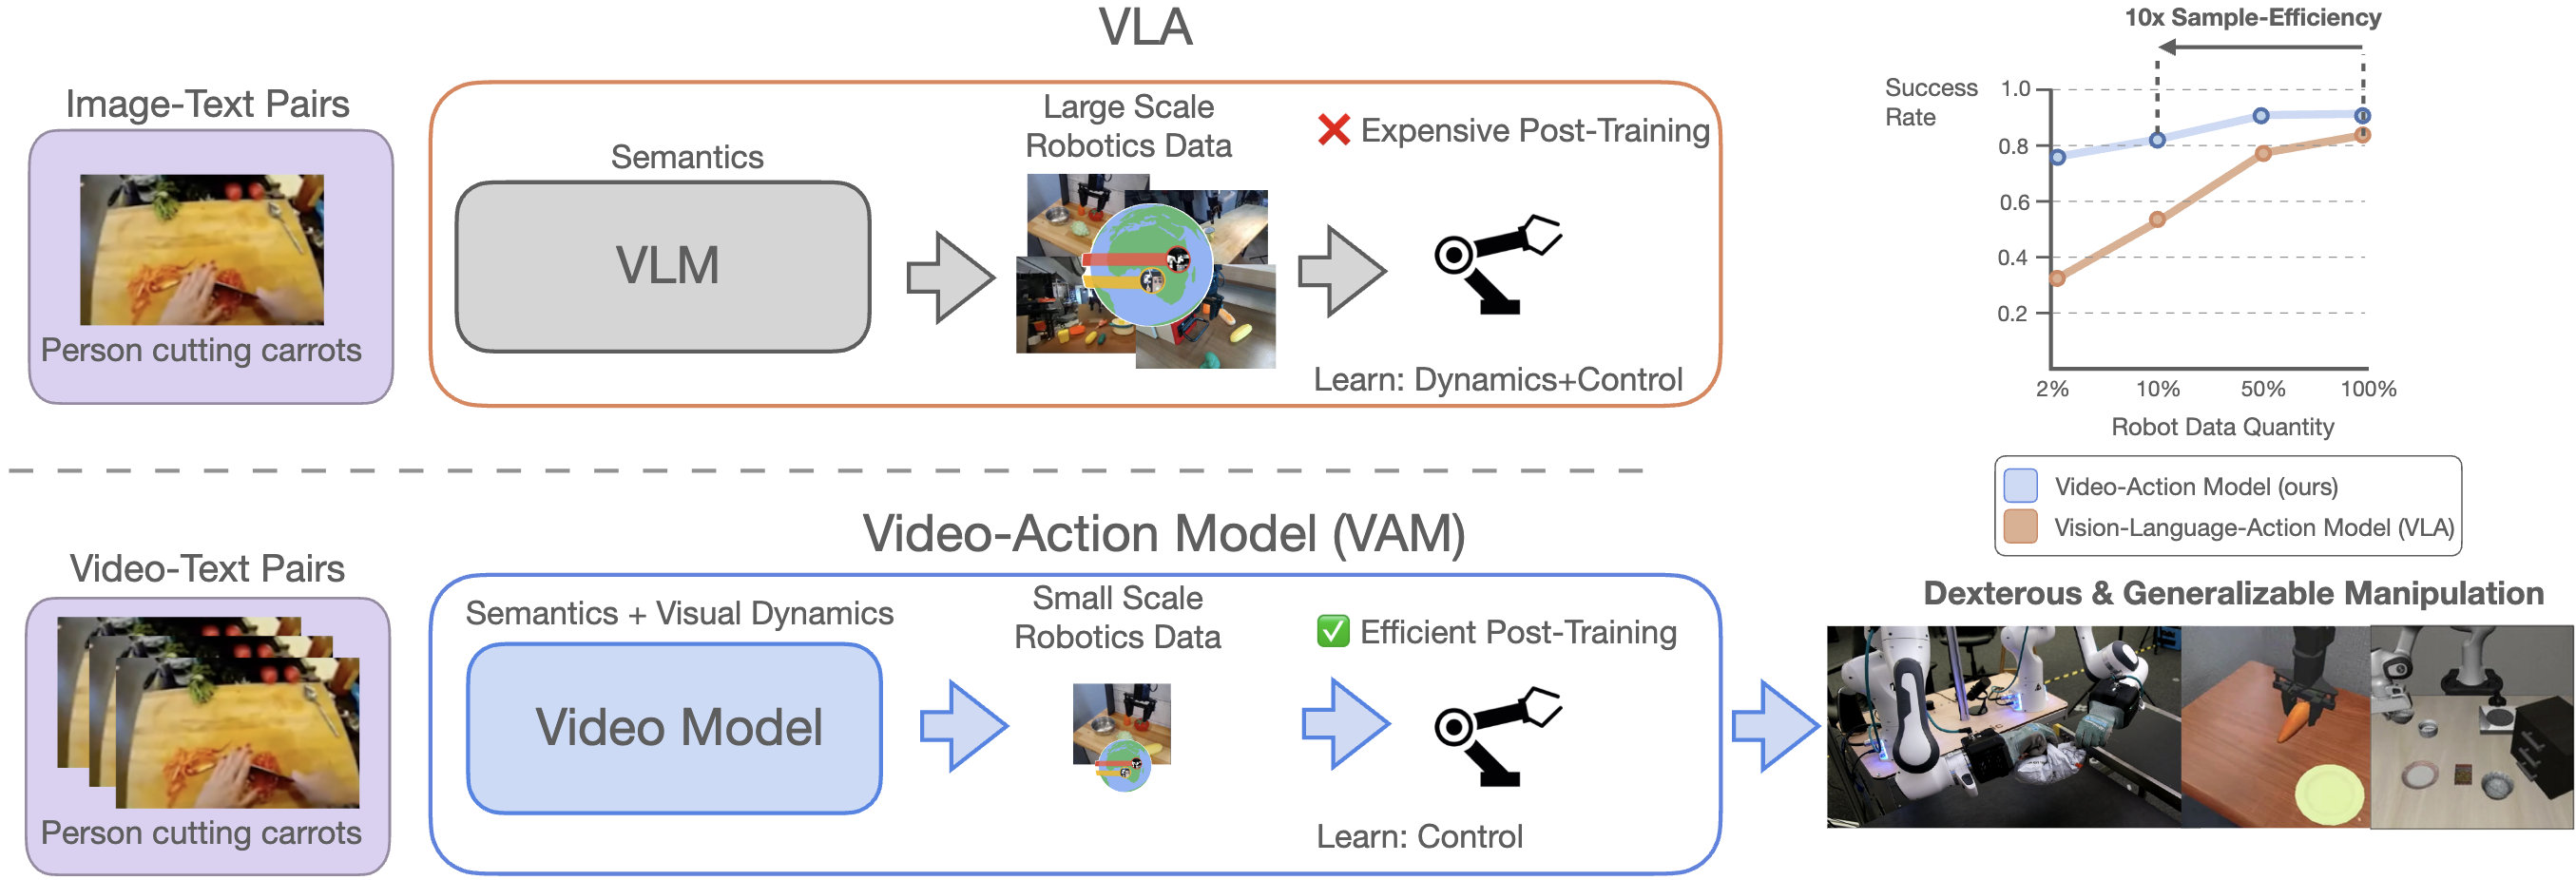
Video-Action Models for Generalizable Robot Control Beyond VLAs
兴趣:imitation learning and diffusion policies for robot control
An open-source, hand-worn variant of UMI for collecting bimanual manipulation data without a robot in the loop: modular for any parallel-jaw gripper.
兴趣:robot manipulation and grasping with learned policies
Python
Companion repository for “In-Context Learning for Robots: Methods and Applications” — methods, datasets, and benchmarks organized by taxonomy and release date.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning
兴趣:imitation learning and diffusion policies for robot control
Python
FlashDexRetarget: Accelerating Dexterous Manipulation Data Generation through Multi-Motion Retargeting
兴趣:robot manipulation and grasping with learned policies
Python
SGLang is a high-performance serving framework for large language models and multimodal models.
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
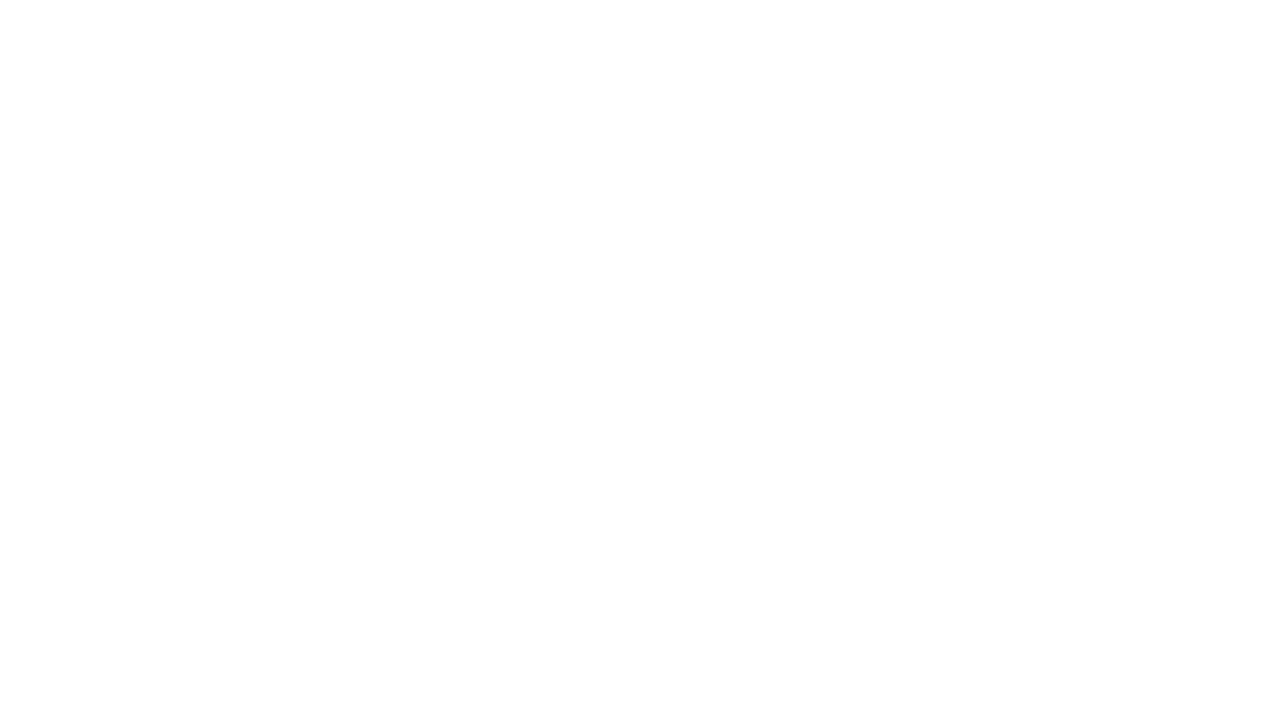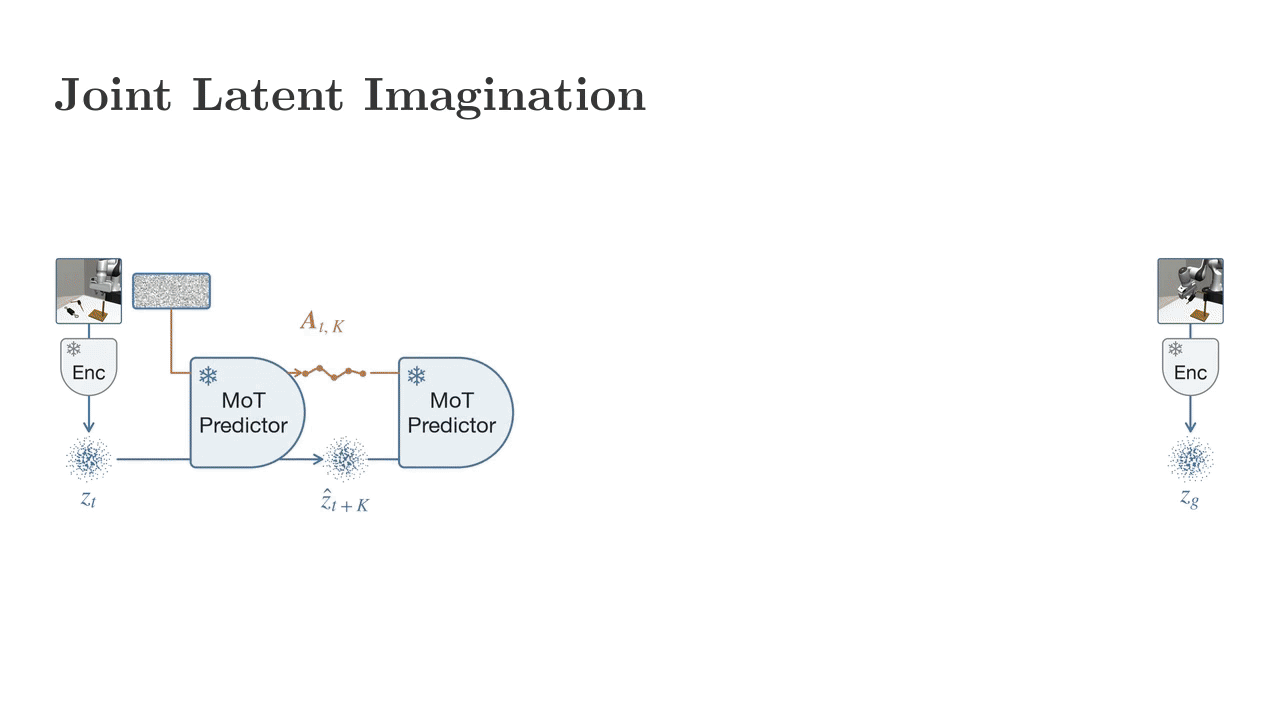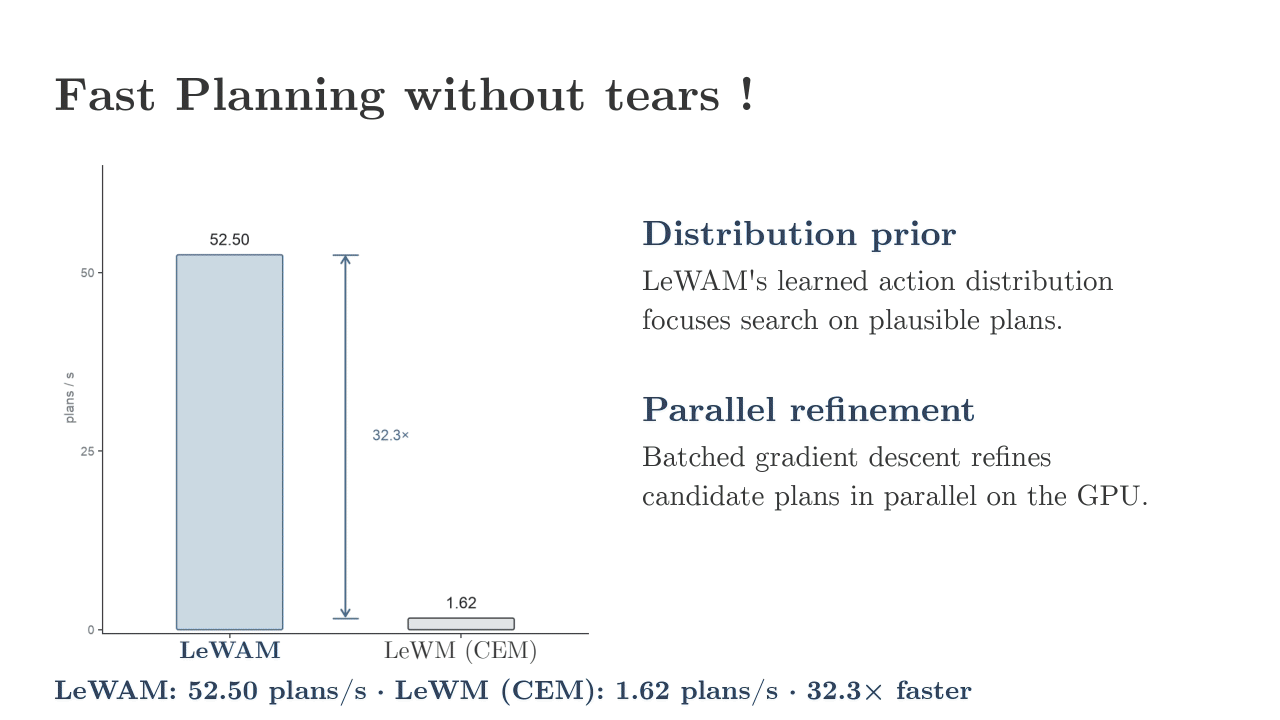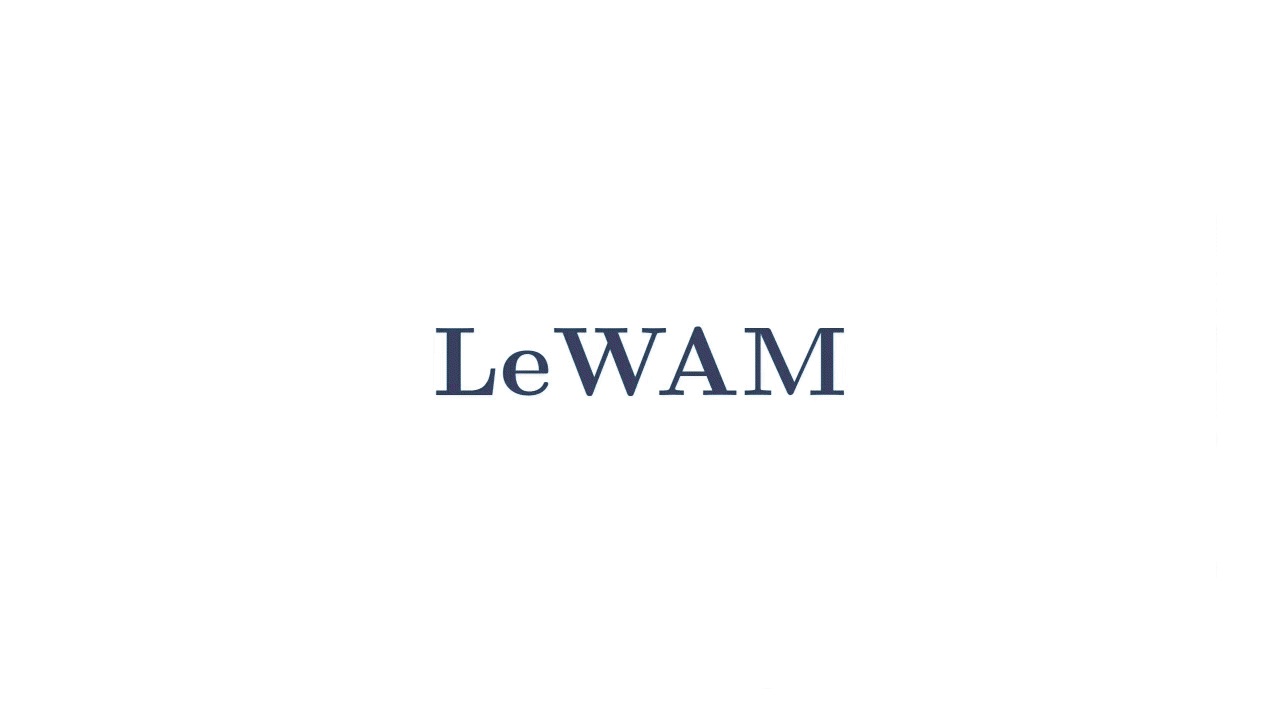
LeWAM: End-to-End World and Action Modeling with JEPAs
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
Unified framework for robot learning with multi-physics/renderer support
兴趣:3D perception, point clouds and scene understanding for robotics
Python
DONIC: Generalist Dexterous Bimanual Tracking Control from Human Demonstrations
兴趣:robot manipulation and grasping with learned policies
Python
A lightweight suite of motion imitation methods for training controllers.
兴趣:imitation learning and diffusion policies for robot control
JavaScript
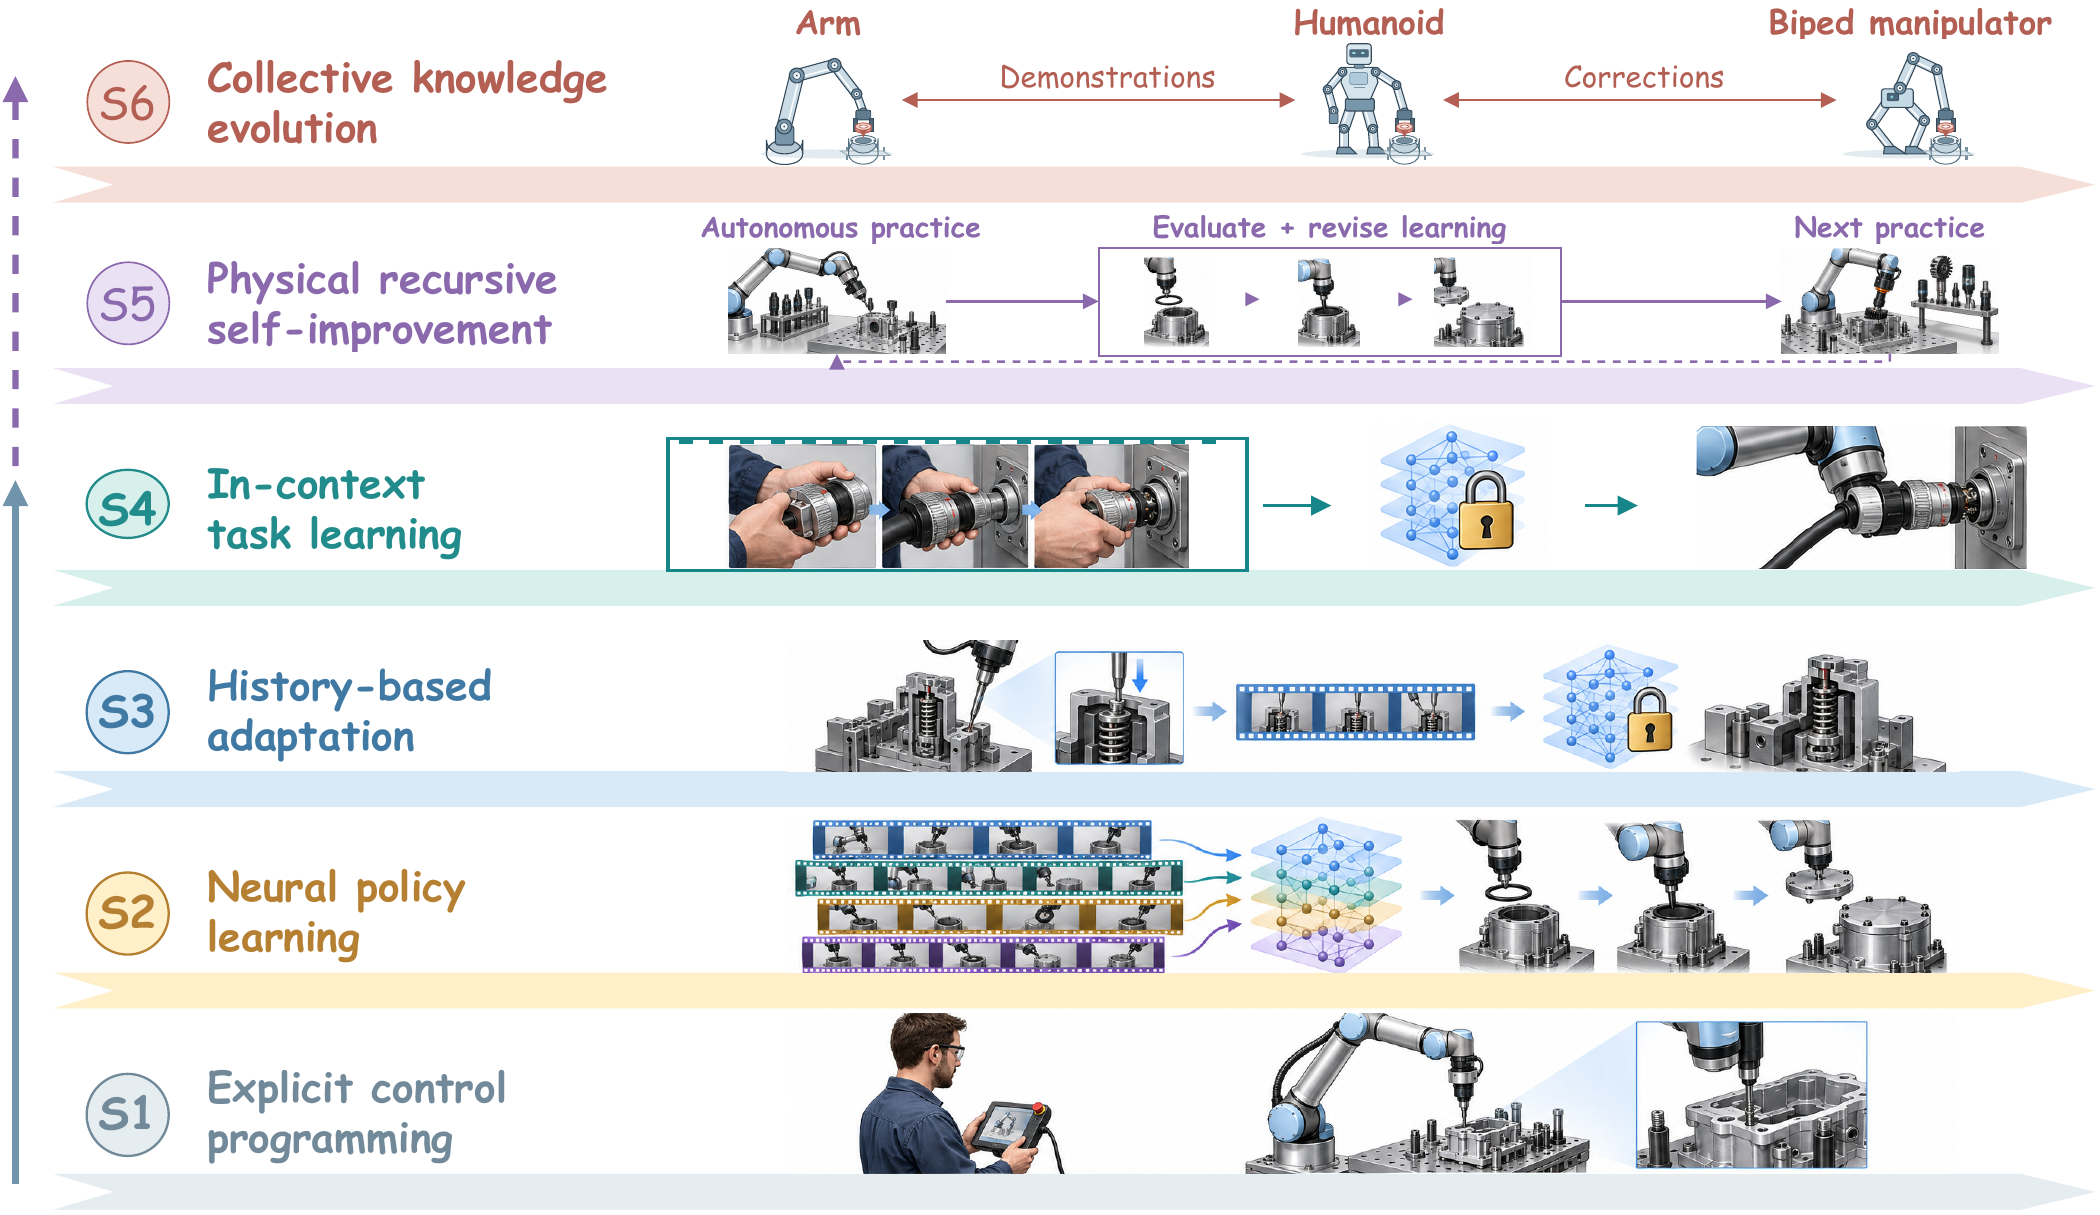
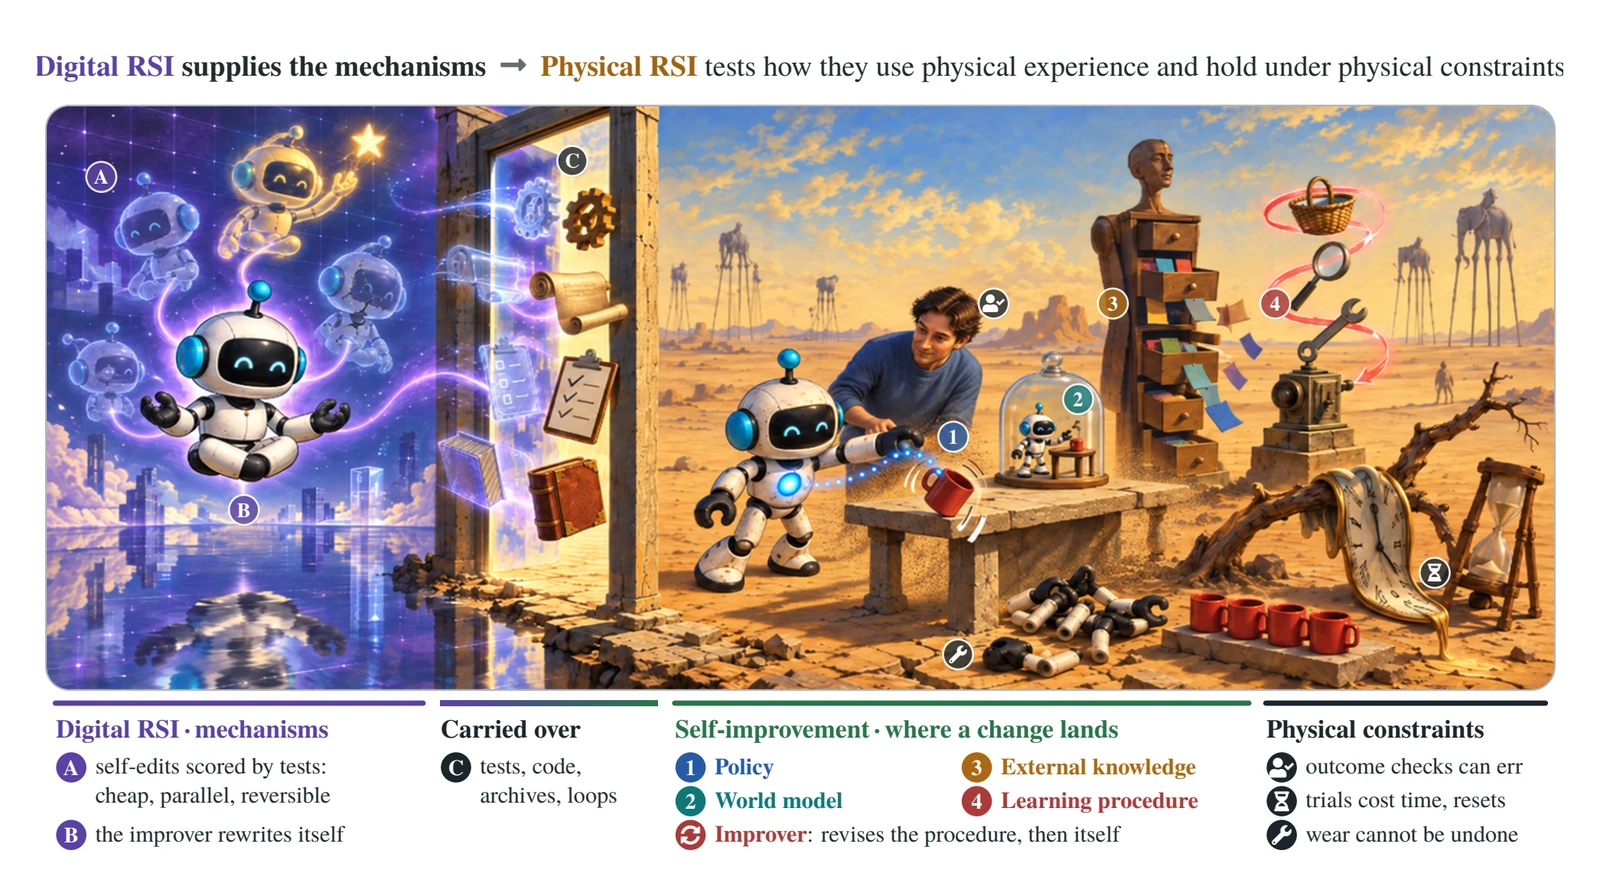
Toward Recursive Self-Improvement in Physical AI: Foundations, Mechanisms, and Open Problems. Survey overview and open reference library.
兴趣:humanoid robots and whole-body control
Python
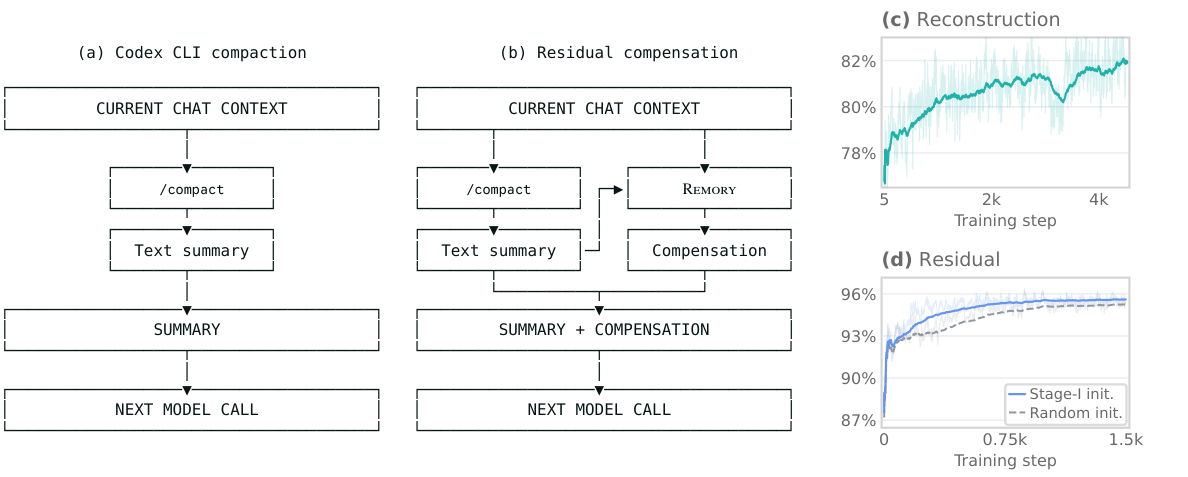
Remory: Learning Residual Memory for Context Compaction
兴趣:world models and video prediction for embodied agents
Python
StarVLA: A Lego-like Codebase for Vision-Language-Action Model Developing
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
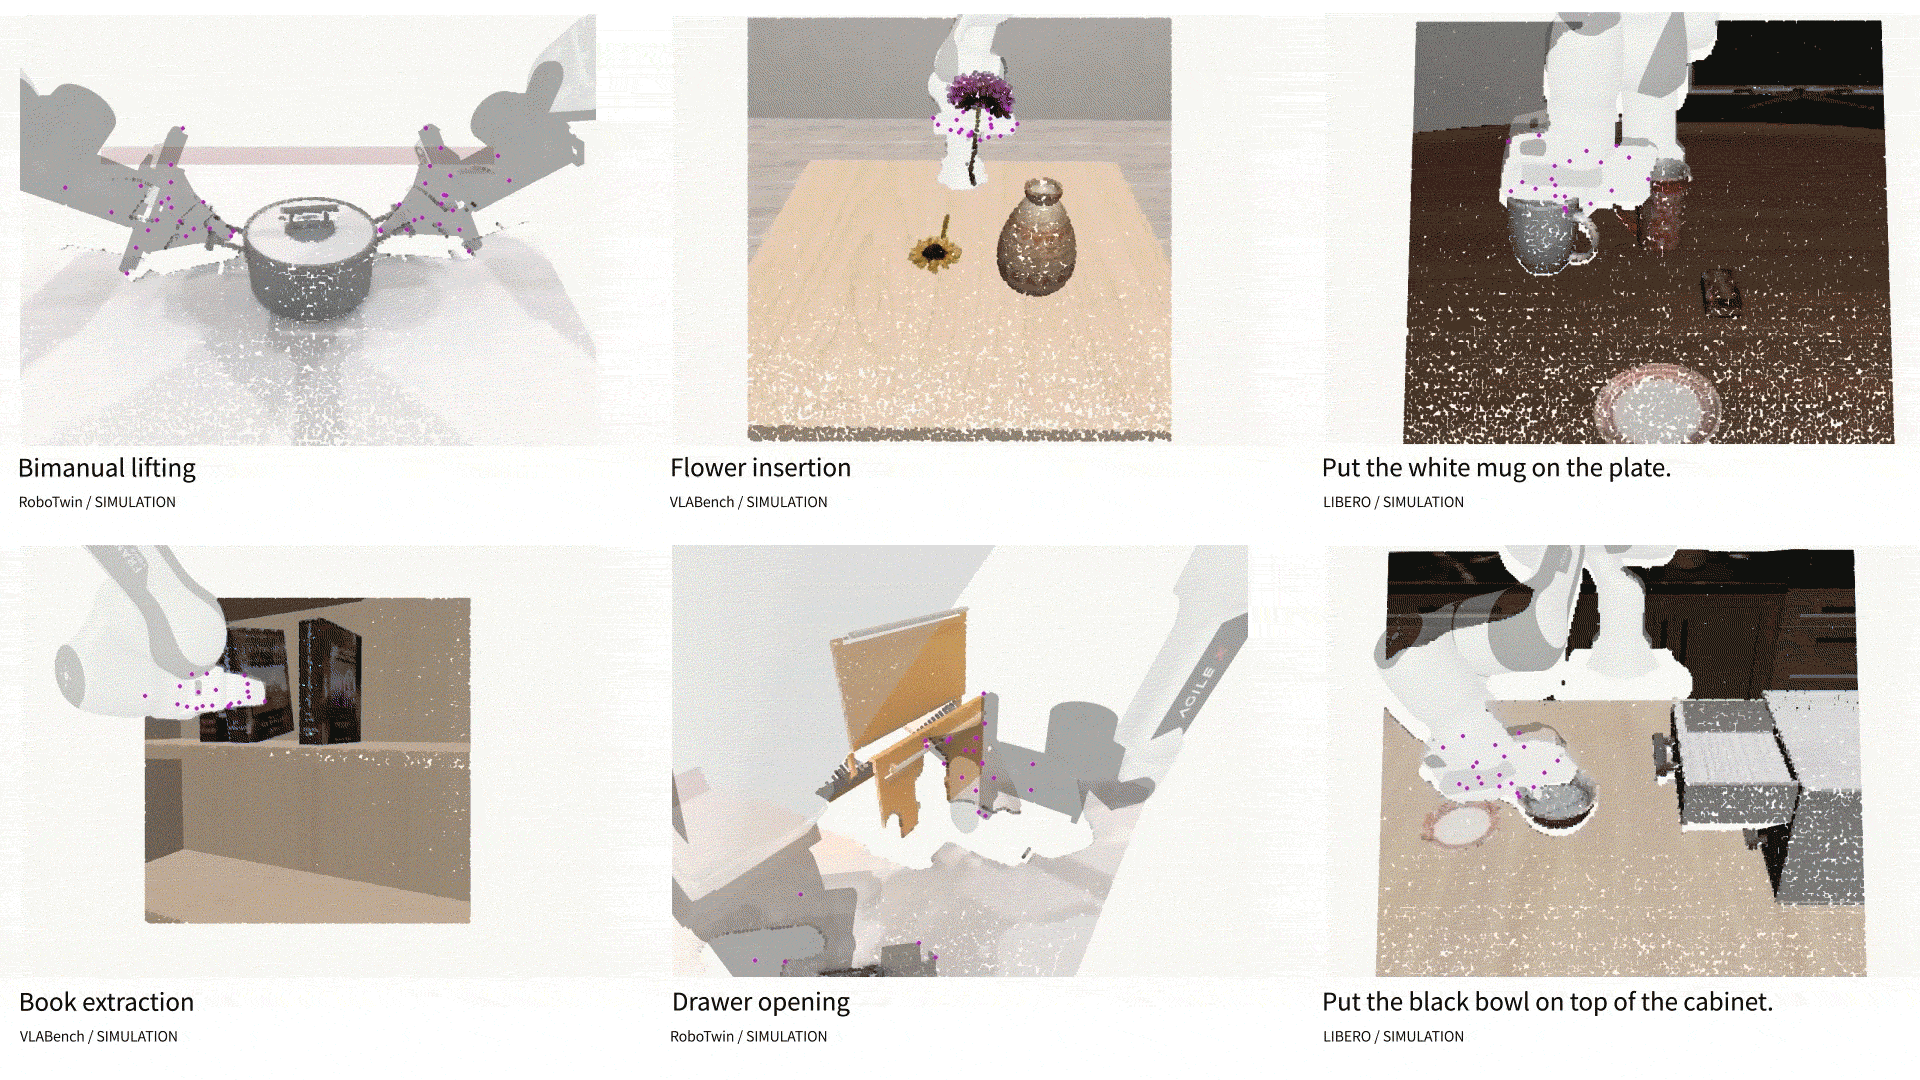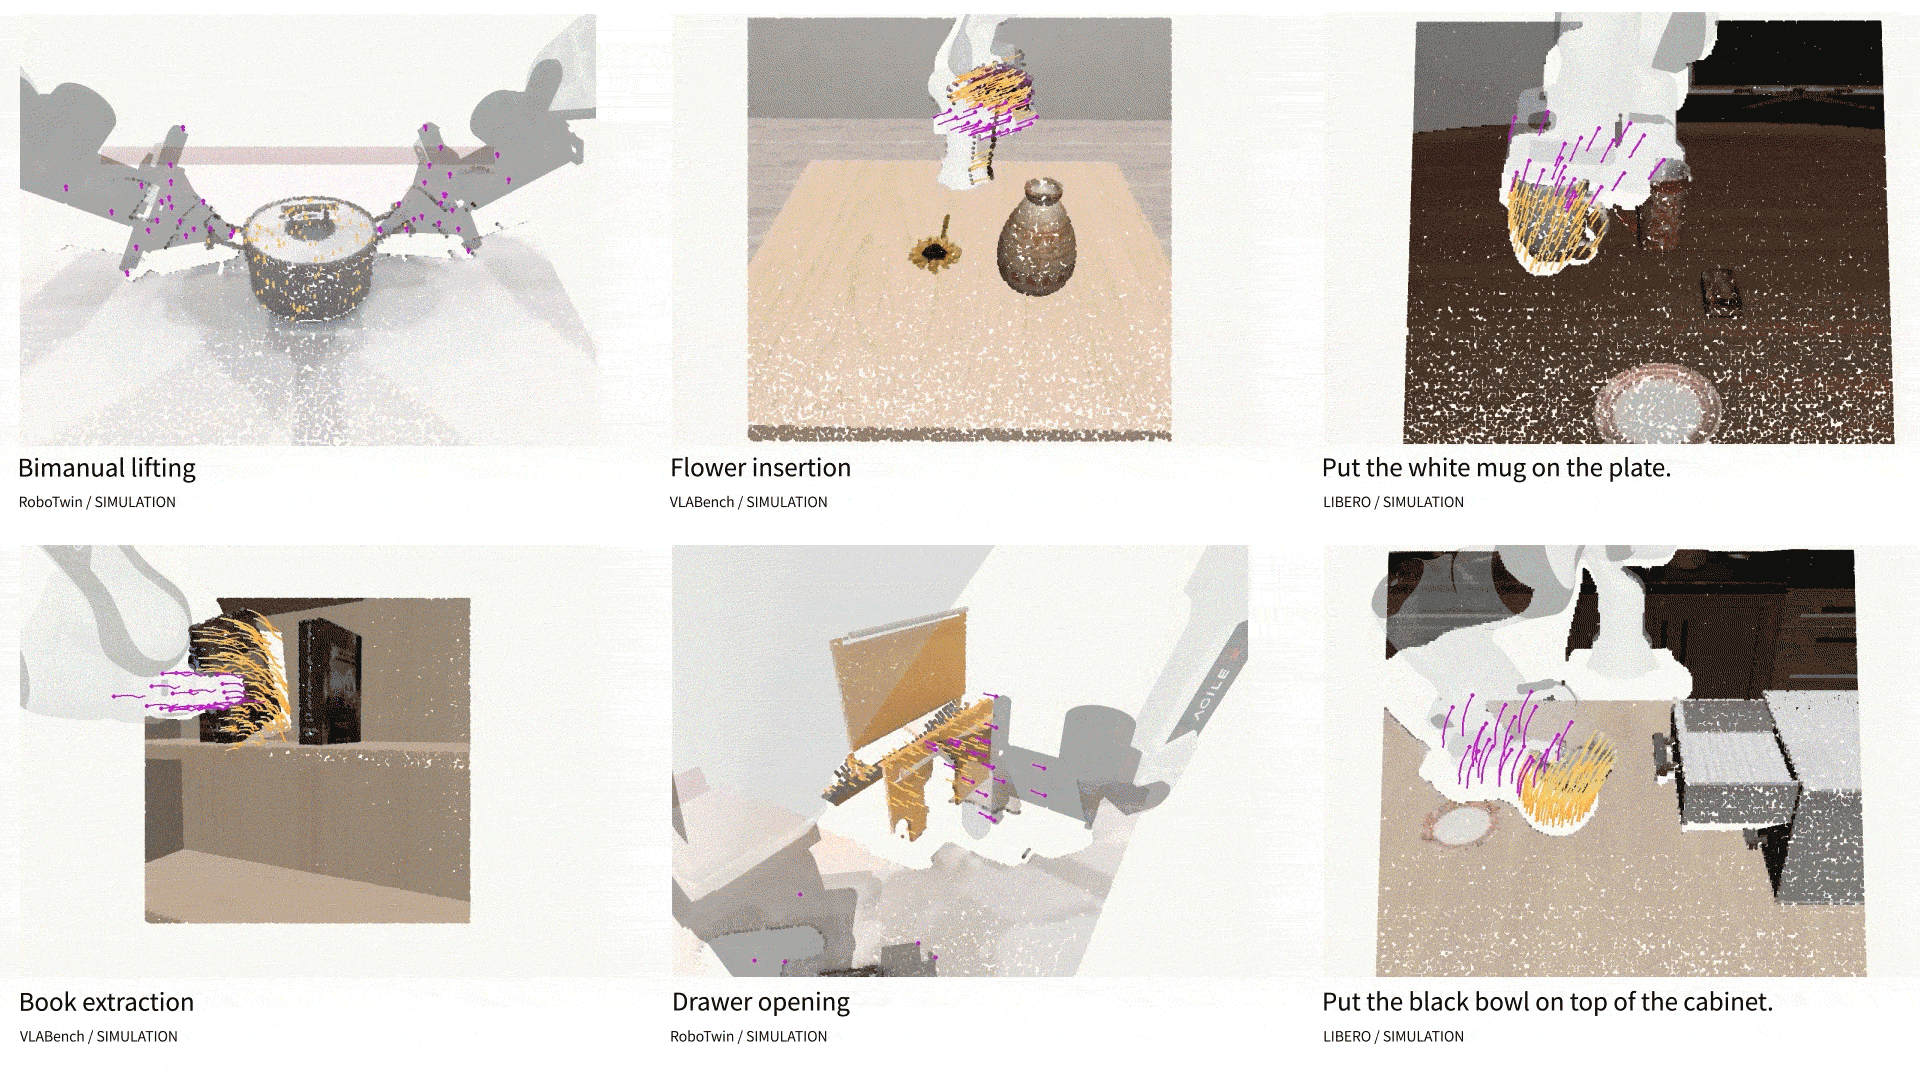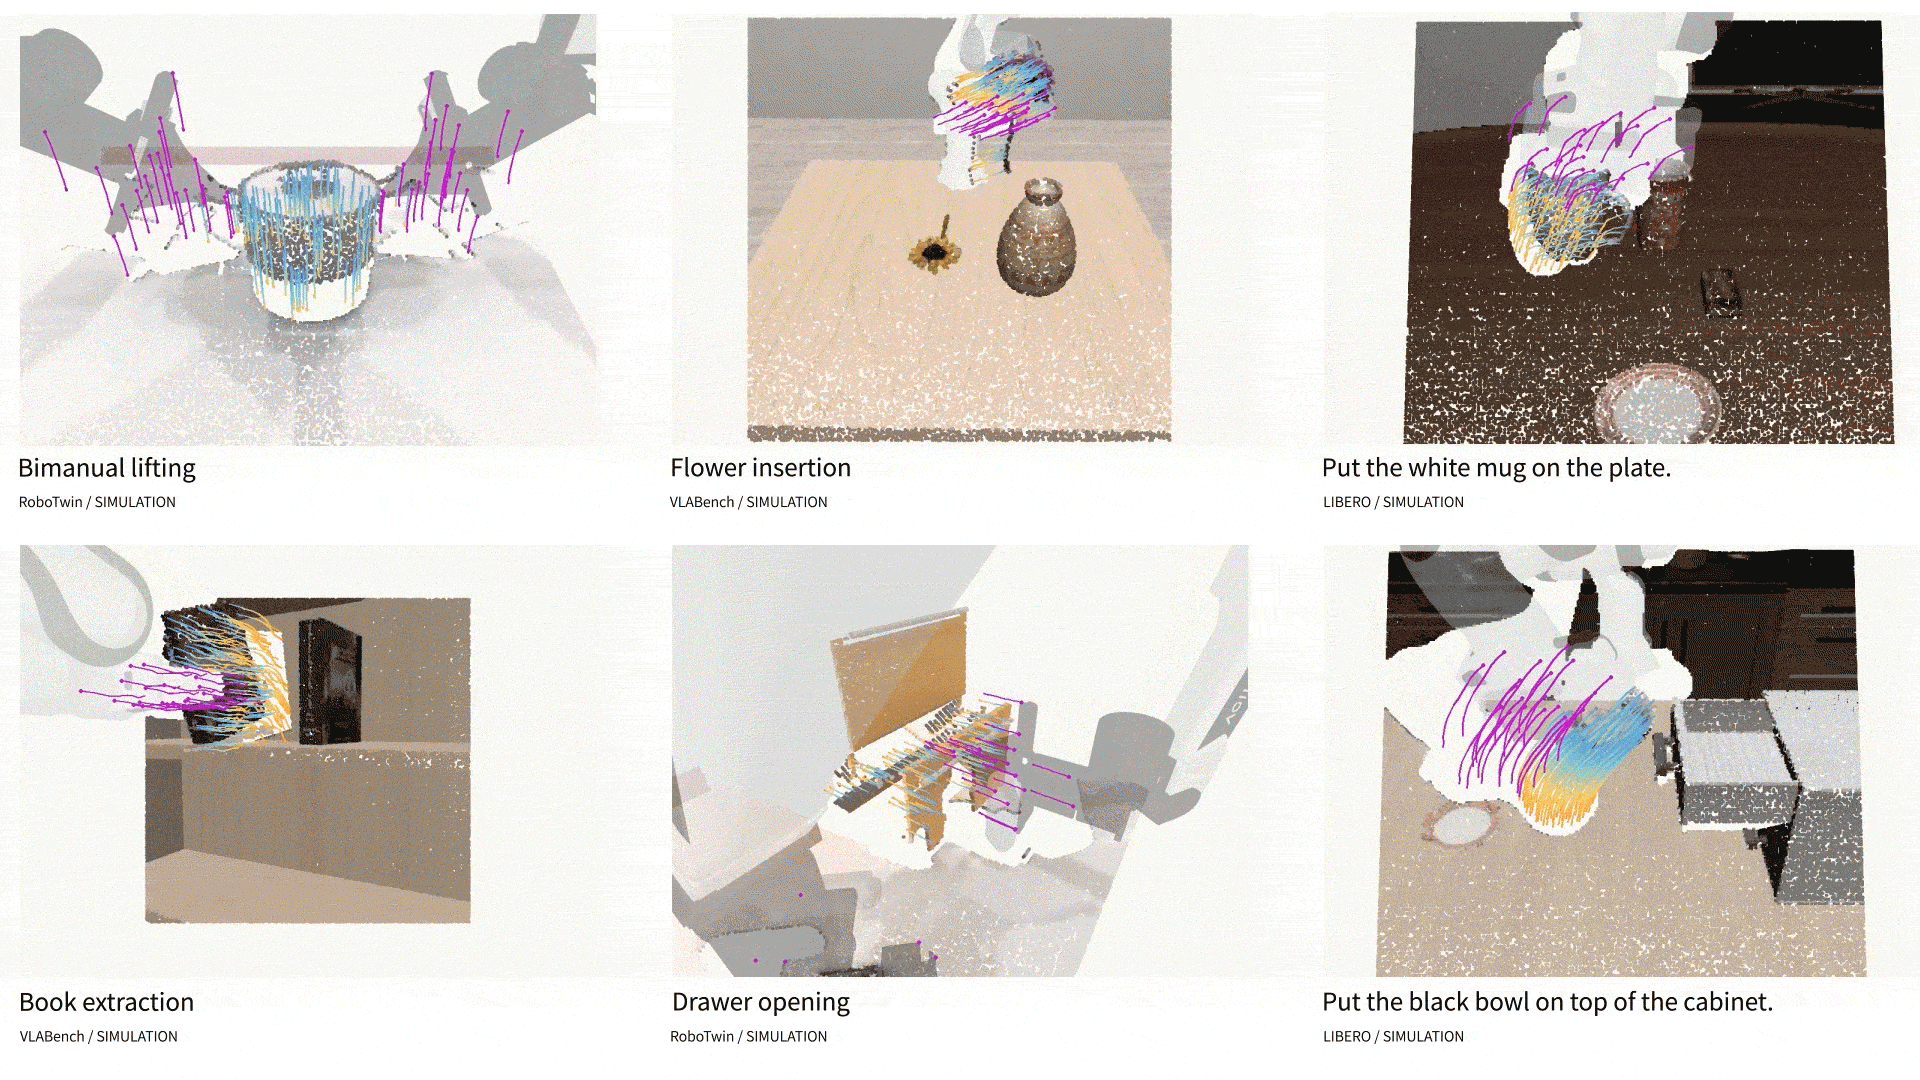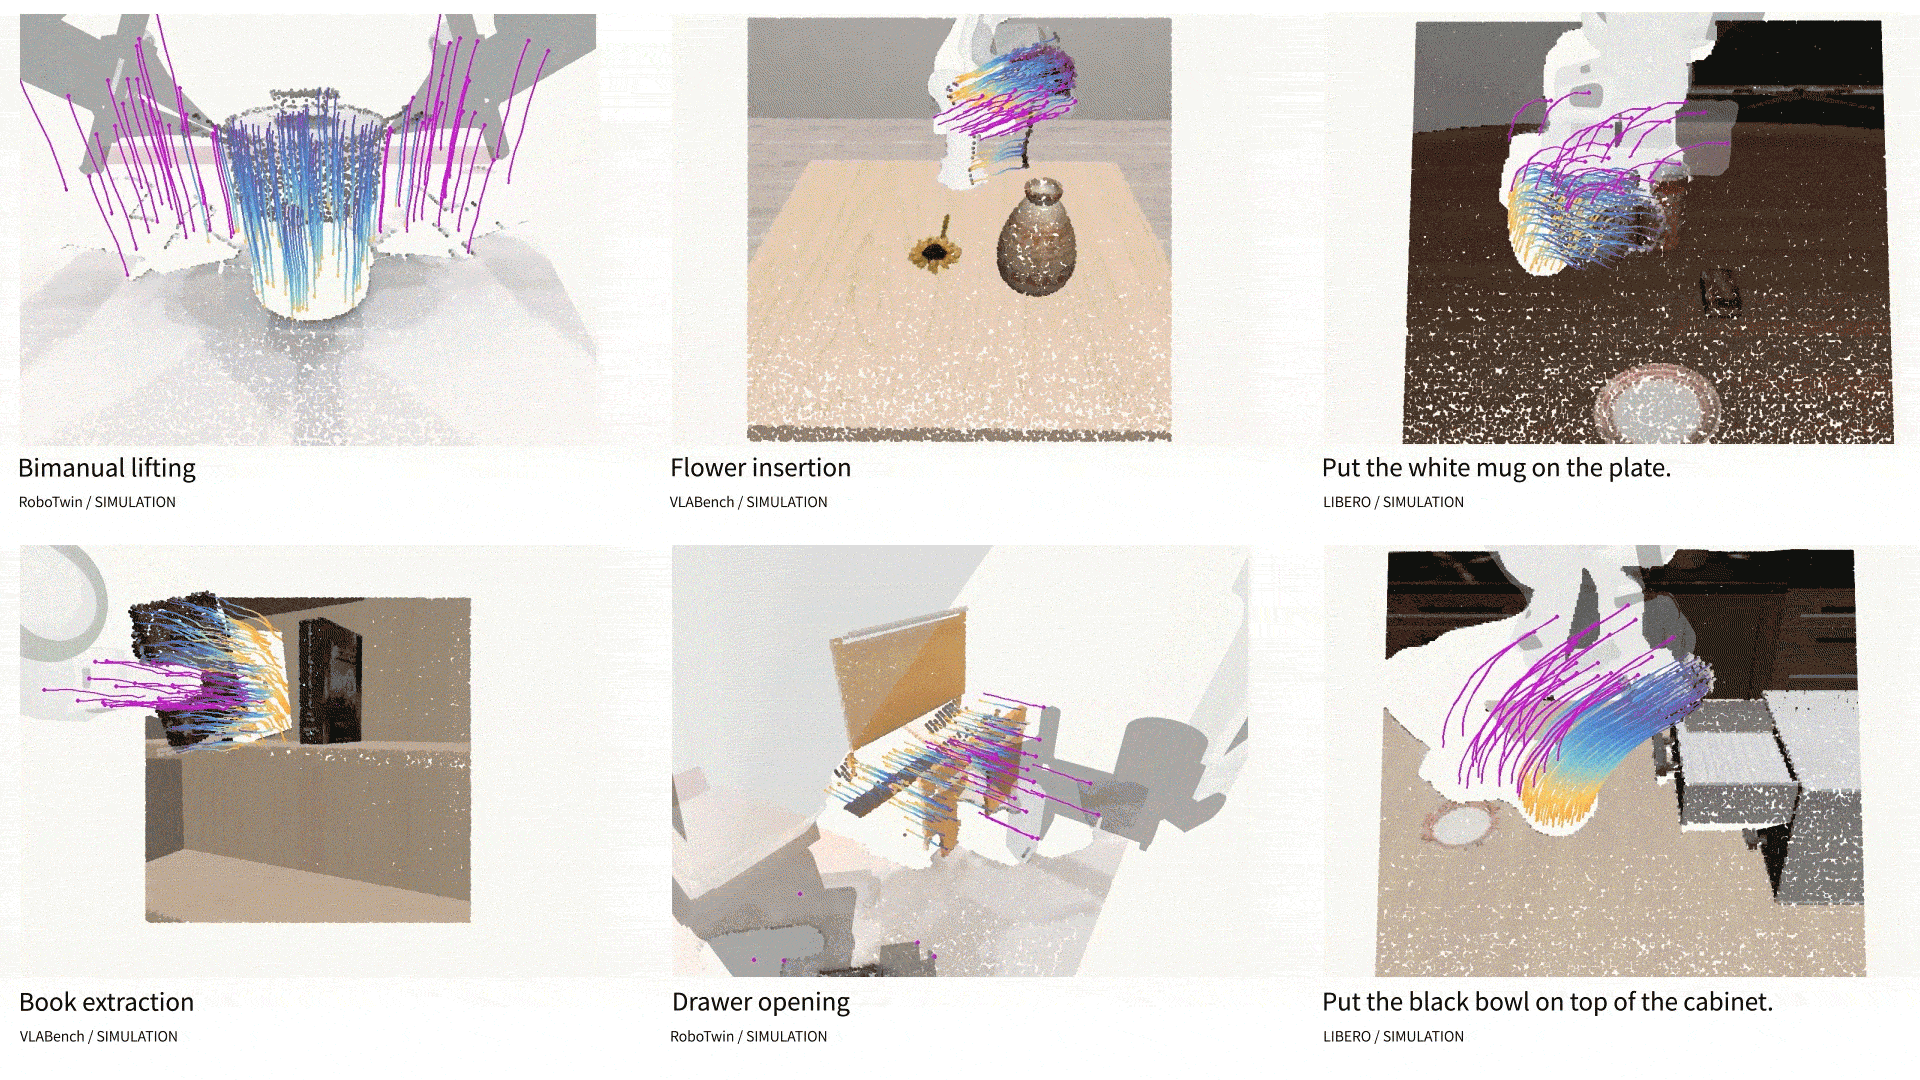
Official codebase for Unitas: A 3D-Native World Action Model for Embodied Manipulation
兴趣:vision-language-action (VLA) models and foundation models for robots
Python
The first exam for code agents in the physical world: frozen robot tasks from many benchmark suites, each answered with a program and verified in a separate sandbox. Runs on Harbor.
兴趣:vision-language-action (VLA) models and foundation models for robots