Tech Station

2026-10-24

0 篇论文 · 30 个项目 ← 2026-10-23 · 2026-10-25 →

GitHub 项目

#12024-12-08★ 4.2k +873

datawhalechina/every-embodied

Python

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

仅需Python基础,从0构建自己的具身智能机器人;从0逐步构建VLA/OpenVLA/SmolVLA/Pi0, 深入理解具身智能

embodied-agentembodied-aiembodied-intelligenceopenvlasmolvlavision-language-action-modelVLAvision-language-actionembodied

兴趣:world models and video prediction for embodied agents

#22026-08-26★ 379 +572

OpenMOSS/EasyWAM

Python

A unified framework for training, fine-tuning, and evaluating World Action Models

A unified framework for training, fine-tuning, and evaluating World Action Models

benchmarkcodebaseembodied-aifoundation-modelsloraroboticsvision-language-actionworld-action-modelvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#32026-10-05★ 199 +1新项目71

AetherLabsAI/Video2World

Python

Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective

Benchmarking Coding Agents for Interactive World Modeling from Embodied Videos - Rethinking Embodied Real2Sim from a Software Engineering Perspective

benchmarkcoding-agentembodied-aifoundation-modelsreal-to-simrobot-learningroboticssimulationrobotembodied

兴趣:world models and video prediction for embodied agents

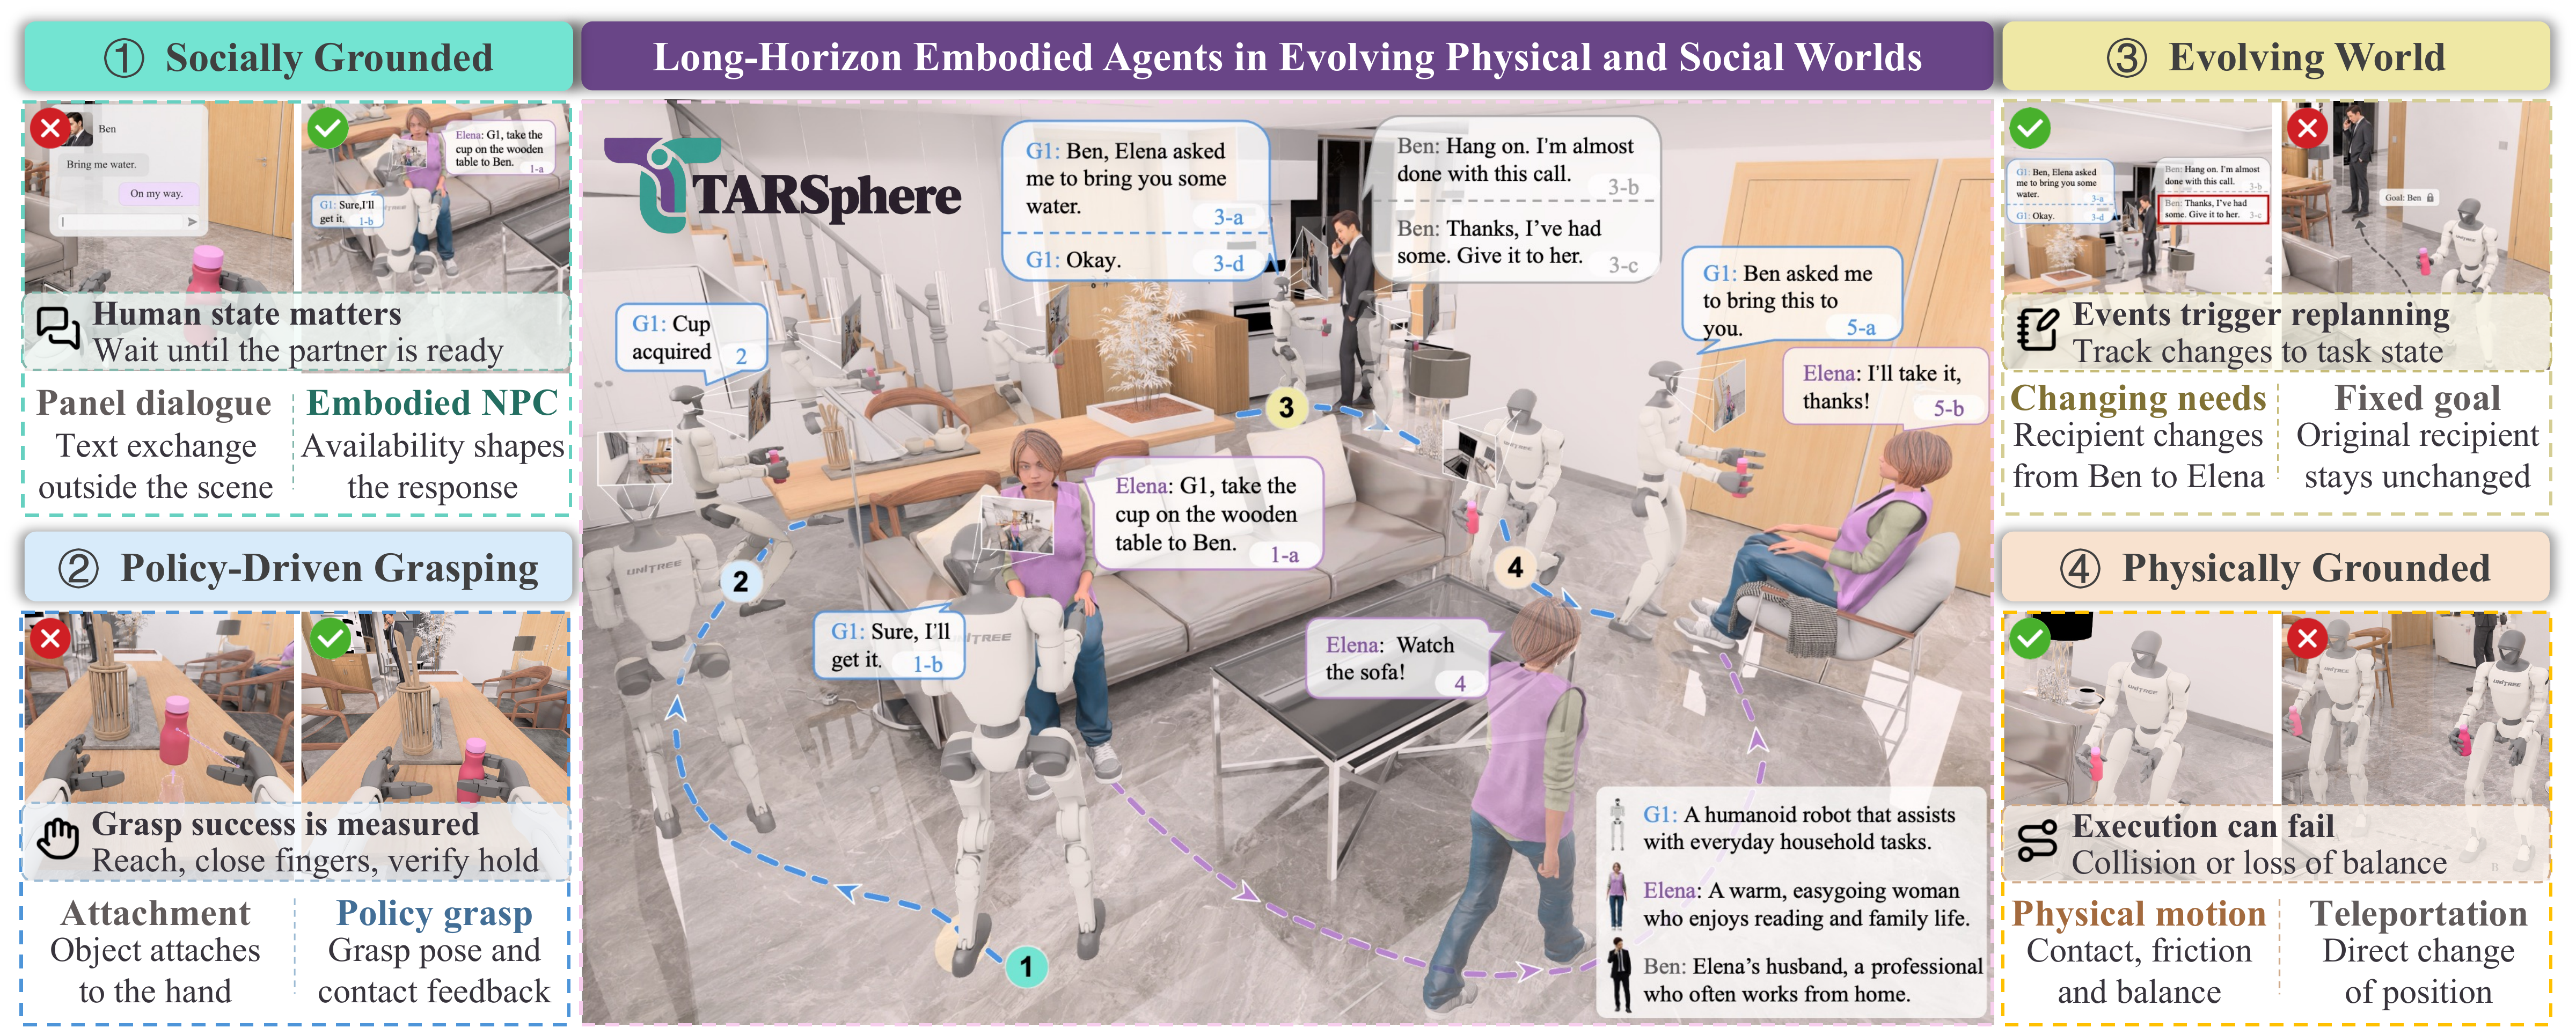
#42026-10-21★ 17 +1新项目71

xuyicheng-zju/TARSphere

Python

A robot-oriented full-stack framework for long-horizon embodied agents in evolving physical and social environments.

A robot-oriented full-stack framework for long-horizon embodied agents in evolving physical and social environments.

benchmarkembodied-aiisaac-simroboticsrobotembodied

兴趣:world models and video prediction for embodied agents

#52026-07-19★ 681 +371

RealXiaoze/humanoid-motion-intelligence

人形机器人运动智能论文、开源项目、产业与求职知识库

人形机器人运动智能论文、开源项目、产业与求职知识库

embodied-aihumanoid-roboticslocomotionmotion-controlreinforcement-learningrobot-learningsim2realvlarobotVLAhumanoidlocomotionembodied

兴趣:humanoid robots and whole-body control

#62024-12-24★ 38470

manumerous/wb_humanoid_mpc

C++

Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control

Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control

aidata-generationhumanoidhumanoid-robotlocomotionmpcnonlinearoptimizationrobotmanipulationhumanoidlocomotion

兴趣:humanoid robots and whole-body control

#72023-09-06★ 29.5k +32770

harvard-edge/cs249r_book

Python

Machine Learning Systems: Foundations, Scaling, Agentic AI, and Physical AI (Vols I–IV) • Harvard CS249r | https://mlsysbook.ai

Machine Learning Systems: Foundations, Scaling, Agentic AI, and Physical AI (Vols I–IV) • Harvard CS249r | https://mlsysbook.ai

agentic-aiai-agentsartificial-intelligencecloud-mlcomputer-systemscoursewaredeep-learningedge-machine-learningembodied

兴趣:multi-agent systems and LLM agents

#82026-09-30★ 176 +13新项目70

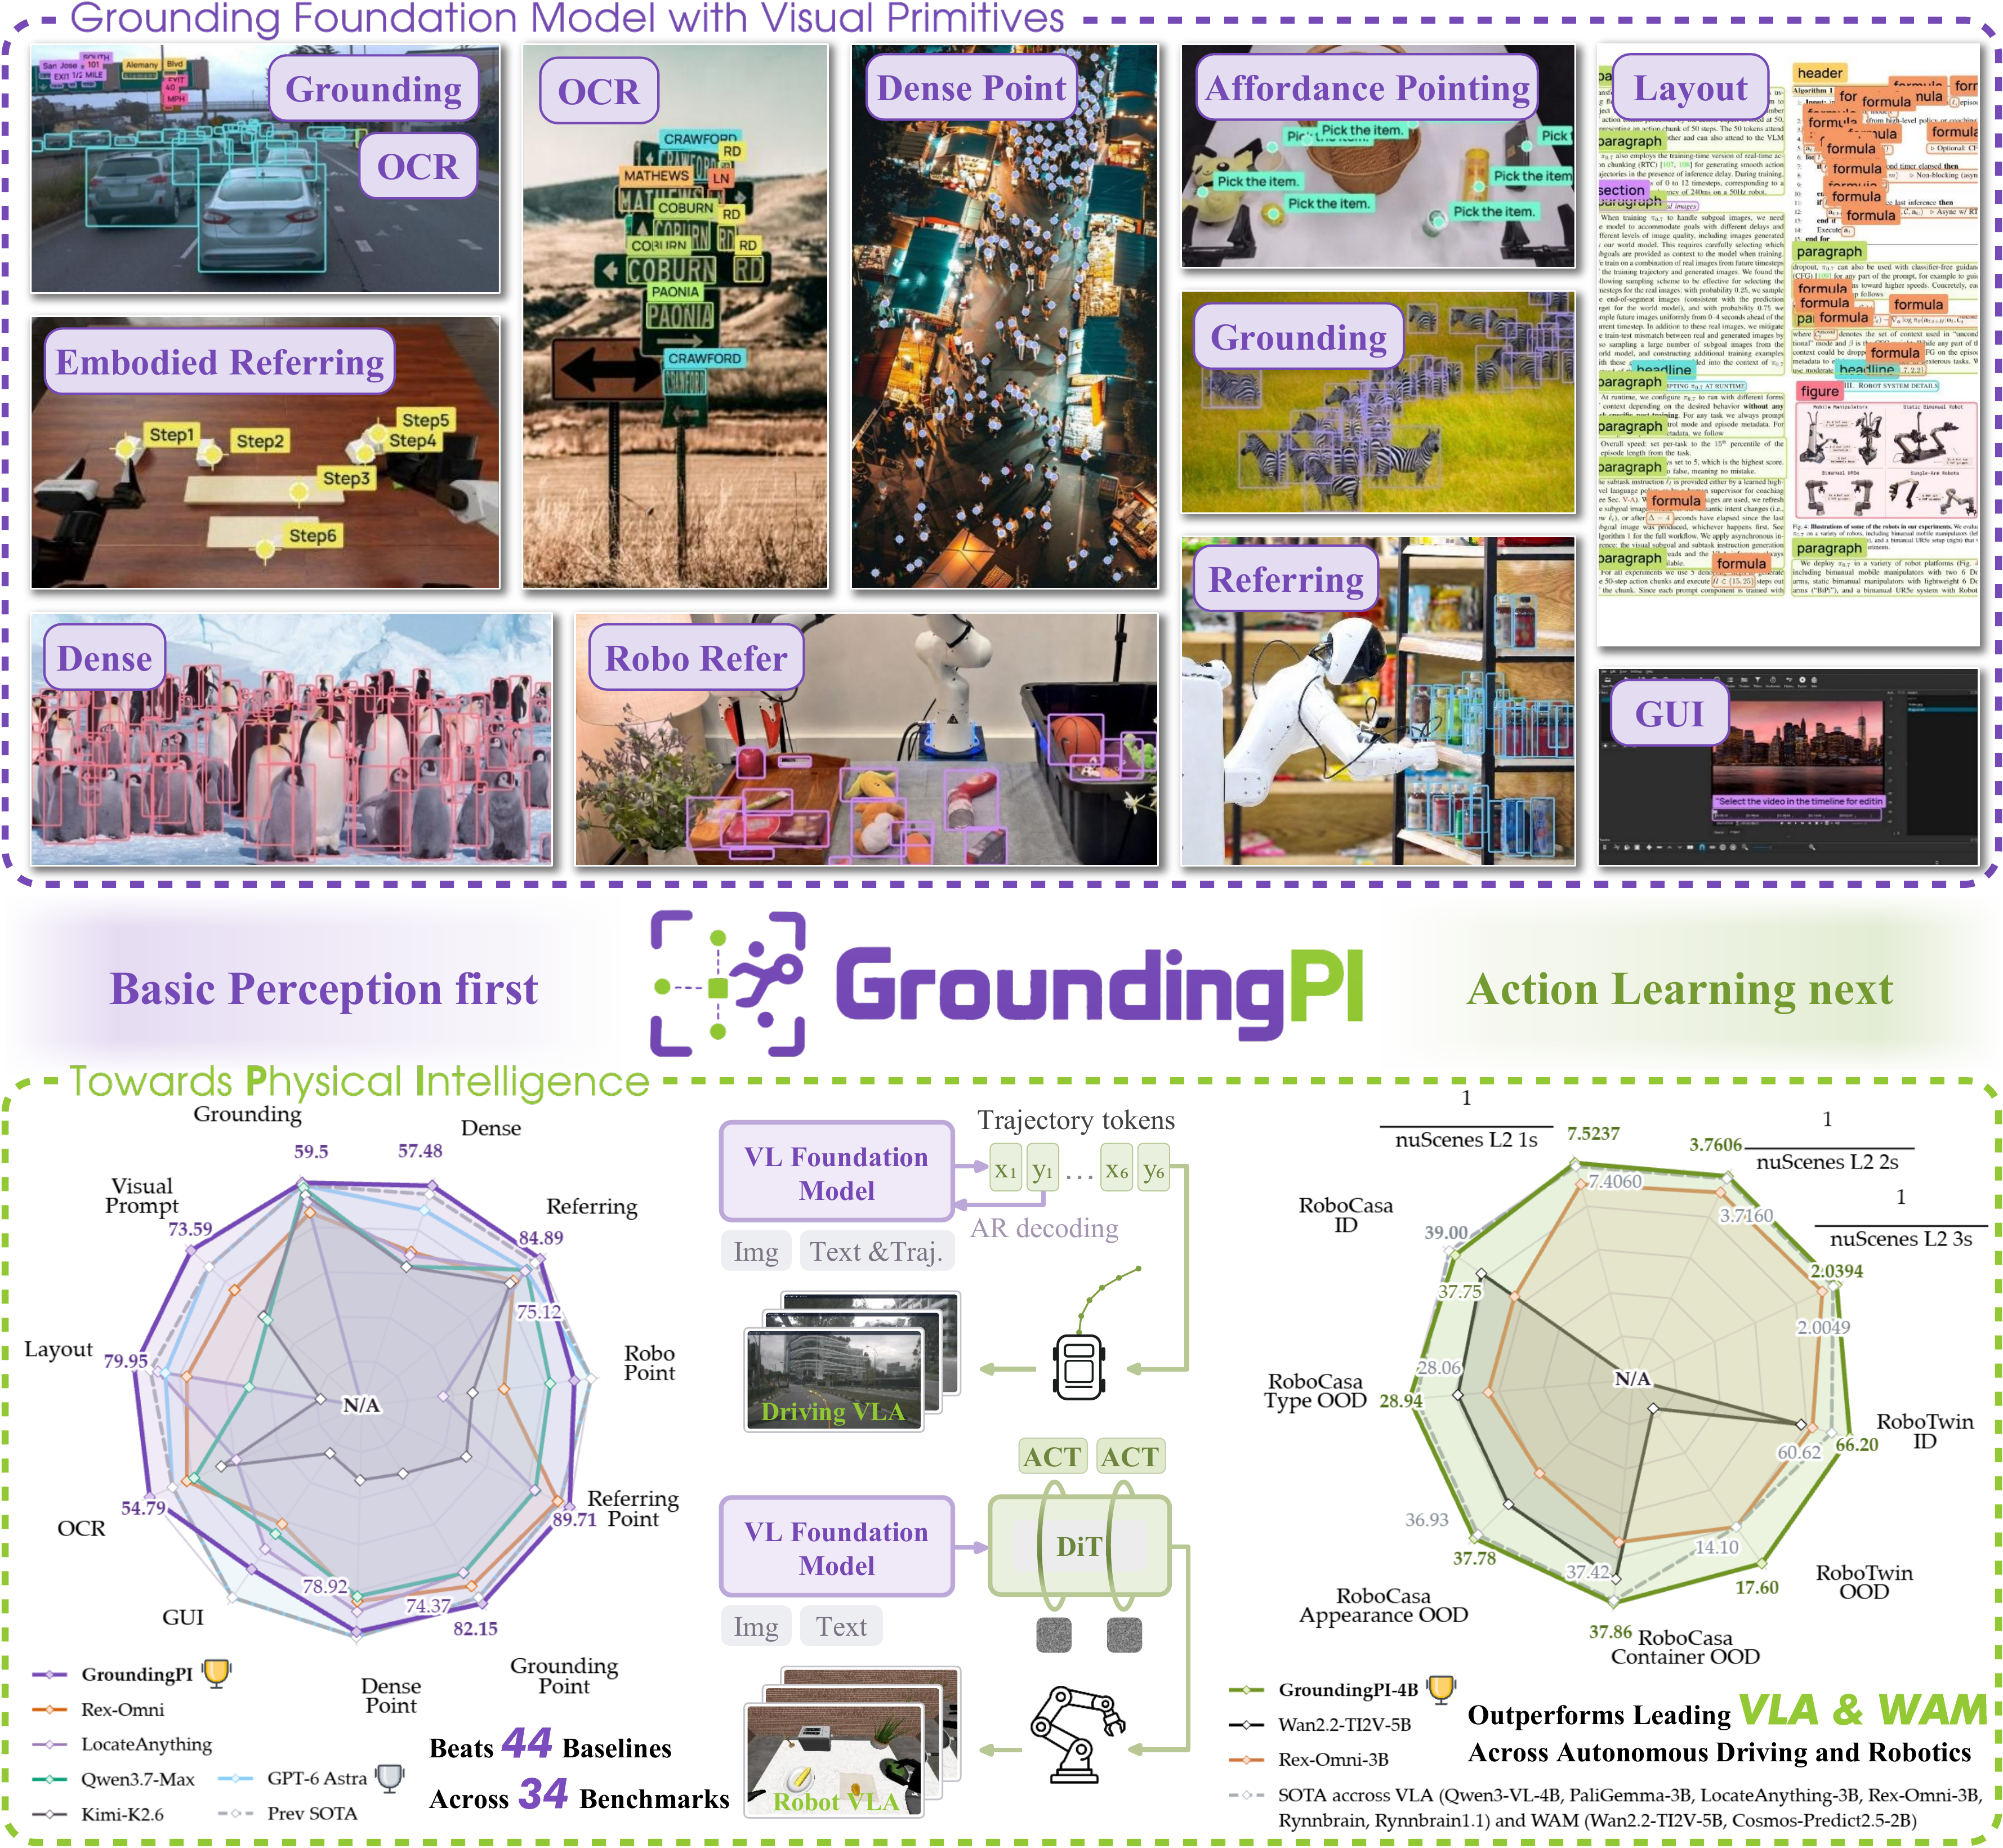
groundingpi/GroundingPI

Python

A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and i…

A 4B grounding foundation model for physical intelligence. Unifies detection, referring, pointing, OCR, GUI, and layout grounding, achieving SOTA overall across 34 benchmarks and improving robot generalization and data efficiency in controlled evaluations.

embodied-aigui-groundingobject-detectionocrphysical-intelligencepointingrobot-learningvision-language-modelrobotVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#92022-11-16★ 8.5k +1570

isaac-sim/IsaacLab

Python

Unified framework for robot learning with multi-physics/renderer support

Unified framework for robot learning with multi-physics/renderer support

isaac-simomniverse-kit-extensionrobot-learningroboticsrobot

兴趣:3D perception, point clouds and scene understanding for robotics

#102026-10-16★ 39 +6新项目70

Ropedia/DONIC

Python

DONIC: Generalist Dexterous Bimanual Tracking Control from Human Demonstrations

DONIC: Generalist Dexterous Bimanual Tracking Control from Human Demonstrations

bimanualdexterous-manipulationhand-object-interactionreinforcement-learningmanipulationdexterous

兴趣:robot manipulation and grasping with learned policies

#112026-09-02★ 163 +1370

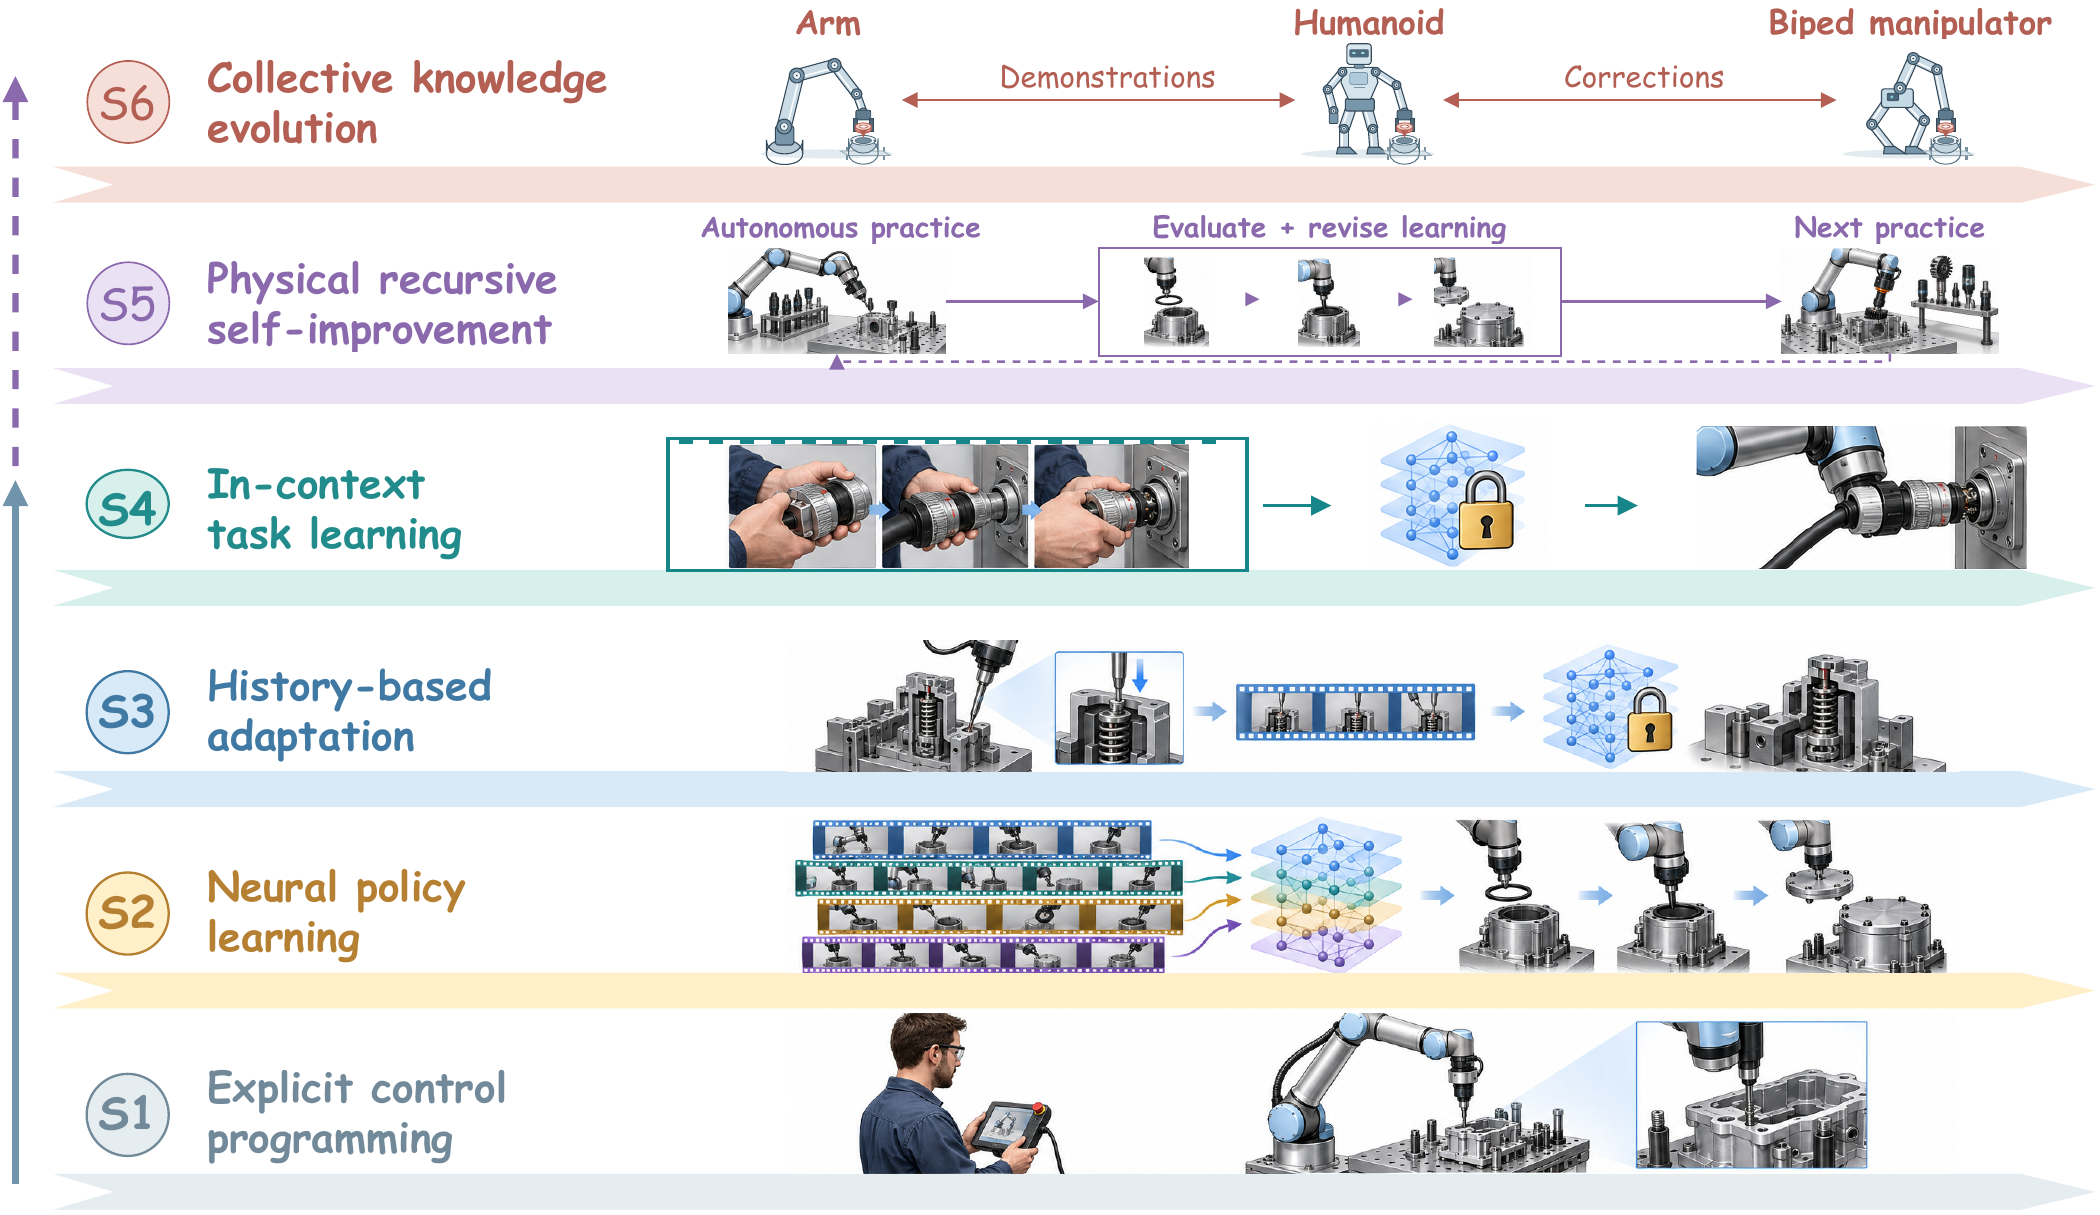
JethroJames/awesome-robots-icl

Python

Companion repository for “In-Context Learning for Robots: Methods and Applications” — methods, datasets, and benchmarks organized by taxonomy and release date.

Companion repository for “In-Context Learning for Robots: Methods and Applications” — methods, datasets, and benchmarks organized by taxonomy and release date.

awesome-listembodied-aiimitation-learningin-context-learningrobot-learningroboticsvision-language-actionworld-modelsrobotvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#122026-06-24★ 325 +1170

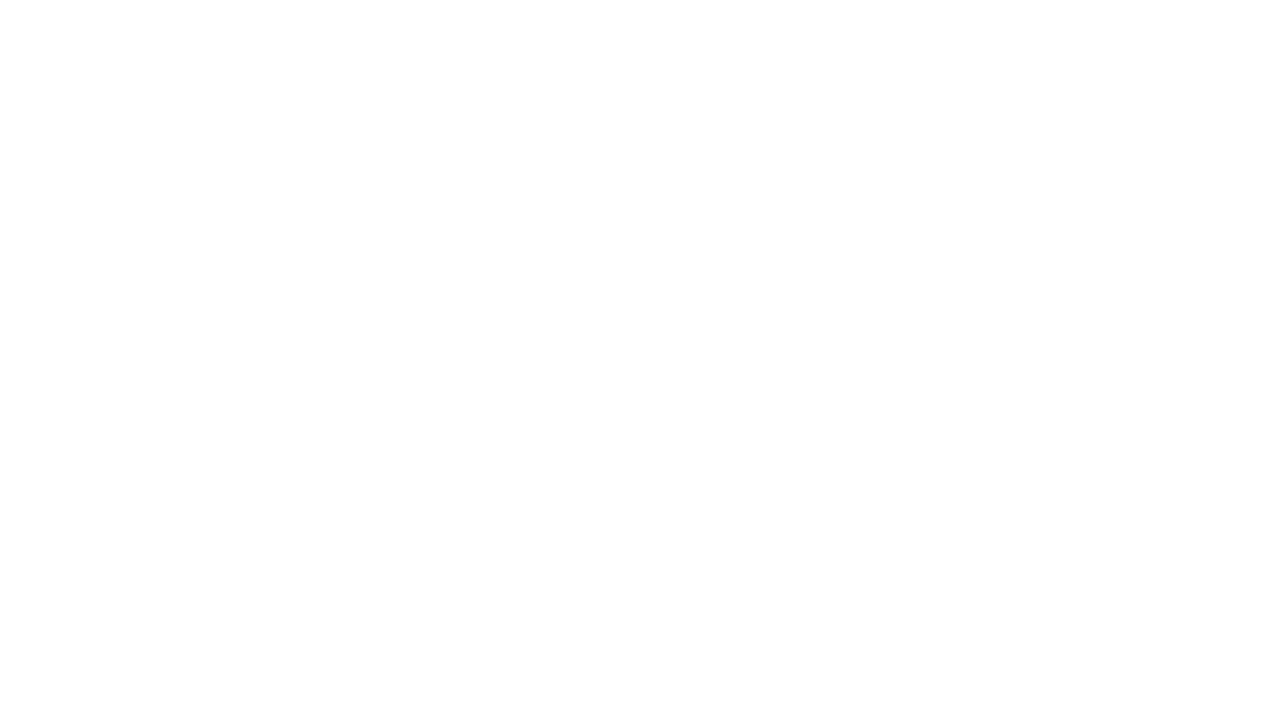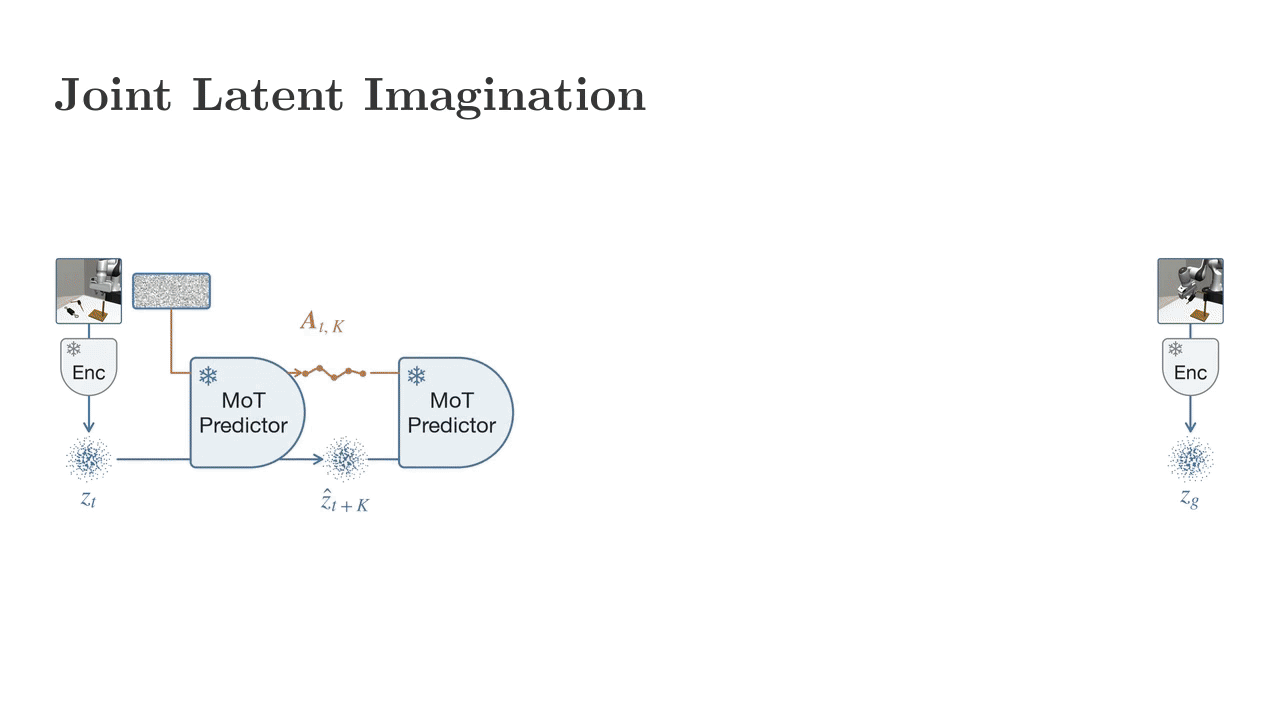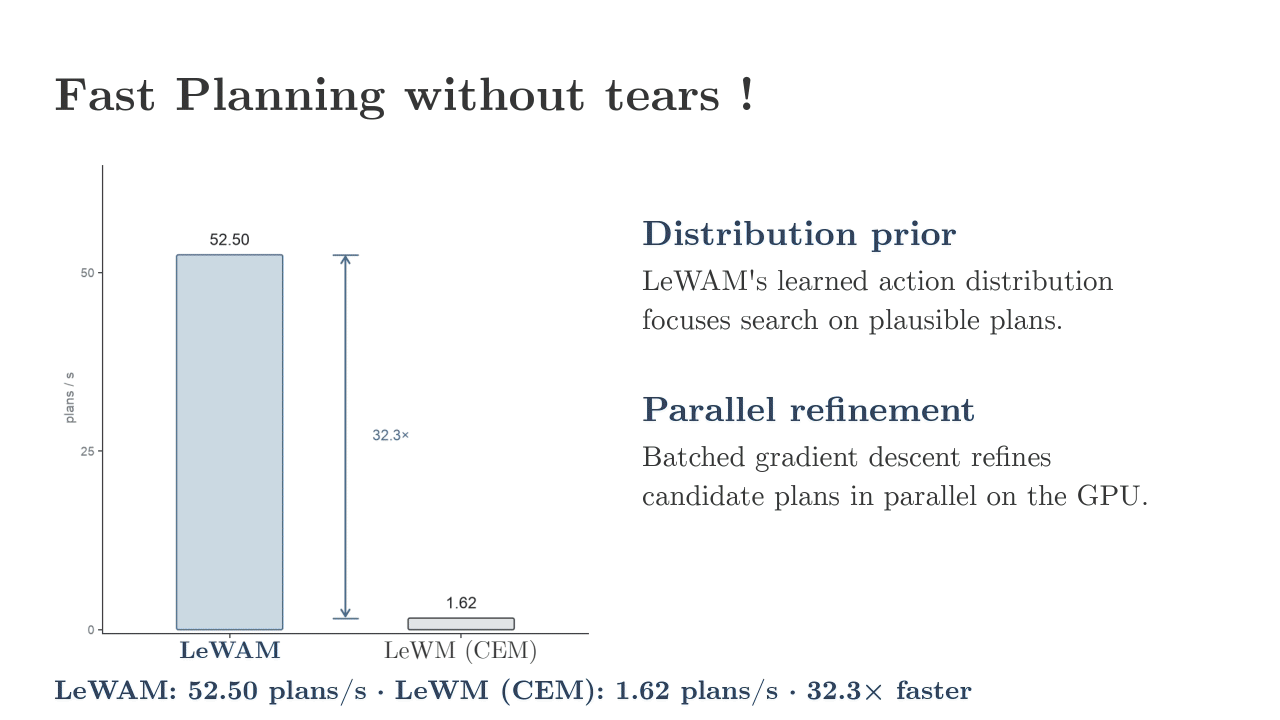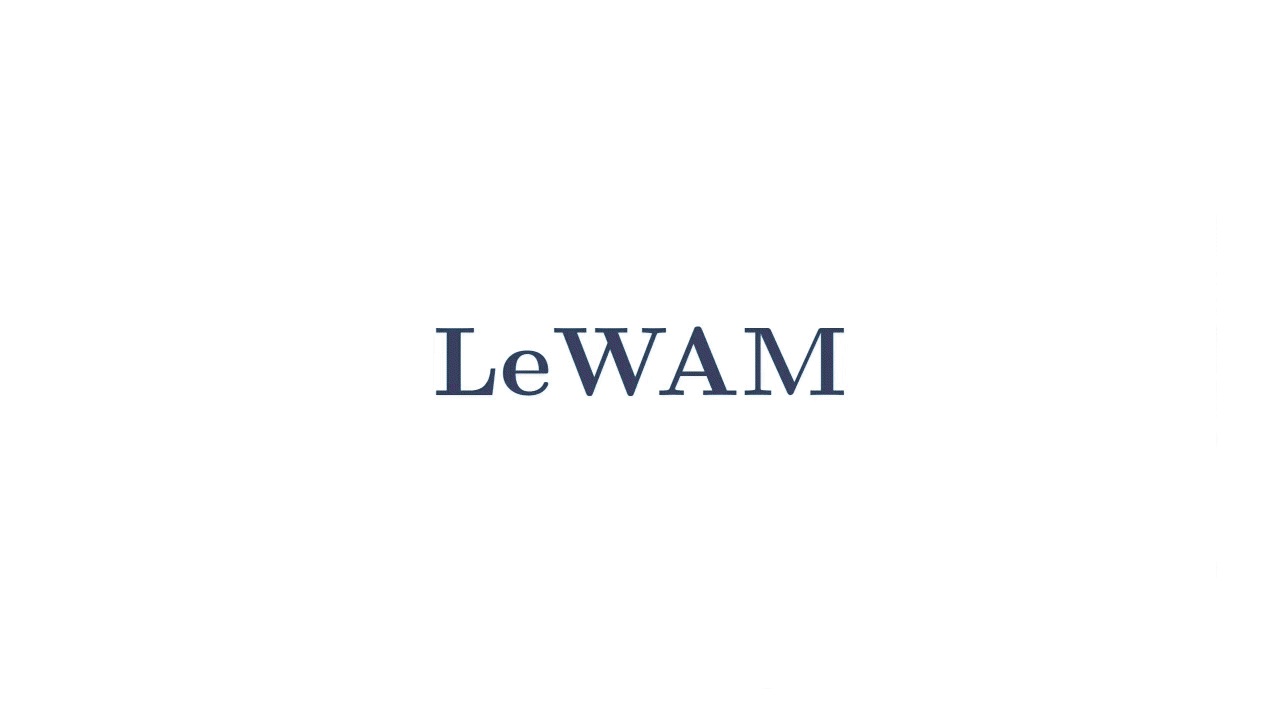
MinghaoFu/lewam

Python

LeWAM: End-to-End World and Action Modeling with JEPAs

LeWAM: End-to-End World and Action Modeling with JEPAs

jeparobot-learningworld-modelsrobot

兴趣:vision-language-action (VLA) models and foundation models for robots
#132026-04-18★ 117 +169

murobotics-ai/handumi-hw

An open-source, hand-worn variant of UMI for collecting bimanual manipulation data without a robot in the loop: modular for any parallel-jaw gripper.

An open-source, hand-worn variant of UMI for collecting bimanual manipulation data without a robot in the loop: modular for any parallel-jaw gripper.

data-collectionimitation-learningrobotmanipulation

兴趣:robot manipulation and grasping with learned policies

#142024-02-29★ 16869

RobotControlStack/robot-control-stack

Python

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for…

A lean, ROS-free sim-to-real framework for training and deploying Vision-Language-Action (VLA) models and RL agents. Native MuJoCo Gymnasium wrappers with synchronous execution for Franka, UR5e, xArm, SO101 and YAM.

frankagymnasiummujocoreinforcement-learningrobot-learningrobot-manipulationsim-to-realvision-language-actions-modelsrobotmanipulationVLAvision-language-actionsim-to-real

兴趣:vision-language-action (VLA) models and foundation models for robots

#152026-10-07★ 442 +27新项目69

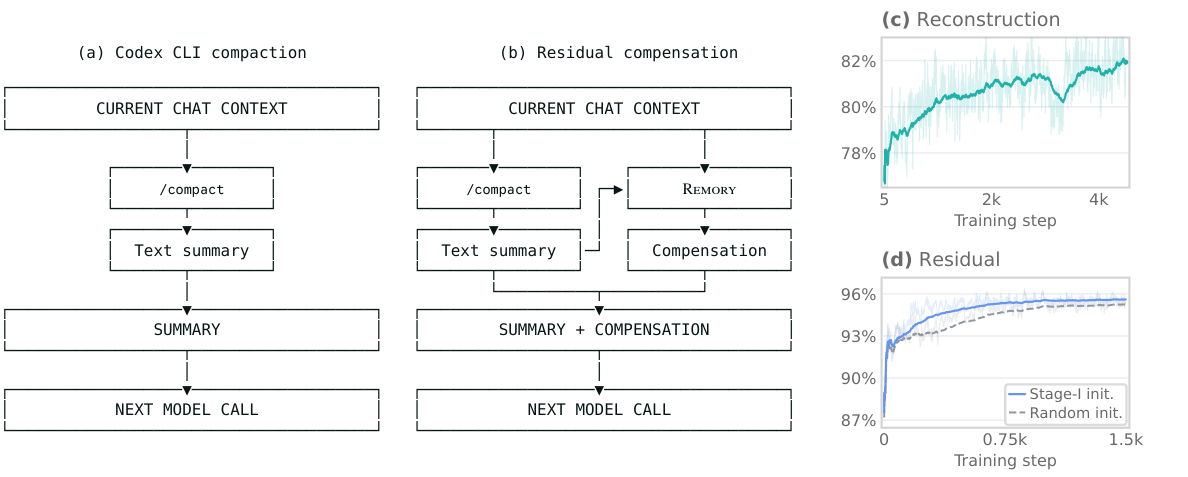
fudan-generative-vision/Remory

Python

Remory: Learning Residual Memory for Context Compaction

Remory: Learning Residual Memory for Context Compaction

context-compactioninferencellm-agentsresidual-memory

兴趣:world models and video prediction for embodied agents

#162024-01-26★ 28.4k +968

huggingface/lerobot

Python

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

🤗 LeRobot: Making AI for Robotics more accessible with end-to-end learning

兴趣:imitation learning and diffusion policies for robot control

#172026-04-22★ 22.9k +19868

earthtojake/text-to-cad

Python

Give your agent CAD superpowers.

Give your agent CAD superpowers.

agentsai-agentscadmechanical-engineeringroboticsstepstlstp

兴趣:multi-agent systems and LLM agents

#182025-08-14★ 5.5k +568

RLinf/RLinf

Python

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

RLinf: Reinforcement Learning Infrastructure for Embodied and Agentic AI

agentic-aiembodied-aireinforcement-learningrl-infrarlinfvla-rlVLAembodied

兴趣:vision-language-action (VLA) models and foundation models for robots

#192025-11-23★ 73568

sou350121/VLA-Handbook

HTML

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

本项目旨在为致力于进入VLA(Vision-Language-Action)领域的算法工程师提供一份全中文、实战导向的学习/面试手册。 不同于通用的 CV/NLP 面试指南,本项目聚焦于 Robotics 特有的挑战

chinesedeep-learningembodied-aillmrobot-learningroboticsvision-language-actionvlarobotVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#202026-10-15★ 22 +3新项目67

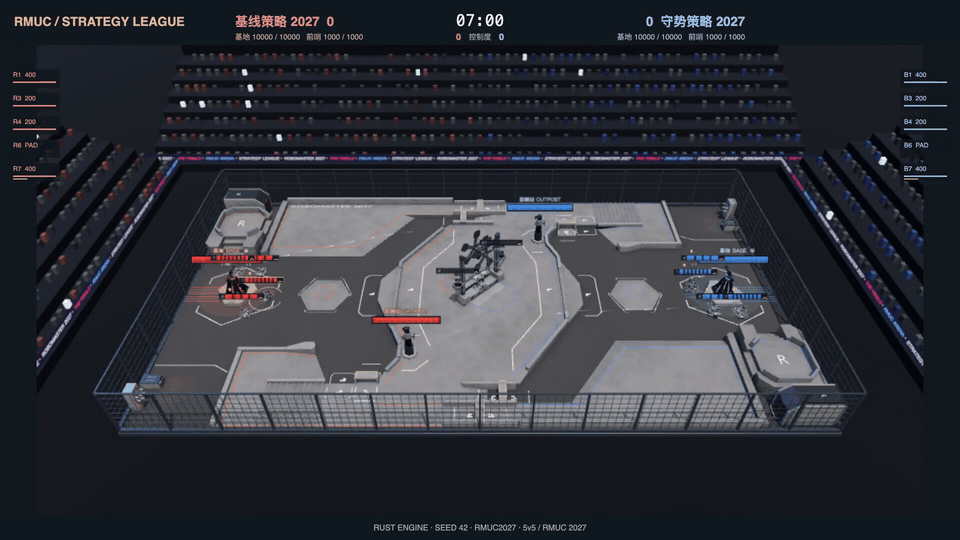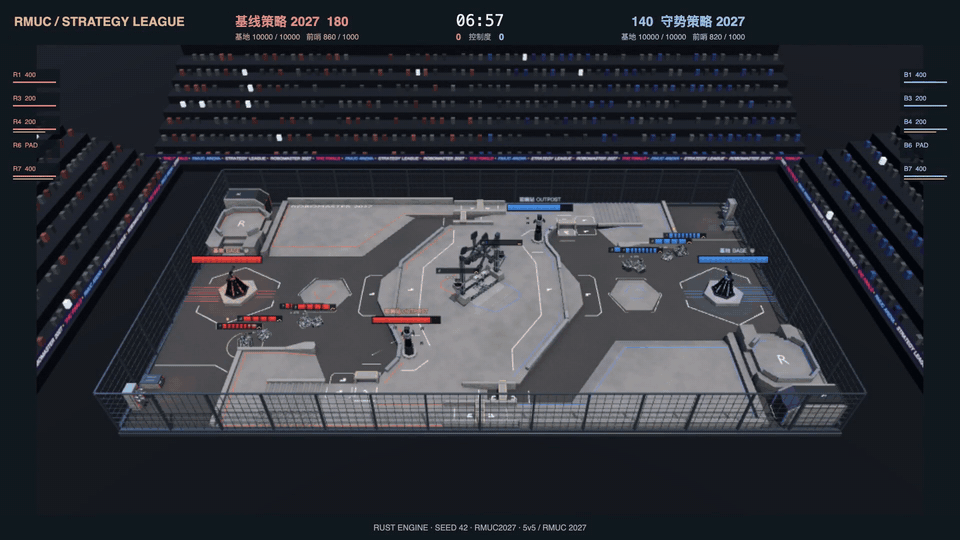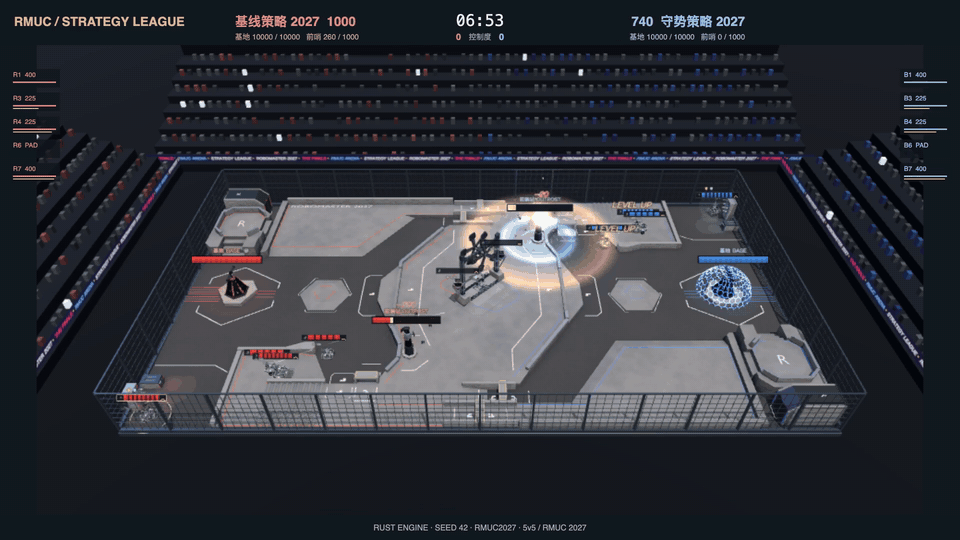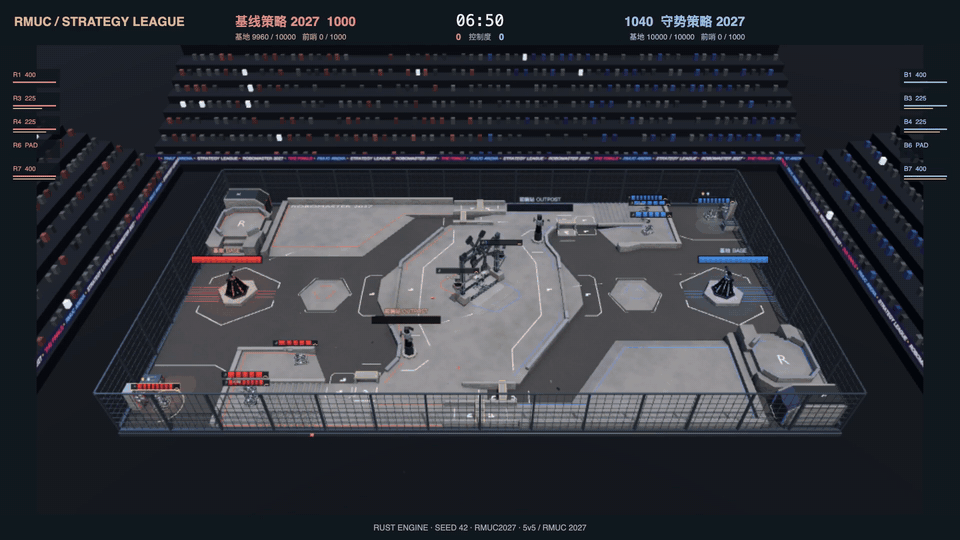
RM-Arena/Arena-1

Python

A RoboMaster-inspired arena for agent strategy, programming and multi-robot cooperation · Non-commercial learning only

A RoboMaster-inspired arena for agent strategy, programming and multi-robot cooperation · Non-commercial learning only

electronroboticssimulationsource-availablerobot

兴趣:multi-agent systems and LLM agents

#212026-08-29★ 9567

OpenBMB/SimpleMemVLA

Python

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.

embodied-ailong-horizon-roboticsmultimodal-learningnative-video-memoryrobot-learningrobot-manipulationstreaming-inferencevideo-understandingrobotmanipulationVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#222025-04-04★ 1.9k67

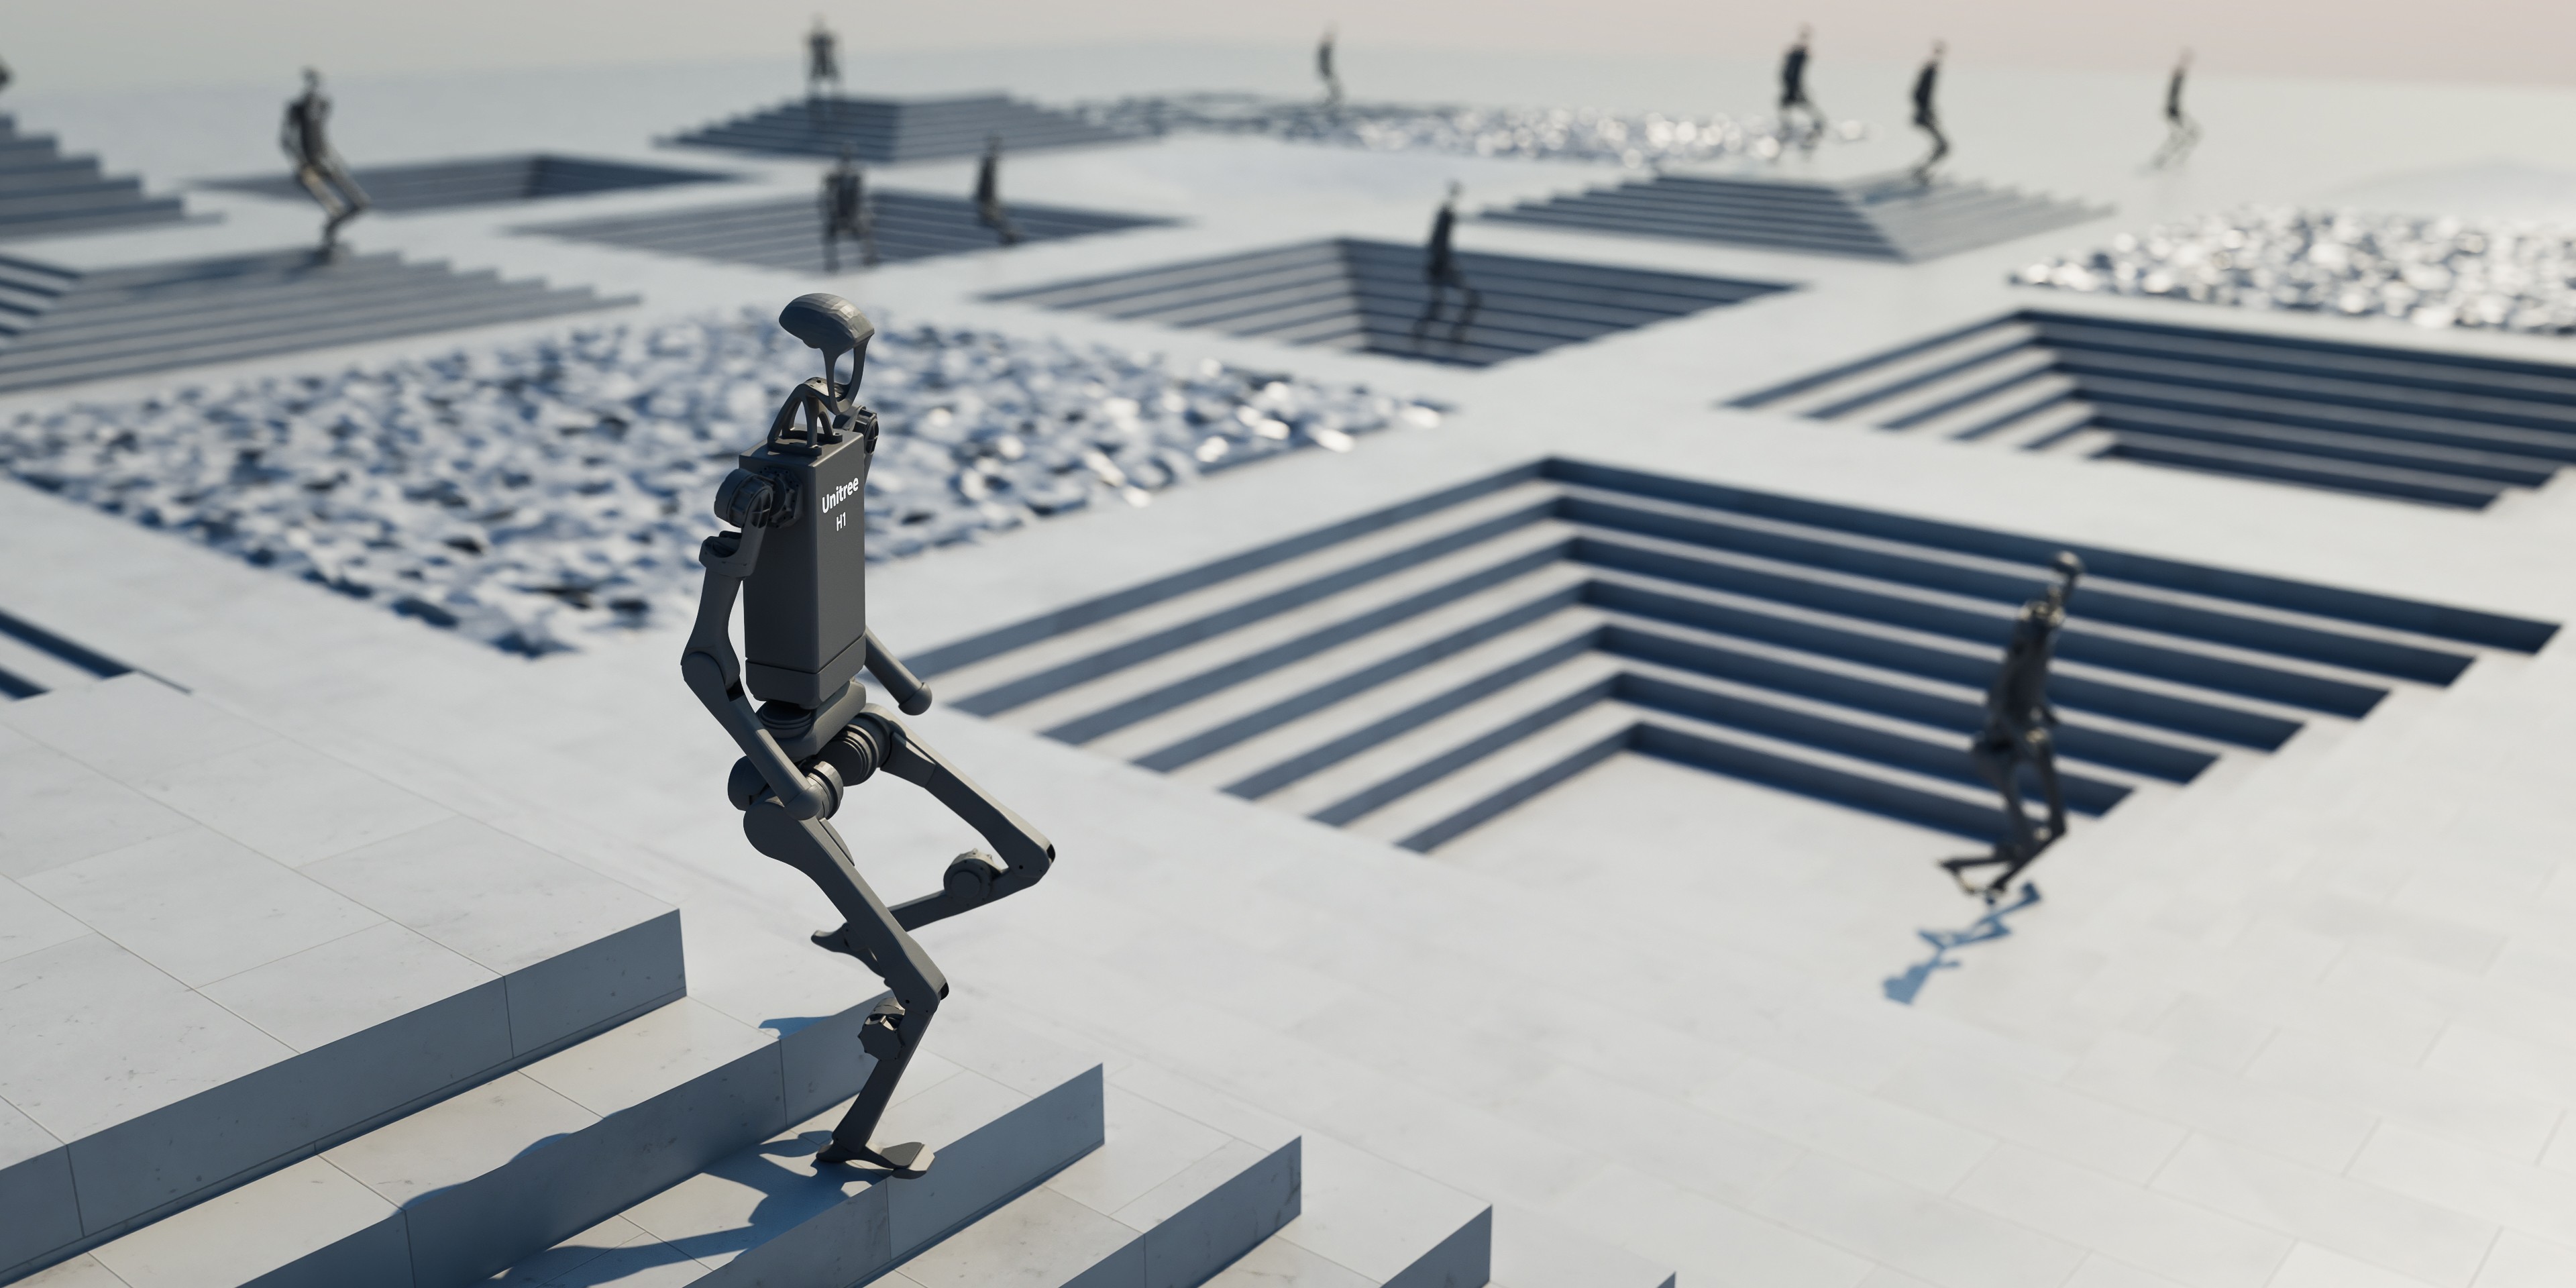
RoboVerseOrg/RoboVerse

Python

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

RoboVerse: Towards a Unified Platform, Dataset and Benchmark for Scalable and Generalizable Robot Learning

imitation-learningreinforcement-learningroboticssimulationrobot

兴趣:imitation learning and diffusion policies for robot control

#242026-04-07★ 31367

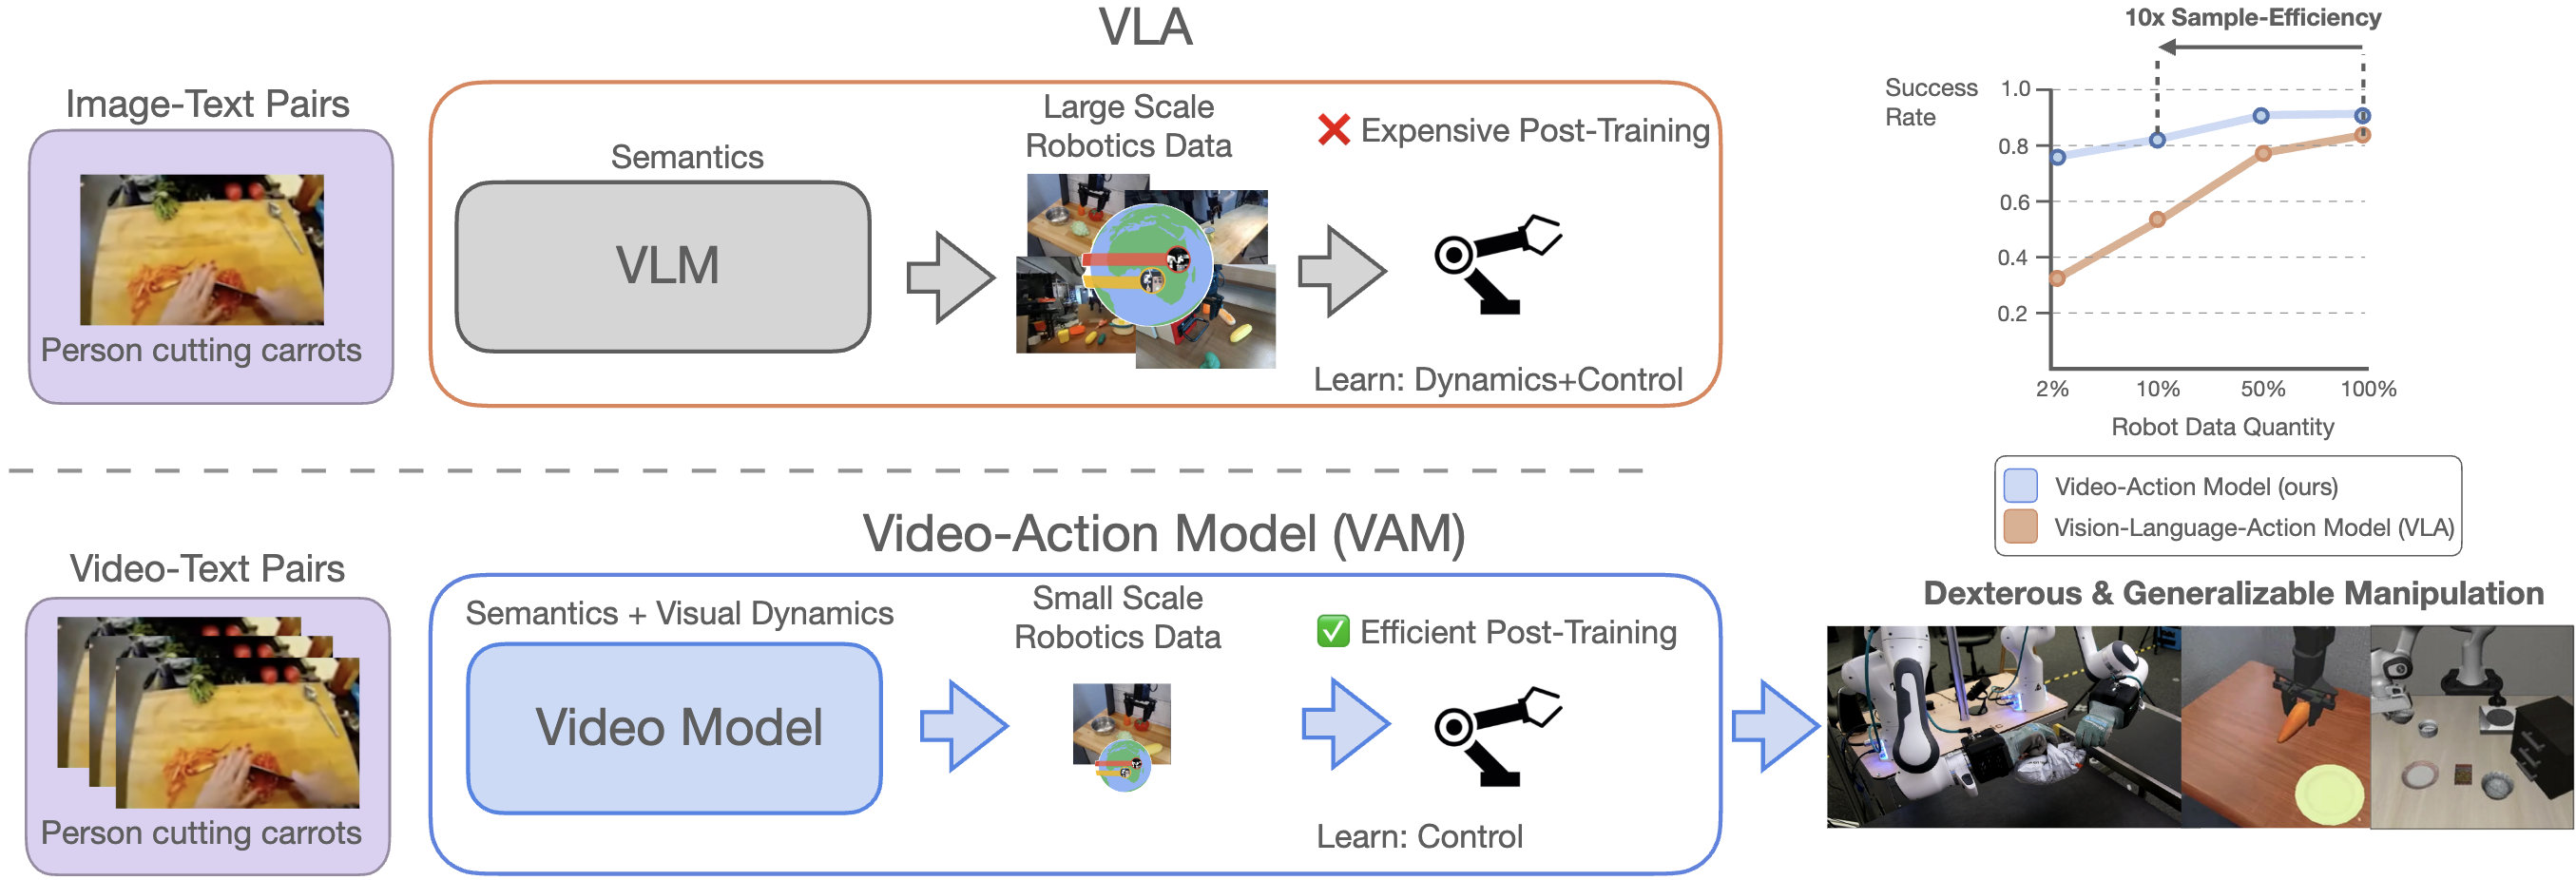
mimic-video/mimic-video

Python

Video-Action Models for Generalizable Robot Control Beyond VLAs

Video-Action Models for Generalizable Robot Control Beyond VLAs

robot-learningroboticsvamvideo-action-modelsvlarobotVLA

兴趣:imitation learning and diffusion policies for robot control

#252026-05-19★ 169 +1367

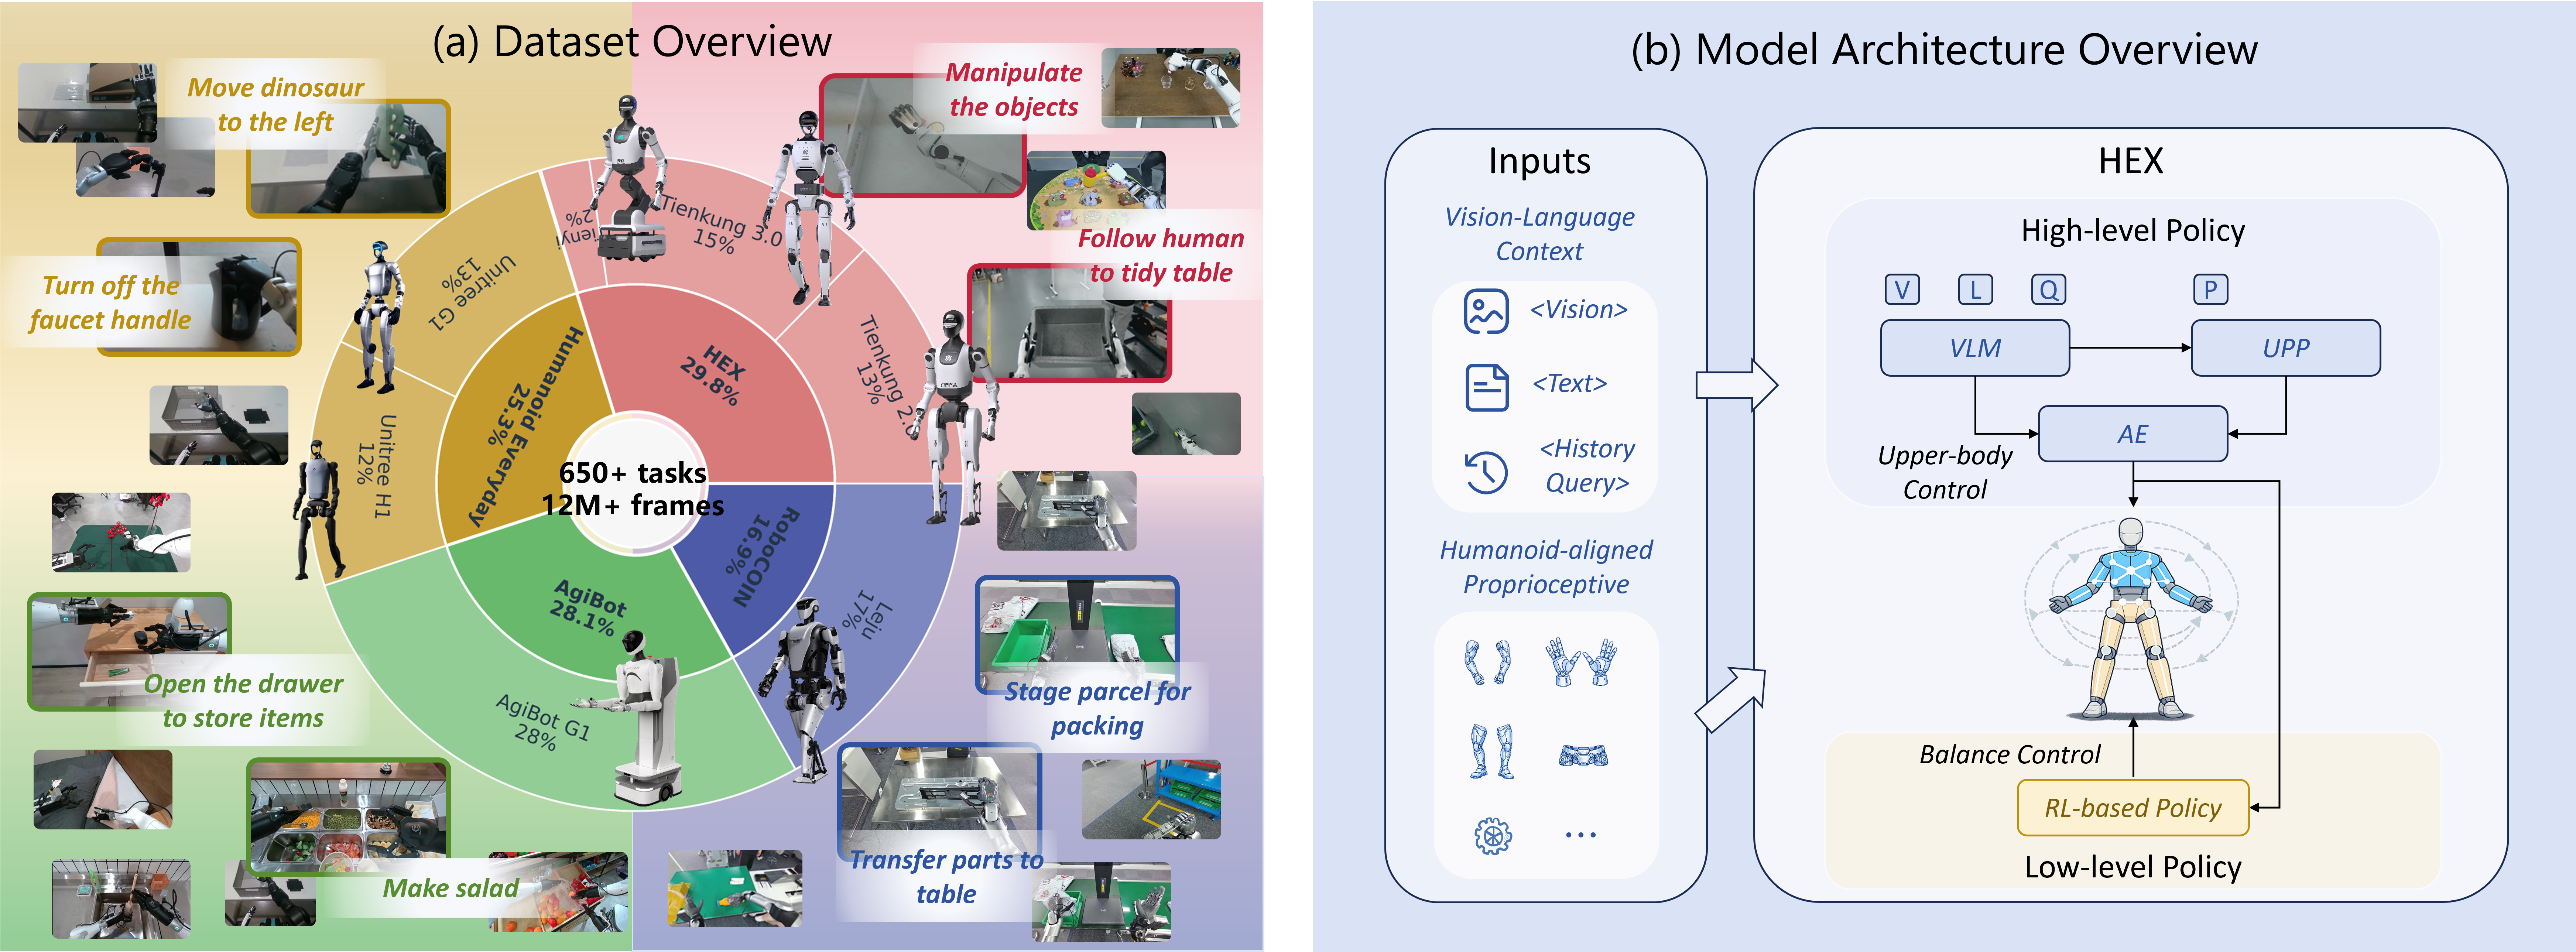
Open-X-Humanoid/HEX

Python

HEX is a whole-body vision-language-action framework for full-sized humanoid robots.

HEX is a whole-body vision-language-action framework for full-sized humanoid robots.

cross-embodimentembodied-aihumanoid-roboticsimitation-learningmultimodal-aivision-language-action-modelvla-modelwhole-body-manipulationmanipulationVLAvision-language-actionhumanoidembodied

兴趣:humanoid robots and whole-body control

#262026-07-06★ 2.2k67

dexmal/opendm

Python

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

An Open-World Foundation Model for General-Purpose Embodied Intelligence.

embodied-aiembodied-intelligenceroboticsvision-language-actionvlaVLAvision-language-actionembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#272026-09-18★ 165 +666

mll-lab-nu/embodied-first-exam

Python

The first exam for code agents in the physical world: frozen robot tasks from many benchmark suites, each answered with a program and verified in a separate sandbox. Runs on Harbor…

The first exam for code agents in the physical world: frozen robot tasks from many benchmark suites, each answered with a program and verified in a separate sandbox. Runs on Harbor.

ai-agentsbenchmarkcoding-agentsembodied-aievaluationharborllm-agentsrobot-learningrobotembodied

兴趣:vision-language-action (VLA) models and foundation models for robots
#282026-03-18★ 73k +32666

rohitg00/ai-engineering-from-scratch

Python

Learn AI Engineering! Learn it. Build it. Ship it for others.

Learn AI Engineering! Learn it. Build it. Ship it for others.

agentsaiai-agentsai-engineeringcomputer-visioncoursedeep-learningdsh

兴趣:multi-agent systems and LLM agents

#292024-09-29★ 3.6k +366

enactic/openarm

MDX

A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.

A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.

bilateral-teleoperationforce-feedbackgenesisgravity-compensationhumanoid-robotimitation-learningmachine-learningmoveit2robothumanoid

兴趣:humanoid robots and whole-body control

#302019-07-02★ 16.8k66

datawhalechina/leedl-tutorial

Jupyter Notebook

《李宏毅深度学习教程》(李宏毅老师推荐👍,苹果书🍎),PDF下载地址:https://github.com/datawhalechina/leedl-tutorial/releases

《李宏毅深度学习教程》(李宏毅老师推荐👍,苹果书🍎),PDF下载地址:https://github.com/datawhalechina/leedl-tutorial/releases

bertchatgptcnndeep-learningdiffusionganleedl-tutorialmachine-learning

兴趣:vision-language-action (VLA) models and foundation models for robots